Skip to content

General Questions

2.3k Topics 11.3k Posts

Not sure where your question goes? Ask here. ModalAI engineers and the community answer questions about any VOXL product.

  • Is the Flight Core V2 a direct replacement for V1?

    Unsolved
    7
    0 Votes
    7 Posts
    2k Views
    VinnyV
    Hi @nickyblanch Anytime. yeah, we had quite a bit of cables and mods to get to FCv2, but we think it's worth it, and now much more aligned with Dronecode and present/future hardware we make. FCv1 was a bit of a anomaly from it's early design inputs and constraints, so we do view FCv2 as much easier now to work with (if you are starting from scratch). We do have on our roadmap a much more "standard" drone mounting pattern w/o changing any other functions, but that effort keeps moving to the right... haha
  • Image transmission between Trip2 and VOXL2

    Unsolved
    9
    0 Votes
    9 Posts
    2k Views
    Eric KatzfeyE
    @Ethan-Wu Not sure about Ethernet. UVC is specific to USB.
  • External vision pose with voxl2

    Unsolved
    1
    0 Votes
    1 Posts
    926 Views
    No one has replied
  • Difference Between Starling C6 and C20 - PX4 Edition

    Unsolved
    6
    0 Votes
    6 Posts
    1k Views
    S
    @Moderator Perfect. Thanks.
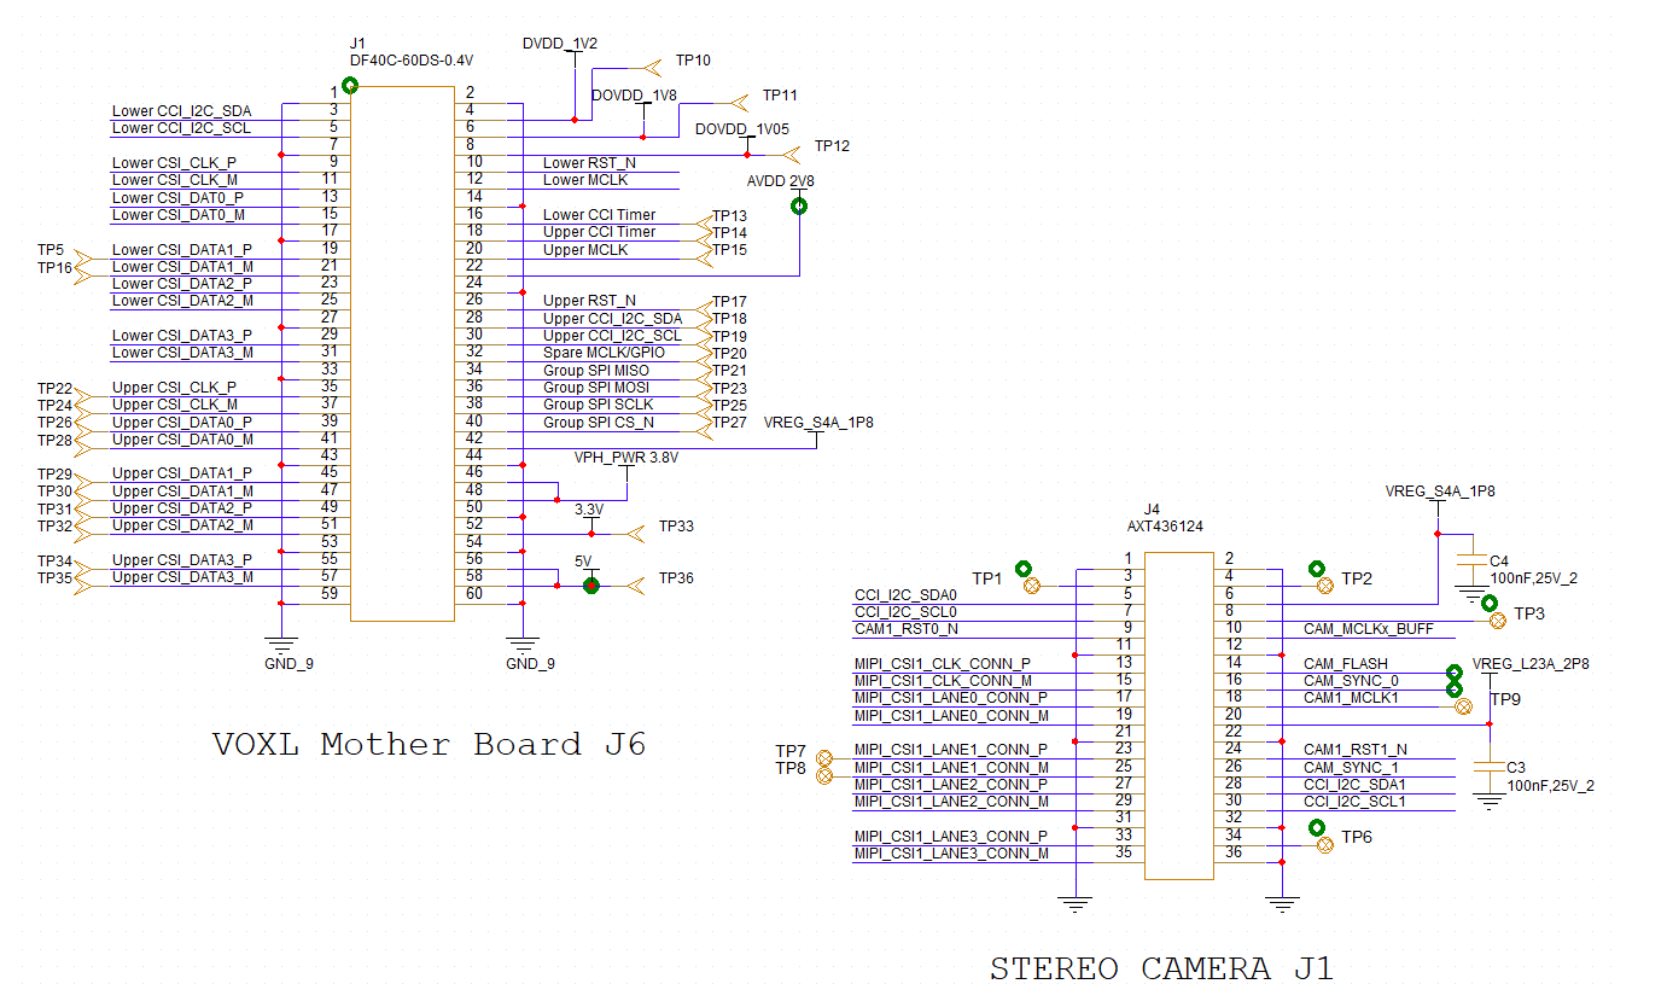
  • Schematic Review

    Unsolved
    12
    2
    0 Votes
    12 Posts
    2k Views
    VinnyV
    Hi @andrea_seock That set of connections does appear to be correct now. Keep us posted!
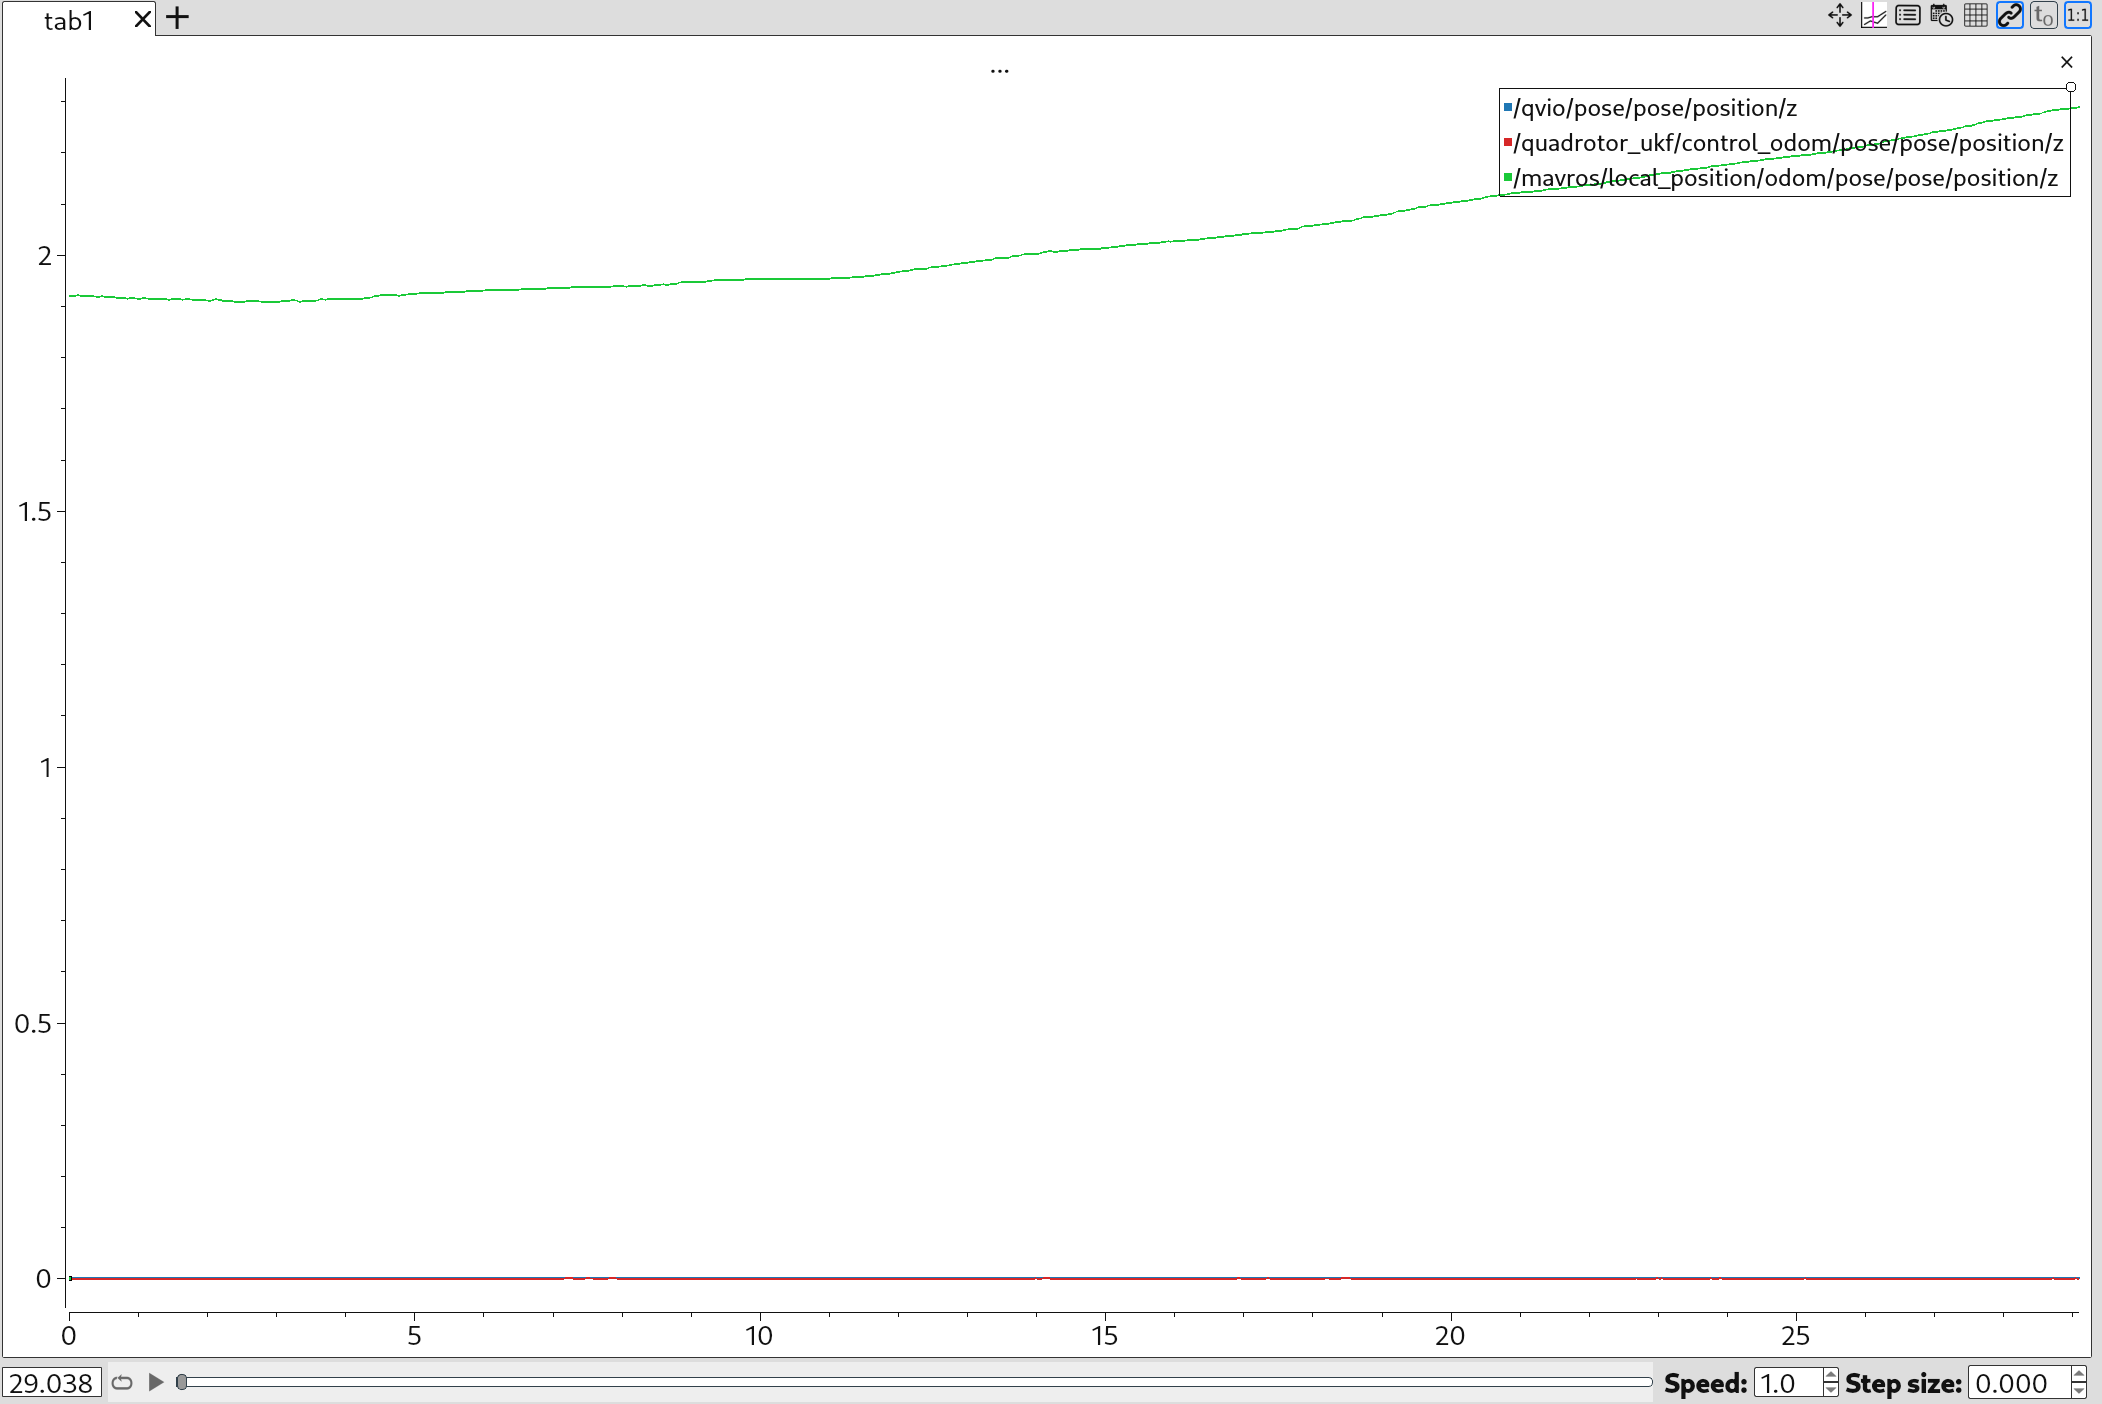
  • Mavros/local_position/odom Z-Axis drift

    Unsolved
    6
    1
    1 Votes
    6 Posts
    2k Views
    Kashish GargK
    @Riccardo-Franceschini We were not able to resolve this issue. However because our control stack is sending TRPY commands to mavros, this didn't come into play at all. The concern for us originated when the drone was taking off significantly higher than commanded. It turned out the propeller coefficients we received from ModalAI were insufficient.
  • Jethro is rather old... any plans to move forward?

    Unsolved
    5
    0 Votes
    5 Posts
    927 Views
    M
    @modaltb Great to know. I needed at least 2.1 to get layer support for RAUC. Which I hope ModalAI will support RAUC or SWUpdate out of the box at some point. Or another framework for OTA updates.
  • Forcing Voxl flight into fastboot

    Unsolved
    13
    1
    0 Votes
    13 Posts
    1k Views
    Jayden SmithJ
    @Vinny Oh, thanks for the advice!
  • Unexpected Flight Behavior after new RTK GPS Installation

    Unsolved
    3
    0 Votes
    3 Posts
    752 Views
    S
    @Alex-Kushleyev No. This was a test for the RTK GPS. I'll try.
  • Deep Learning with VOXL2

    Unsolved
    1
    0 Votes
    1 Posts
    903 Views
    No one has replied
  • How to Get the imei code from modem 4g tle

    Unsolved
    2
    0 Votes
    2 Posts
    1k Views
    tomT
    @Ariel-Saez Can you describe your hardware setup a bit more? Are you using voxl1 or voxl2? Are you using the Sierra 4G LTE add-on board?
  • ROS2 topic data not visible on remote computer (VOXL2, SDK 1.1)

    Unsolved
    5
    0 Votes
    5 Posts
    2k Views
    Zachary Lowell 0Z
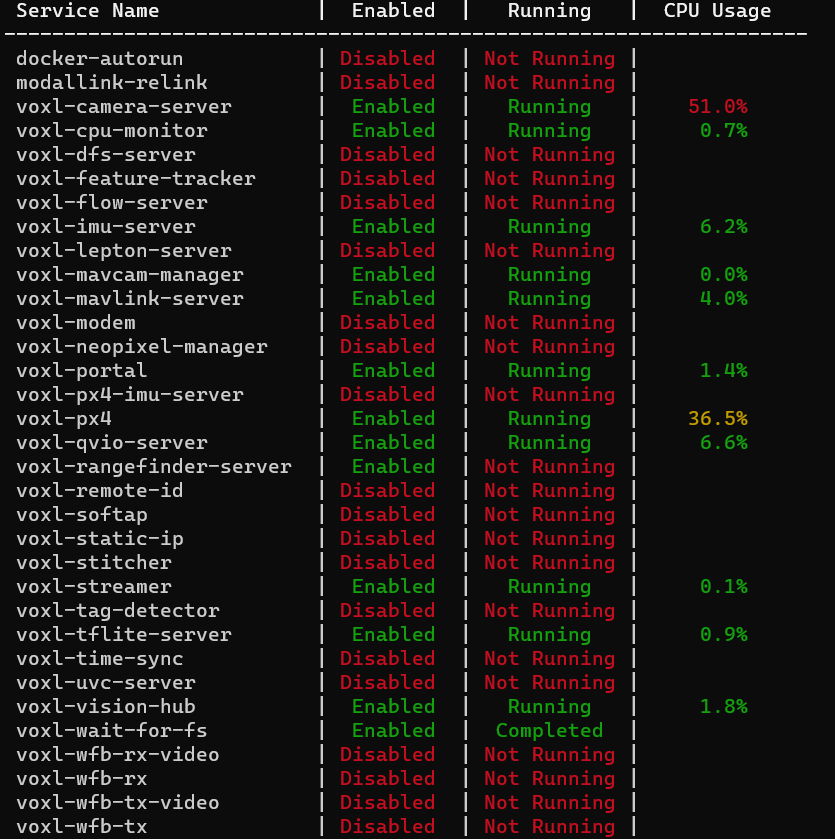
    @Isaac-Stephan-Remy I need you to still explain how you are sending data from the voxl2 to the parent computer - just because they are on the same wifi network doesn't mean that when you launch the ros2 node on the voxl2, and then run a ros2 topic list on your parent computer it will see those topics. There needs to be somewhere on your rpi or parent computer where you are probing the voxl2's ros2 instance whether you have sockets opened up, etc. Can you confirm that the voxl2 instance of ros2 is locally publishing - aka adb shell into another terminal instance of the voxl2 while the voxl-mpa-to-ros2 is actively running and try doing a ros2 echo TOPIC to see if it streams just fine locally - if it isnt, then that is your issue right there. Which topics are you actively trying to listen to as well? Do you have all the required services running? AKA voxl-imu-server, voxl-qvio-server, voxl-camera-server, etc. Can you post a screenshot of voxl-inspect-services Zach
  • Updated M500 with m10 heading issues

    Unsolved
    8
    0 Votes
    8 Posts
    1k Views
    wilkinsafW
    @tom After 8 hours of grueling coding: https://gitlab.com/voxl-public/voxl-sdk/utilities/voxl-px4-params/-/merge_requests/11
  • ADB no longer working, docker-daemon no longer on the VOXL-2 services page

    Unsolved
    5
    1
    0 Votes
    5 Posts
    1k Views
    Stefan AmundarainS
    @Alex-Kushleyev all is working now. Not sure what has changed but we are all set. Thank you for your help Alex! Stefan
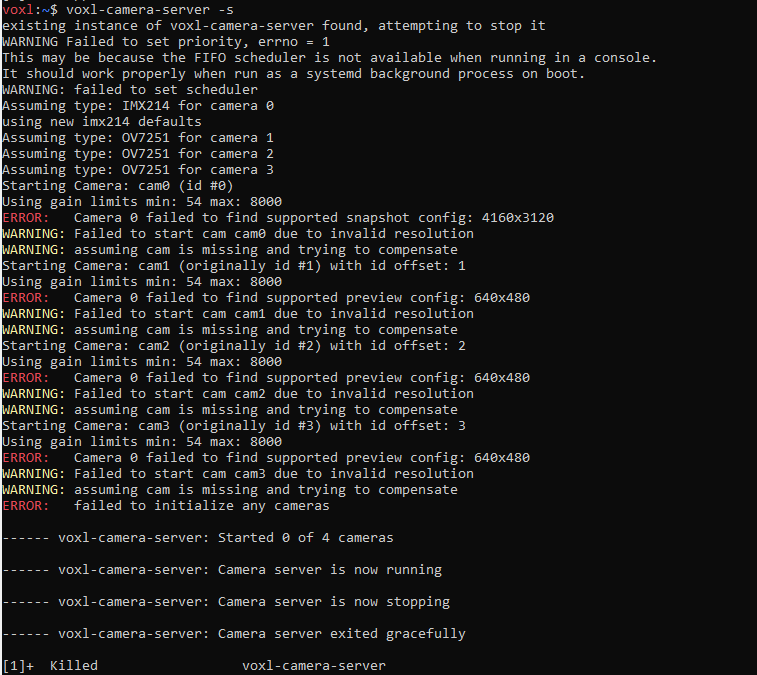
  • 4K Hires Camera crashes camera server

    Unsolved
    21
    2
    0 Votes
    21 Posts
    5k Views
    Alex KushleyevA
    @riteshsharma you are welcome. If the current approach initializes and works fine (is able to allocate all the buffers), the performance should be stable. I am a bit surprised so many buffers are needed for the encoder, there is probably some other settings in our software to change that... However since it is actually working with 11 buffers, maybe there is no need for me to test / fix that. If you do encounter any other issues, let me know..
  • Installing RTK GPS On Sentinel

    Unsolved
    10
    0 Votes
    10 Posts
    2k Views
    S
    @SMRazaRizvi Actually connecting my RTK-GPS to the configuration described here: https://docs.modalai.com/voxl2-guides-onboard-offboard-sensors/#external-gps-mag--gnss was not giving me RTK corrections so I am now using the J9 connector on the 5G modem, and that works fine in giving me GPS Coordinates and receiving RTK Connections. But another problem that I am facing is Compass Sensor 0 missing. Do you think there's some setting of the default compass that PX4 was picking up with the M8N GPS that came with the drone? Where can I configure the compass?
  • Voxl2 Mini i2c

    Unsolved
    9
    0 Votes
    9 Posts
    2k Views
    Eric KatzfeyE
    @tiralonghipol No, only within px4
  • Probing Intel Realsense LIDAR with voxl-mapper

    Unsolved
    11
    0 Votes
    11 Posts
    3k Views
    wilkinsafW
    @K-Stute I wish, but it is not.
  • Flying multiple RB5s

    Unsolved
    8
    0 Votes
    8 Posts
    1k Views
    T
    @Moderator I have followed the build instructions and got the voxl-mavlink-server built. I'm currently testing it with different ports (other than 14550). Thank you for your support.
  • Clarification on voxl and PX4 Integration for state estimation

    Unsolved
    3
    1 Votes
    3 Posts
    1k Views
    ModeratorM
    @aashry VIO and EKF2 are separate, concurrent state estimations. You can see where voxl-vision-hub sends the VIO data to PX4's EKF2 here: https://gitlab.com/voxl-public/voxl-sdk/services/voxl-vision-hub/-/blob/master/src/vio_manager.c?ref_type=heads#L395 I'm not sure what mavros uses, but here is the mpa-to-ros code to publish VIO data https://gitlab.com/voxl-public/voxl-sdk/utilities/voxl-mpa-to-ros/-/blob/master/catkin_ws/src/src/interfaces/vio_interface.cpp?ref_type=heads#L151