Skip to content

General Questions

2.3k Topics 11.3k Posts

Not sure where your question goes? Ask here. ModalAI engineers and the community answer questions about any VOXL product.

  • Poor quality of stereo-camera calibration

    Unsolved
    4
    0 Votes
    4 Posts
    1k Views
    Dobry KolaczD
    @VictorT Were you able to successfully calibrate after focusing/cleaning? The M0015-1 sensors should have no issues calibrating after they are properly focused as long as there are no scratches in the lens. Are they mounted in a VOXL Flight Deck?
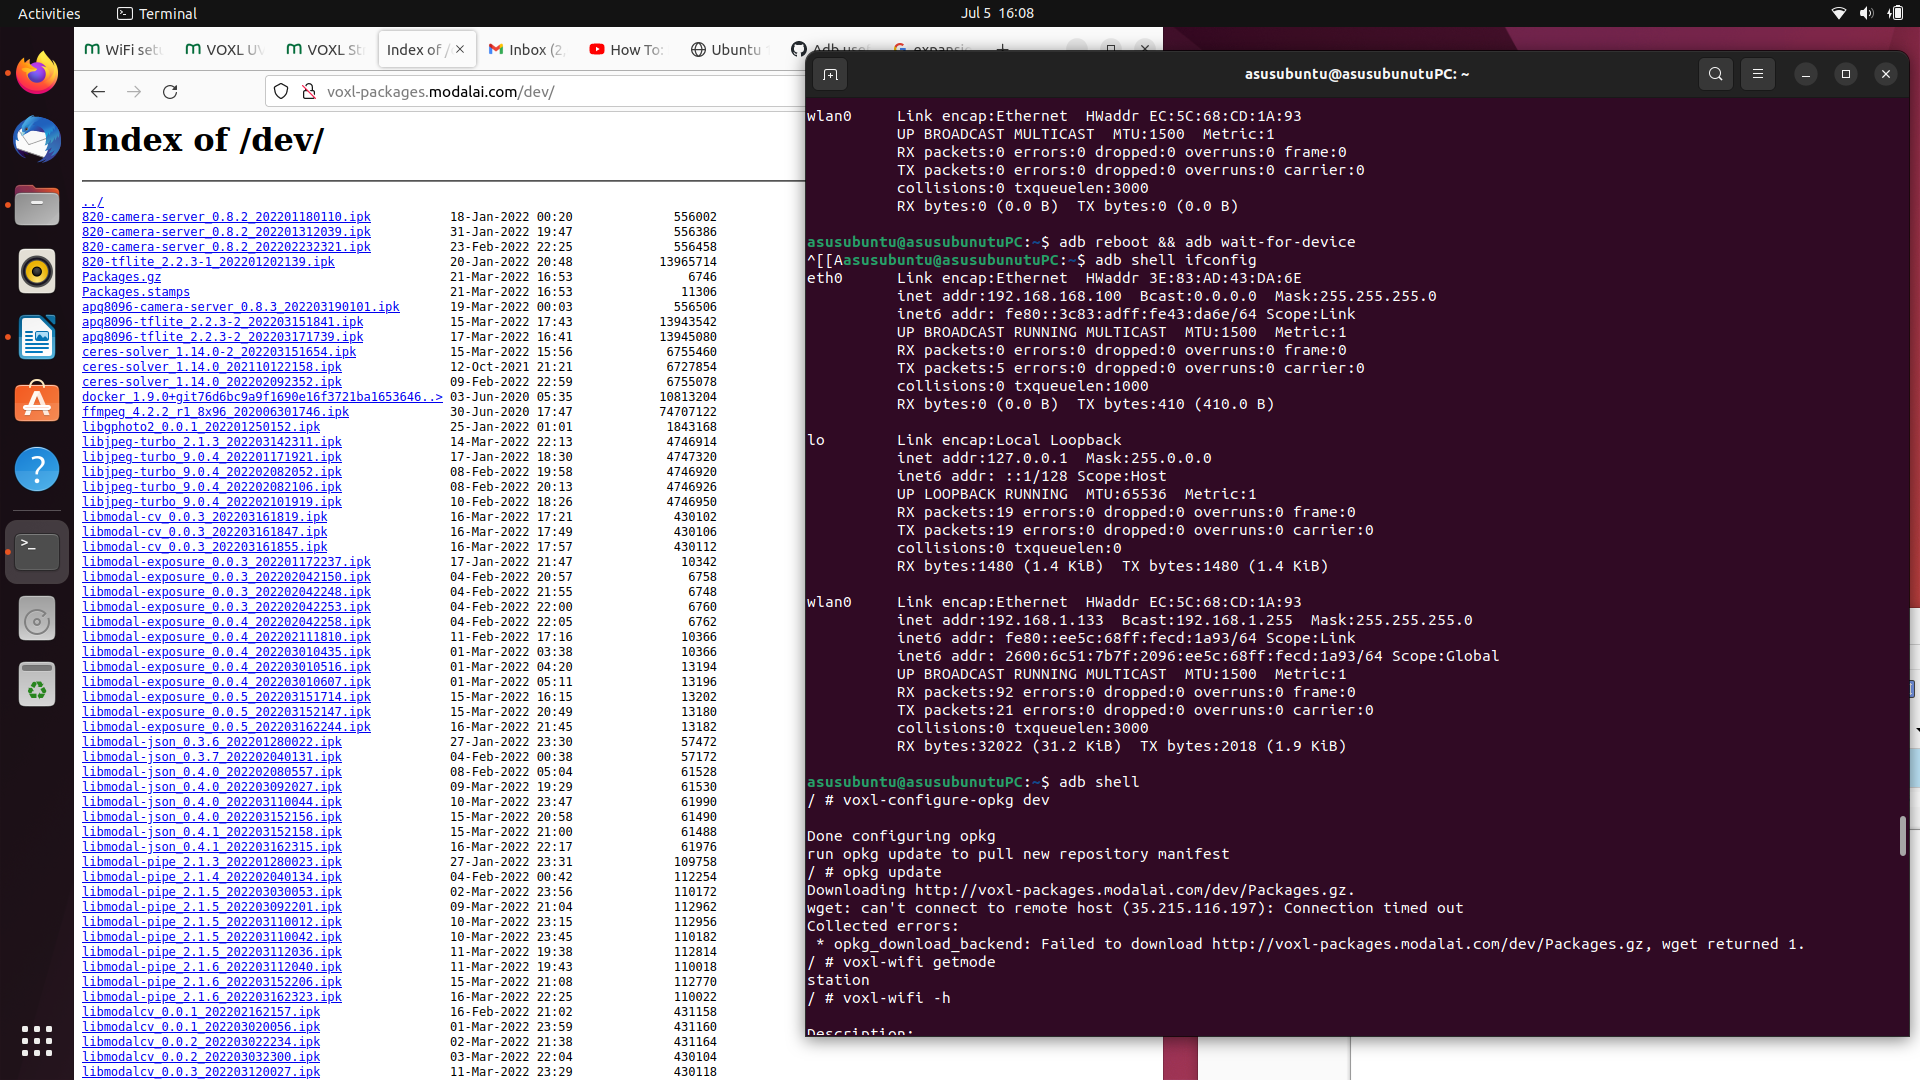
  • Trouble with Package server

    Unsolved
    1
    1
    0 Votes
    1 Posts
    557 Views
    No one has replied
  • x&y values zero in odometry

    Unsolved
    10
    1 Votes
    10 Posts
    2k Views
    Adrian HidalgoA
    @DarkKnightCH I believe Cliff answered that but in case it was missed: "z is fusing baro+vision and why you get z and no xy"
  • Failsafe to Altitude Hold from VIO(Position)

    Unsolved
    1
    0 Votes
    1 Posts
    379 Views
    No one has replied
  • Stereo right side out of focus

    Unsolved
    4
    1
    0 Votes
    4 Posts
    1k Views
    張為超張
    Thanks for answering me , I will give it a try! If i get any problem I will keep update. Thanks!
  • Using another external Visual System for Localization

    Unsolved voxl-vision-px4 voxl
    2
    0 Votes
    2 Posts
    2k Views
    D
    @vmassague Hi, I am pretty much doing the same thing and I faced a similar issue with you. have you solved this issue? https://forum.modalai.com/topic/919/using-motion-capture-systems-optitrack-for-position-estimation/2?_=1656684369036
  • Problem with the exposure of cameras

    Unsolved
    3
    0 Votes
    3 Posts
    710 Views
    H
    I am just using voxl-cam and the issue is with tracking camera .
  • Quick question on micro hard resets and ip hopping issue.

    Unsolved
    10
    0 Votes
    10 Posts
    2k Views
    R
    @tom Thanks I am aware of that web GUI. This issue persists regardless of standard Micro Hard setup. But I sort of have a solution and have delivered to the client now. Also knowing about the master slave auto setup timing that works more reliably. I'm essentially off this project. I am interested to know about it because I may integrate VOXLs into future products. I will consider opening another topic when I have a moment. Thanks for the suggestion and input!
  • HDMI accessory solution

    Unsolved
    2
    0 Votes
    2 Posts
    661 Views
    Chad SweetC
    MIPI-CSI and USB are the primary methods to connect cameras to VOXL Boson integration is documented here: https://docs.modalai.com/voxl-uvc-server/#running-voxl-uvc-server Image sensors via MIPI-CSI are documented here and here
  • Cant find TOF Camera ID using voxl-env show

    Unsolved
    1
    2
    0 Votes
    1 Posts
    365 Views
    No one has replied
  • Gaining VIO altitude estimates only in one direction

    Unsolved
    7
    0 Votes
    7 Posts
    887 Views
    H
    @James-Strawson ah I get it now. There was nothing wrong at all, it was all about reference frames. I should be looking at voxl-inspect-pose -l instead. Thanks!
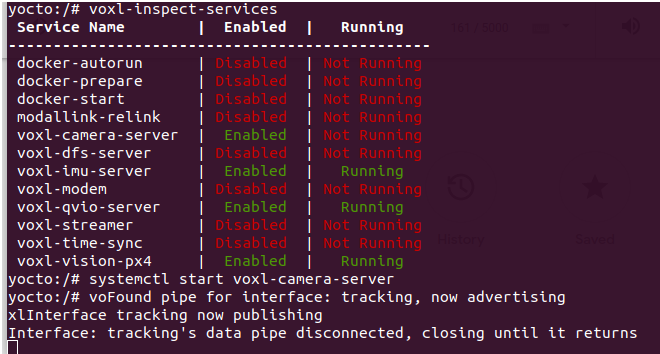
  • voxl-camera-server

    Unsolved
    8
    1
    0 Votes
    8 Posts
    2k Views
    VOXL FlightV
    For your information, voxl:~$ voxl-version cat: /etc/modalai/voxl-software-bundle-version.txt: No such file or directory -------------------------------------------------------------------------------- system-image: ModalAI 3.3.0 BUILDER: ekatzfey BUILD_TIME: 2021-06-06_19:28 kernel: #1 SMP PREEMPT Sun Jun 6 19:41:01 UTC 2021 3.18.71-perf factory-bundle: 1.0.1 (Yocto installation) -------------------------------------------------------------------------------- architecture: aarch64 processor: apq8096 os: GNU/Linux -------------------------------------------------------------------------------- voxl-suite: Package: voxl-suite Version: 0.5.0 Depends: libjpeg_turbo (>= 9.0.4), libmodal_exposure (>= 0.0.2), libmodal_json (>= 0.3.6), libmodal_pipe (>= 2.1.1), librc_math (>= 1.1.5), libvoxl_cutils (>= 0.0.2), libvoxl_io (>= 0.5.4), mavlink-camera-manager (>= 0.0.2), mongoose (>= 7.3.0), opencv (>= 4.5.2-2), openmp (>= 10.0.2), voxl-camera-calibration (>= 0.1.1), voxl-camera-server (>= 0.8.1), voxl-cpu-monitor (>= 0.2.0), voxl-dfs-server (>= 0.2.2), voxl-docker-support (>= 1.1.3), voxl-gphoto2 (>= 0.0.5), voxl-imu-server (>= 0.9.1), voxl-mavlink (>= 0.0.2), voxl-modem (>= 0.12.0), voxl-mpa-tools (>= 0.3.6), voxl-nodes (>= 0.2.0), voxl-portal (>= 0.1.2), voxl-qvio-server (>= 0.3.4), voxl-streamer (>= 0.2.6), voxl-tag-detector (>= 0.0.2), voxl-tflite (>= 2.2.3), voxl-tflite-server (>= 0.1.5), voxl-utils (>= 0.8.4), voxl-vision-px4 (>= 0.9.5), voxl-vpn (>= 0.0.3) Status: install user installed Architecture: all Installed-Time: 5549
  • This topic is deleted!

    1
    0 Votes
    1 Posts
    4 Views
    No one has replied
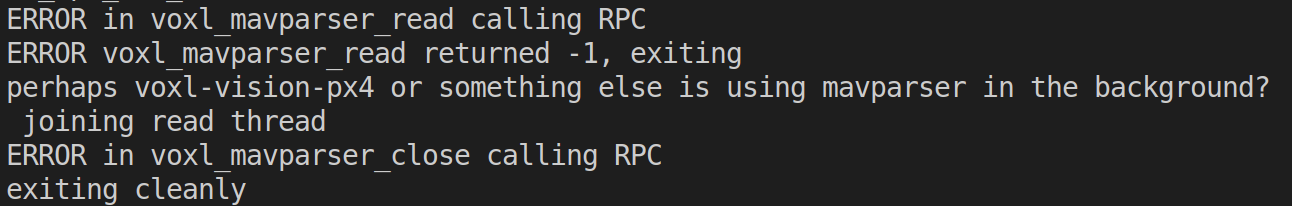
  • Multiple mavparser connections

    Unsolved
    2
    1
    0 Votes
    2 Posts
    651 Views
    No one has replied
  • Heavy Drone Stability Problem.

    Unsolved
    2
    0 Votes
    2 Posts
    650 Views
    Chad SweetC
    Hi Caleb, All new multirotor vehicles need to go through PID tuning before being safe for flight Our systems mostly run PX4, so it is definitely recommended to follow the px4 PID tuning guide https://docs.px4.io/v1.12/en/config_mc/pid_tuning_guide_multicopter.html
  • Voxl cam to external flight controller

    Unsolved
    3
    0 Votes
    3 Posts
    700 Views
    H
    HELLO, As mentioned above I made a cable to connect VOXL to Pixhawk cube. How can I verify if the UART is working? Thank you
  • problems cloning MAVSDK Python docker from Gitlab

    Unsolved
    16
    0 Votes
    16 Posts
    3k Views
    tomT
    @parbat101 Since it is included in that image, one (bad) option is to modify the script and then re-build the Docker image and it will pull in the modified script. The better solution that I would recommend is create a new script i.e my-script.py and then mount it inside the Docker image on run time using something like this: docker run -it --rm --privileged --net=host -v $(pwd)/my-script.py:/path/to/my-script.py gcr.io/modalai-public/voxl-mavsdk-python:v1.1 /bin/bash where you mount the script from your host os inside of the Docker container. You can read more about docker + mounting here: https://docs.docker.com/storage/bind-mounts/ This would allow you to modify the script on your host os, then run the above command to pull it into the docker container on run-time. Keep in mind if you modify the script inside of the docker container and then exit the container, the edits will be lost. So make sure you edit the script outside of the container and then re-run the above command to pull in the updated script. Another note, /path/to/my-script.py will denote the path at which you would like to have the script live inside of the docker container, so you will need to modify that to your liking.
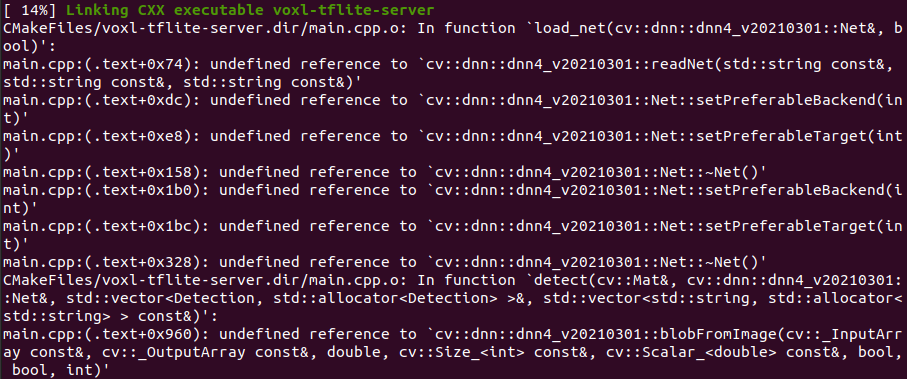
  • Error when using opencv dnn module.

    Unsolved
    3
    1
    0 Votes
    3 Posts
    663 Views
    Nguyen Tien SuN
    Thank @Chad-Sweet !
  • Cooling question

    Unsolved
    2
    0 Votes
    2 Posts
    660 Views
    Adrian HidalgoA
    Yes, it is a good idea to cool the Voxl-Flight with some sort of cooling device. We have not performed comprehensive environmental testing, but for Voxl 0-55C Ambient, Guaranteed by Test. Enclosures or other structures which raise the ambient temperature will impact this range. The performance will be better with cooler temps. Hope this helps
  • Replacing the VIO pose message with the MoCap pose message

    Unsolved
    1
    0 Votes
    1 Posts
    476 Views
    No one has replied