Skip to content

General Questions

2.3k Topics 11.3k Posts

Not sure where your question goes? Ask here. ModalAI engineers and the community answer questions about any VOXL product.

  • Ceres c++ error when used in voxl2 project

    Unsolved
    9
    1
    0 Votes
    9 Posts
    1k Views
    Alex KushleyevA
    @lfierz , excellent! I am glad that it worked
  • Unable to retrieve camera information

    Unsolved
    3
    0 Votes
    3 Posts
    801 Views
    Riccardo FranceschiniR
    Hi @Kashish-Garg unfortunately no update on this side
  • Seeker offboard failsafe unexpected behavior and firmware update parameter issues.

    Unsolved
    3
    0 Votes
    3 Posts
    753 Views
    tomT
    @Karrthik-Gk SDK 1.1.1 for voxl 1 includes PX4 v1.14 for flight core. I would recommend starting there
  • Flightcore v2

    Unsolved
    2
    0 Votes
    2 Posts
    517 Views
    ModeratorM
    @Jw0719 hi, we're not familiar with that specific capability. Flight Core v2 is fairly stock PX4 though, so if PX4 supports it Flight Core should support it
  • VOXL MPA to ROS Seeker

    Unsolved
    1
    0 Votes
    1 Posts
    1k Views
    No one has replied
  • Seeker SLAM Setup Help

    Unsolved
    9
    0 Votes
    9 Posts
    3k Views
    U
    @tom Installing the VOXL1 SDK now... Thanks!
  • Voxl 2 Mini Mounting

    Unsolved
    1
    0 Votes
    1 Posts
    475 Views
    No one has replied
  • Is it possible to do a multiple camera streaming in the VOXL m500?

    Unsolved
    1
    0 Votes
    1 Posts
    387 Views
    No one has replied
  • Exploring the Potential of VOXL m500 for Advanced Control Algorithm Testing

    Unsolved
    1
    0 Votes
    1 Posts
    294 Views
    No one has replied
  • Cannot arm Starling in Position mode

    Unsolved
    2
    6
    0 Votes
    2 Posts
    658 Views
    ModeratorM
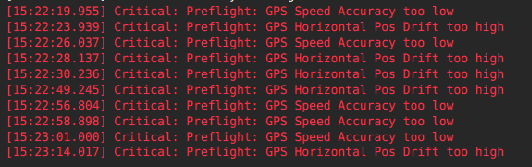
    @kerct did you remove the GPS? It is showing errors related to GPS You can upload your PX4 log to logs.px4.io and it will likely tell you
  • Are MCBL-00068 cables any different from regular cables?

    Unsolved
    2
    1
    0 Votes
    2 Posts
    529 Views
    ModeratorM
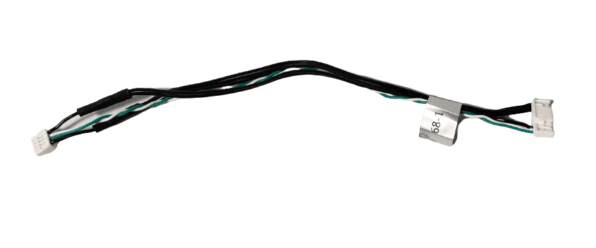
    @황인호 We're not sure how you would define regular cables. You can find the specs for MCBL-00068 here: https://docs.modalai.com/cable-datasheets/#mcbl-00068
  • Get depth from dfs

    Unsolved
    3
    0 Votes
    3 Posts
    922 Views
    ModeratorM
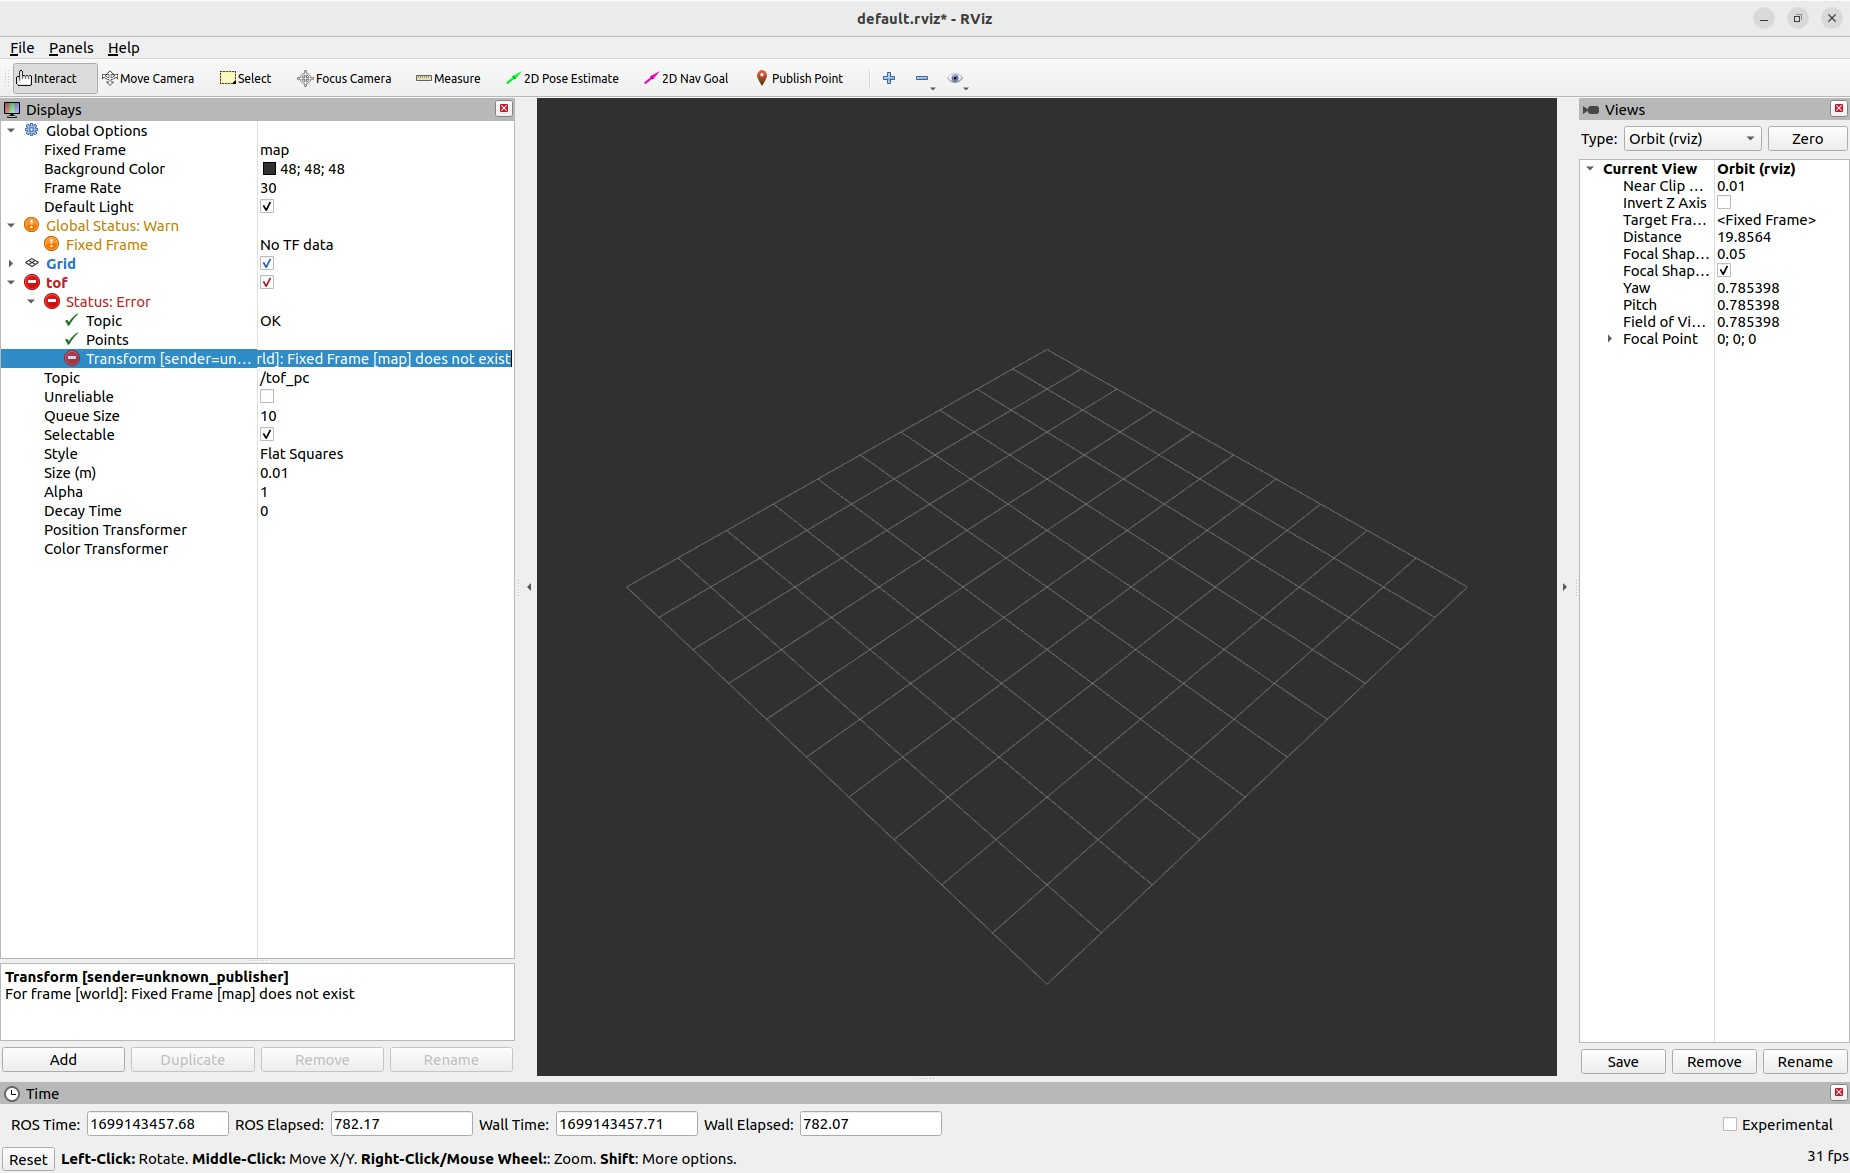
    @cch you can see the code where voxl-vision-hub takes the pointcloud topic from DFS and uses the information, this should be a good reference: https://gitlab.com/voxl-public/voxl-sdk/services/voxl-vision-hub/-/blob/master/src/voa_manager.c?ref_type=heads#L434
  • Integrating Holybro GPS on Sentinel drone

    Unsolved
    2
    0 Votes
    2 Posts
    611 Views
    ModeratorM
    @SMRazaRizvi At first glance, it looks like that GPS uses CAN to communicate. There is not a supported CAN interface on VOXL 2. You will need to use an Arduino or something in the middle to translate CAN protocol to something VOXL 2 can interface with
  • 10Hz GPS?

    Unsolved
    6
    0 Votes
    6 Posts
    868 Views
    S
    @SethG How did you do this? Please mention the steps here.
  • This topic is deleted!

    2
    1
    0 Votes
    2 Posts
    10 Views
  • Connecting External LiDAR Sensor

    Unsolved
    1
    0 Votes
    1 Posts
    657 Views
    No one has replied
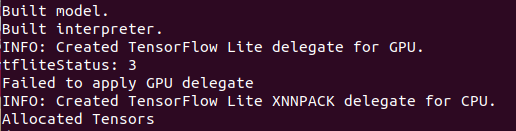
  • VOXL 2 tflite GPU delegate fails on custom model

    Unsolved
    1
    1
    0 Votes
    1 Posts
    615 Views
    No one has replied
  • Voxl2 Webportal

    Unsolved
    2
    0 Votes
    2 Posts
    1k Views
    Eric KatzfeyE
    @Jetson-Nano Code is here: https://gitlab.com/voxl-public/voxl-sdk/services/voxl-portal
  • This topic is deleted!

    1
    0 Votes
    1 Posts
    4 Views
    No one has replied
  • SITL simulation of VOXL Vision PX4

    Unsolved
    5
    0 Votes
    5 Posts
    2k Views
    Eric KatzfeyE
    @Siddhanth I guess I don't understand what you are trying to accomplish. SITL runs on the host computer. HITL runs on the VOXL. If you have a MAVROS application running on VOXL and you want to test it against PX4 you can use HITL. Or you could run your MAVROS application on the host computer and test it against SITL.