Skip to content
  • Recovering Flight Logs from a Bricked VOXL2

    Unsolved VOXL 2 and VOXL 2 Mini voxl-2
    6
    2
    0 Votes
    6 Posts
    1k Views
    N. ChenN
    @lhermosillo That is harsh. Do you have a bare board, or one with some additions? If you can use the bare voxl2, try that. If you have been using the bare board all along, I'm stumped here. I'd maybe try to reinstall the modalai-qdl env, or use another image. Maybe the qdl command itself instead of the webUI. Hope you'll be able to save your board!
  • 0 Votes
    14 Posts
    1k Views
    Eric KatzfeyE
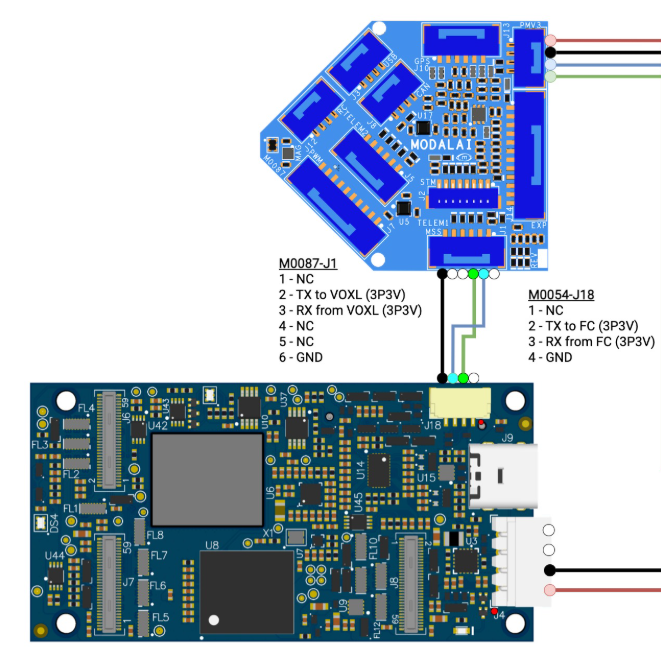
    @ravi I'm suspecting you have a bad cable or the cable is subject to some interference. Can you try this on a benchtop with just a VOXL 2 and an FC v2 and no other components? Is it currently integrated into a custom drone? Can you look at the signal quality on the TX and RX UART lines with an oscilloscope?
  • WASP-200 LIDAR on Starling 2 Max

    Unsolved VOXL 2 and VOXL 2 Mini voxl-2
    4
    0 Votes
    4 Posts
    661 Views
    Eric KatzfeyE
    @adiprin1 On Ardupilot there is currently no way to use apps side UARTs (Some day we will add a method to use them). So, you would have to use one of the 3 UARTs attached to the DSP. If you removed the RC or the GPS and used that port then, theoretically, it could work. However, we have not tried that so can't make any guarantees. Also on PX4 you can use an apps side UART if there is one available on an add-on board. And, as you mention, you could use an SBUS RC on the VOXL 2 IO board and free up the standard RC UART.
  • 0 Votes
    7 Posts
    851 Views
    N
    @Moderator Many thanks for your reply Our goal is to develop a drone capable of indoor/confined-space autonomous flight without GPS, using SLAM-based navigation. The system should perform 3D mapping, obstacle avoidance, and full-area path planning. We would like to confirm the correct set of components and the required algorithm stack. Planned Algorithm Stack: State Estimation: QVIO (Visual-Inertial Odometry) providing position and velocity to PX4/EKF2 via voxl-vision-hub. Mapping: voxl-mapper (TSDF/ESDF) using a depth source. Planning and Avoidance: voxl-mapper’s path planner or PX4 avoidance, using VIO as the pose source. Autopilot: PX4 running on VOXL2 via voxl-px4. Proposed Hardware: VOXL2 Autopilot – https://www.modalai.com/products/voxl-2?variant=39914779836467 VOXL2 Tracking Camera (Mono Global-Shutter) – required for QVIO (please confirm the correct part number). -- https://www.modalai.com/collections/image-sensors/products/msu-m0149-1 VOXL2 Compatible adapter https://www.modalai.com/products/mdk-m0076-1 VOXL2 Time-of-Flight (ToF) Depth Sensor – https://www.modalai.com/products/m0178?variant=48528287793456 VOXL2 Mini 40-Pin Connector ToF Adapter (MDK-M0172-1-00) – https://www.modalai.com/products/mdk-m0172-1-00 Questions: Please confirm if this set (VOXL2 + Tracking Camera + Camera adapter + ToF sensor + ToF adapter) is sufficient for robust indoor SLAM navigation using PX4. For the tracking camera, which exact ModalAI part number is recommended for QVIO on VOXL2? Are there any best-practice configurations for voxl-mapper when using ToF instead of stereo depth? Would you recommend any additional sensors for improved performance in larger or more complex indoor environments? Goal Summary: We want the drone to hold position, generate a 3D occupancy map, avoid obstacles, and autonomously plan paths throughout the flyable space—without any GPS input. Thank you in advance for your guidance and confirmation. Best regards, Nitin
  • Optimizing DSP Load wr.t. IO

    Unsolved VOXL 2 and VOXL 2 Mini voxl-2
    3
    0 Votes
    3 Posts
    606 Views
    Eric KatzfeyE
    @Alex-Kushleyev The IMU is being configured with an 8K ODR so by increasing IMU_GYRO_RATEMAX you are reading the FIFO more often but reading less samples each time. So you are mainly increasing the overhead of context switching. Can you characterize how much the load increases just by increasing IMU_GYRO_RATEMAX and not doing any of the extra UART IO? Unfortunately we don't have a lot of control over the low level implementation of the IO drivers that are in the Qualcomm code. And there is no DMA that could help lower IO overhead. One idea would be to lower the ODR to 1K so that you are only reading one sample from the FIFO at each interrupt.
  • NTP versus Systemd-timesyncd on the VOXL2

    Unsolved VOXL 2 and VOXL 2 Mini voxl-2
    4
    0 Votes
    4 Posts
    791 Views
    Alex KushleyevA
    @Aaron-Porter , perhaps systemd-timesyncd works together with systemd to correctly interpret the clock adjustments, so that run-time of systemd services is properly calculated. Alex
  • VOXL 2 blinking green and not connecting

    Unsolved VOXL 2 and VOXL 2 Mini voxl-2
    1
    0 Votes
    1 Posts
    290 Views
    No one has replied
  • Changing Time stamps from Monotonic to Real-Time

    Unsolved VOXL 2 and VOXL 2 Mini time imu camera voxl-2
    6
    0 Votes
    6 Posts
    2k Views
    Eric KatzfeyE
    @Aaron-Porter Most likely jump is due to NTP aligning the clock. The other device that is time stamping using real time clock really should move to monotonic.
  • GPIO on DSP?

    Unsolved VOXL 2 and VOXL 2 Mini voxl-2
    8
    0 Votes
    8 Posts
    2k Views
    J
    @tom got it, I think you indirectly answered my question by giving me the last valid configuration. Am I looking in the right place?: voxl sdk 1.5.0 -> system image 1.8.04 -> recipes-kernel/linux-msm/files/dts/common/m0xxx-modalai-gpio.dtsi : &soc { voxl_gpio { ... modalai,gpio-init-output-high = <0 1 53 56 57 85 86 87 88 89 124 152 157 159>; modalai,**gpio-init-output-low** = <36 37 **46** 54 55 67 82 83 84 131 153 154 155>; modalai,gpio-init-input = <48 49 50 51 52 110 111 112 113 114>; status = "ok"; }; ... }; So settings for gpio pin 46 on sentinel w/ spektrum receiver should be direction:out, value:0 assuming they aren't overwritten somewhere else.
  • QGC not loading proper

    Unsolved VOXL 2 and VOXL 2 Mini voxl-2
    8
    0 Votes
    8 Posts
    1k Views
    Jetson NanoJ
    @tom Thank you for the support.
  • edk2 error when build system image for VOXL 2

    Unsolved VOXL 2 and VOXL 2 Mini voxl-2
    1
    0 Votes
    1 Posts
    232 Views
    No one has replied
  • Incomplete file in voxl-opencv

    Unsolved VOXL 2 and VOXL 2 Mini voxl-2
    3
    0 Votes
    3 Posts
    520 Views
    R
    @Alex-Kushleyev Thanks
  • Multiple RTSP streaming

    Unsolved VOXL 2 and VOXL 2 Mini voxl-2
    3
    0 Votes
    3 Posts
    748 Views
    Jetson NanoJ
    @Eric-Katzfey thank you for reverting back, it was very helpful, i was able to get multiple streams.
  • VOXL2 can not connect to ethernet by type C (J9)

    Unsolved VOXL 2 and VOXL 2 Mini voxl-2
    1
    0 Votes
    1 Posts
    478 Views
    No one has replied
  • VOXL2 TOF Camera not working

    Unsolved VOXL 2 and VOXL 2 Mini voxl-2
    2
    0 Votes
    2 Posts
    421 Views
    Viktor GalV
    @Thomas-Müller interesting. i'm just experience the very same thing. have you by chance figured out what was the issue?
  • VOXL2 and PCIe WiFi module

    Unsolved VOXL 2 and VOXL 2 Mini voxl-2
    1
    0 Votes
    1 Posts
    331 Views
    No one has replied
  • QVIO NO DATA - MAVLINK MISSING TOPICS

    Unsolved VOXL 2 and VOXL 2 Mini voxl-2
    9
    0 Votes
    9 Posts
    1k Views
    Eric KatzfeyE
    @andrevs01 But, the configuration of what Mavlink broadcasts can be different than what it actually broadcasts. It will only broadcast something that it is configured to broadcast if it is receiving data from the required topic(s) internally.
  • 0 Votes
    8 Posts
    1k Views
    tomT
    @Thomas-Müller you can read up on our "VOA" implementations here: https://docs.modalai.com/voa/
  • VOXL2 Servos Not Rotating

    Unsolved VOXL 2 and VOXL 2 Mini voxl-2
    2
    1
    0 Votes
    2 Posts
    720 Views
    VinnyV
    HI @teddy-zaremba That is the correct approach. We have no mentions of direct servo support from VOXL 2 or any HW. All servos, just like an ESC, need power from an independent battery source not from VOXL 2. Thanks for clarifying here on the Forum.