Skip to content

VOXL 2 and VOXL 2 Mini

665 Topics 3.8k Posts

VOXL 2, VOXL 2 Mini and VOXL 2 IO: bring-up, connectors, power, cameras, system image and SDK installs on the current compute platform.

  • M0054-2 Unbricking Image

    Unsolved voxl-2
    3
    0 Votes
    3 Posts
    959 Views
    Z
    @WesleyHavocAI Thanks for catching it! We just updated flat builds and now it contains m0054-2!
  • Near-zero feature extraction (single camera)

    Unsolved voxl-2-mini
    3
    0 Votes
    3 Posts
    2k Views
    zauberflote1Z
    Regarding the feature track tab, I recommend upgrading to the latest available SDK, features should show on voxl-portal. The correct overlay is under VIO indeed
  • GPIO on DSP?

    Unsolved voxl-2
    8
    0 Votes
    8 Posts
    2k Views
    J
    @tom got it, I think you indirectly answered my question by giving me the last valid configuration. Am I looking in the right place?: voxl sdk 1.5.0 -> system image 1.8.04 -> recipes-kernel/linux-msm/files/dts/common/m0xxx-modalai-gpio.dtsi : &soc { voxl_gpio { ... modalai,gpio-init-output-high = <0 1 53 56 57 85 86 87 88 89 124 152 157 159>; modalai,**gpio-init-output-low** = <36 37 **46** 54 55 67 82 83 84 131 153 154 155>; modalai,gpio-init-input = <48 49 50 51 52 110 111 112 113 114>; status = "ok"; }; ... }; So settings for gpio pin 46 on sentinel w/ spektrum receiver should be direction:out, value:0 assuming they aren't overwritten somewhere else.
  • This topic is deleted!

    1
    1
    0 Votes
    1 Posts
    2 Views
    No one has replied
  • Connecting to QGC Via Transmitter

    Unsolved voxl-2
    6
    0 Votes
    6 Posts
    1k Views
    Eric KatzfeyE
    @PatkirkMartin No, as I said a UART mapped to the applications processor would also work. PX4 has a split architecture on VOXL2 with all flight critical operations happening on the DSP and support functions such as Mavlink, logging, and data manager are on the applications processor. But there is flexibility to move functions between them as needed. So, to match the ELRS receiver with the Mavlink module you could run it on the applications processor instead of the DSP. However, you would need an expansion board that exposes such a connector.
  • GPIO 64 GPI_64_INT_N on J10 signal

    Unsolved voxl-2-mini
    7
    0 Votes
    7 Posts
    1k Views
    M
    @LukeNow This worked, thanks.
  • This topic is deleted!

    1
    0 Votes
    1 Posts
    462 Views
    No one has replied
  • Voxl 2 mini flashing SDK through raspberry pi 5 bricking voxl

    Unsolved voxl-2-mini
    2
    0 Votes
    2 Posts
    1k Views
    tomT
    @mkriesel It's possible the kernel you're flashing is incorrect. Can you provide the full terminal output of the install?
  • VOXL 2 Mini apps IMU showing "PCB damage" / clock line disconnected

    Unsolved voxl-2-mini
    2
    0 Votes
    2 Posts
    920 Views
    Paul NusserP
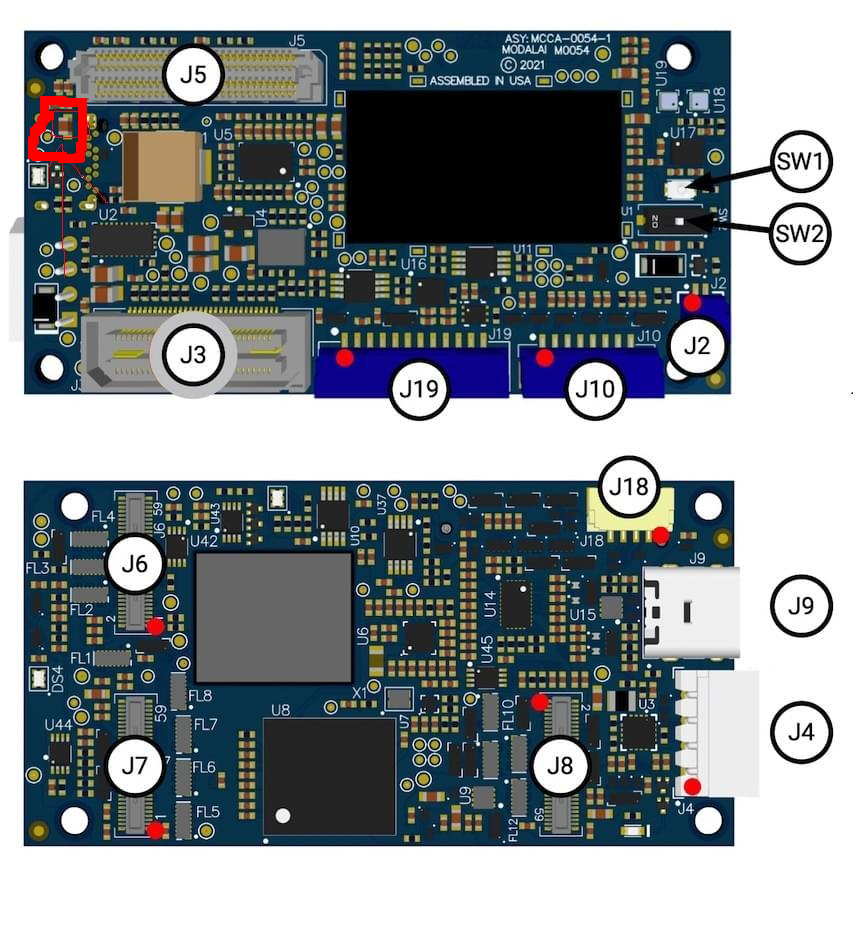
    Hi Cbay, There is a small clock buffer on the edge of the PCB. An RMA can only replace the whole board, not replace a single device. The part to check would be here: [image: 1779297839725-image-1.png]
  • Using Here 4 Blue GPS into J19 on VOXL2 with Ardupilot

    Unsolved voxl-2
    3
    0 Votes
    3 Posts
    1k Views
    R
    Thanks @Eric-Katzfey ! Here is the pinout for the dev board "UART" port that includes i2C_SCL and I2C_SDA. [image: 1778773646212-0cda71eb-2c0f-4b1b-ba91-8b3862fc9763-image.png] The dev board pins 1-6 matching to J19 pins 1-6 We will give the COMPASS_DISBLMSK parameter a shot and see if that works.
  • Mavlink / TFLite / Camera server timestamps

    Unsolved voxl-2
    2
    0 Votes
    2 Posts
    887 Views
    Eric KatzfeyE
    @Plingaas02 Regarding odometry in voxl-mavlink-server, it will not modify timestamps on this message. There will be, potentially, VIO odometry messages going to the flight controller from voxl-vision-hub via voxl-mavlink-server and flight controller odometry messages being routed out to the GCS and to the onboard stream. The odometry messages coming from PX4 will have the DSP monotonic timestamp which is different than the Linux monotonic clock and these will drift with respect to each other over time. PX4 runs the timesync service so it can correct the incoming messages from VIO.
  • AprilTag Localization not affecting static coordinate system

    Unsolved voxl-2
    1
    0 Votes
    1 Posts
    622 Views
    No one has replied
  • Modal AI Schematic Review

    Unsolved voxl-2
    2
    0 Votes
    2 Posts
    1k Views
    VinnyV
    Hi @austin-c Sorry I missed this message somehow. I will email you to kick this off with your team.
  • Moving functions from J19 legacy or high speed B2B

    Unsolved voxl-2
    2
    0 Votes
    2 Posts
    927 Views
    Alex KushleyevA
    @austin-c , The GPS driver is built for SLPI as well as APPS PROC, so you could connect it to a apps-proc UART and start the driver on the apps proc side of PX4. This was done on RB5 : https://docs.modalai.com/Qualcomm-Flight-RB5-linux-user-guide/ https://docs.modalai.com/voxl2-linux-user-guide/ Regarding magnetometer, just like with the GPS driver, you should be able to enable the mag driver to build for apps proc. Since the apps proc i2c uses standard posix interface, it should just work. However, i don't think we have ever tried it. Alex
  • Trigger Hadron camera with DO_SET_CAM_TRIGG_DIST

    Unsolved voxl-2
    6
    0 Votes
    6 Posts
    1k Views
    Eric KatzfeyE
    @restore There are a few examples of code that listens for Mavlink messages in our SDK. For example, in voxl-mpa-tools, take a look at the source code for voxl-inspect-mavlink.c. https://gitlab.com/voxl-public/voxl-sdk/utilities/voxl-mpa-tools/-/blob/master/tools/voxl-inspect-mavlink.c?ref_type=heads Probably would be a good idea to run voxl-inspect-mavlink on the mavlink_onboard and mavlink_to_gcs pipes to see which one has the desired Mavlink message in it. Then create your own application that listens for the Mavlink message on that pipe.
  • MAG SDA 3P3V shorted to ground

    Unsolved voxl-2-mini
    4
    0 Votes
    4 Posts
    975 Views
    Eric KatzfeyE
    @cbay voxl-fpv-px4 is based on voxl-px4 but has some custom tuning code / parameters for our fpv drones that isn't in voxl-px4. So, it's kind of a superset. But there isn't anything related to low level i2c drivers so I have no idea how that could be causing this issue.
  • Recommendations on Custom Build

    Unsolved voxl-2
    1
    0 Votes
    1 Posts
    202 Views
    No one has replied
  • No detections when running custom YOLOv8 model on voxl-tflite-server

    Unsolved voxl-2
    17
    0 Votes
    17 Posts
    2k Views
    A
    Hey @svempati I trained a model in the docker command as provided by you. I am able to run an inference on potholes following exactly the steps provided by @Zachary-Lowell-0 earlier. Could I ask you what your voxl-tflite-version is? And if you havent yet, could you try to run this version: http://voxl-packages.modalai.com/dists/qrb5165/sdk-1.6/binary-arm64/voxl-tflite-server_0.5.1_arm64.deb Make sure to change the .tflite model and labels as shown in the loom video after the install, then run voxl-configure-tflite Thanks
  • Doodle Labs + Low Latency on VTX

    Unsolved voxl-2
    3
    1
    0 Votes
    3 Posts
    530 Views
    DemarconiusD
    @Moderator Thanks for the clarification on the ~50 ms glass-to-glass number. Trying to get a better understanding the performance envelope: 1. Does the 50 ms include RF transport over Doodle, decode, and HDMI output latency, or is that measured only within the VOXL + VRX software stack? 2. Was this measured in point-to-point mode or mesh routing mode? 3. Can you expand on bitrate, resolution, and encoder settings were used (GOP structure, B-frames disabled, UDP vs RTSP)? 4. Is MAVLink or other traffic running on the same link during that measurement? 5. Do you have a latency breakdown per stage (encode / RF / decode / display)? Appreciate any information you can provide. I just want to make sure I can test and validate this effectively.
  • UFS1 Support on J5?

    Unsolved voxl-2
    10
    0 Votes
    10 Posts
    2k Views
    VinnyV
    Hi @wetherbeej Oh yikes.. You should really work with us on that change. There is a high likelihood to damage your VOXL 2 and the MEMs sensors are likely all broken now from the extra reflow cycles. Flash provisioning is all done over QFIL tools, not PCAT.