Skip to content

General Questions

2.3k Topics 11.3k Posts

Not sure where your question goes? Ask here. ModalAI engineers and the community answer questions about any VOXL product.

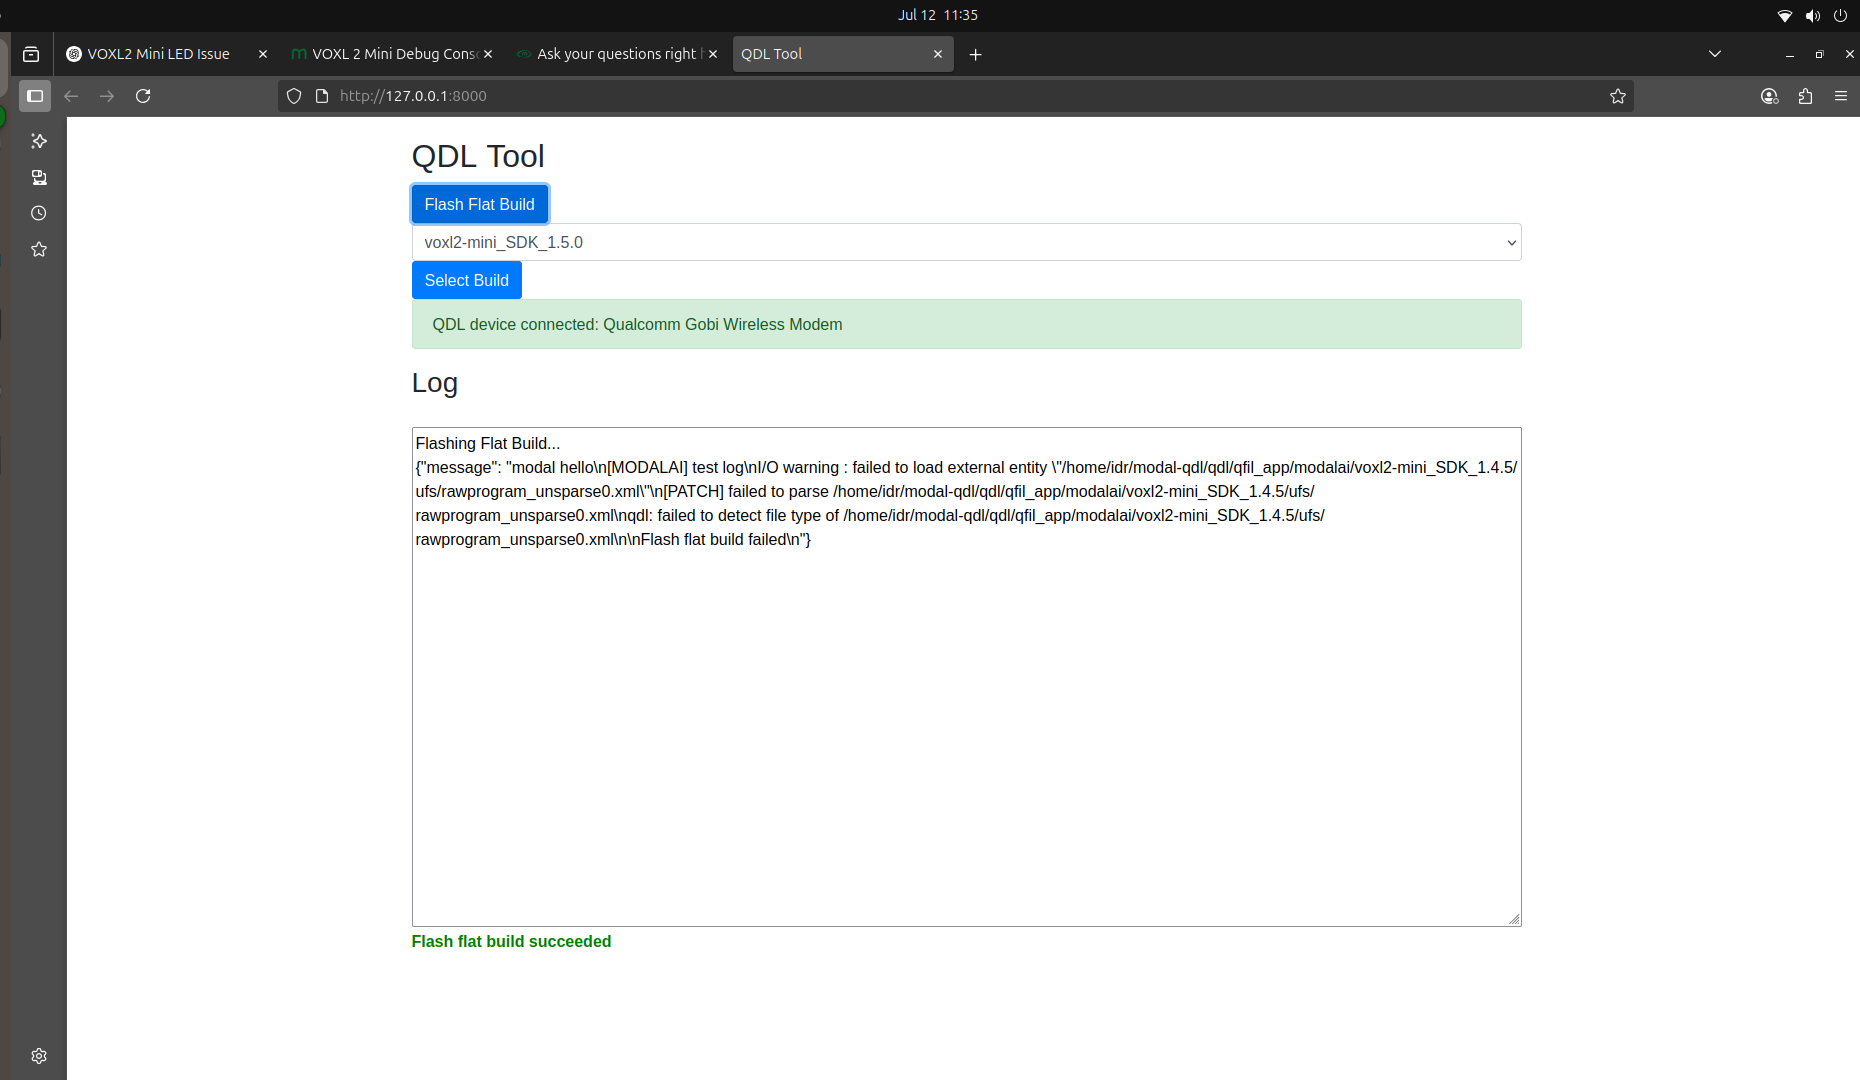
  • VOXL2 Mini Not Detected via ADB/Fastboot – QDL Mode Behavior and Flashing Issues

    Unsolved
    4
    5
    0 Votes
    4 Posts
    817 Views
    P
    @ZuraNeb Please provide the correct link.
  • voxl-io-server won't run

    Unsolved
    5
    0 Votes
    5 Posts
    879 Views
    T
    @Eric-Katzfey I figured out that I did not need it for my project, Thank you thought!
  • tflite GPU usage

    Unsolved
    5
    0 Votes
    5 Posts
    1k Views
    Alex KushleyevA
    @cegeyer , thank you for reporting this. I have never had this issue when checking gpu usage, but will look into it!
  • VOXL2-VOXL2IO-PX4 firmware

    Unsolved
    7
    0 Votes
    7 Posts
    983 Views
    Alex KushleyevA
    @Indra-Jaganathan , Yes, you can just skip the version check in the voxl2_io px4 driver and just hard code that the correct version of M0065 board has been detected, so that the voxl2_io driver can continue, everything should work. You will need to re-build the px4 firmware and install it on voxl2, and after that you can use GCS to set up your actuators for the voxl2_io driver and use actuator test as well. Please let me know if you have any issues with that. Alex
  • imu to camera delay

    Unsolved
    9
    0 Votes
    9 Posts
    1k Views
    Alex KushleyevA
    @yardy , ah, that makes sense!! thank you for clarying. Alex
  • Connecting Video from Voxl 2 to Herelink 1.1

    Unsolved
    4
    0 Votes
    4 Posts
    911 Views
    Idan FikselI
    What have you guys done to stream the video to QGC? do you use a wifi dongle?
  • This topic is deleted!

    1
    5
    0 Votes
    1 Posts
    12 Views
    No one has replied
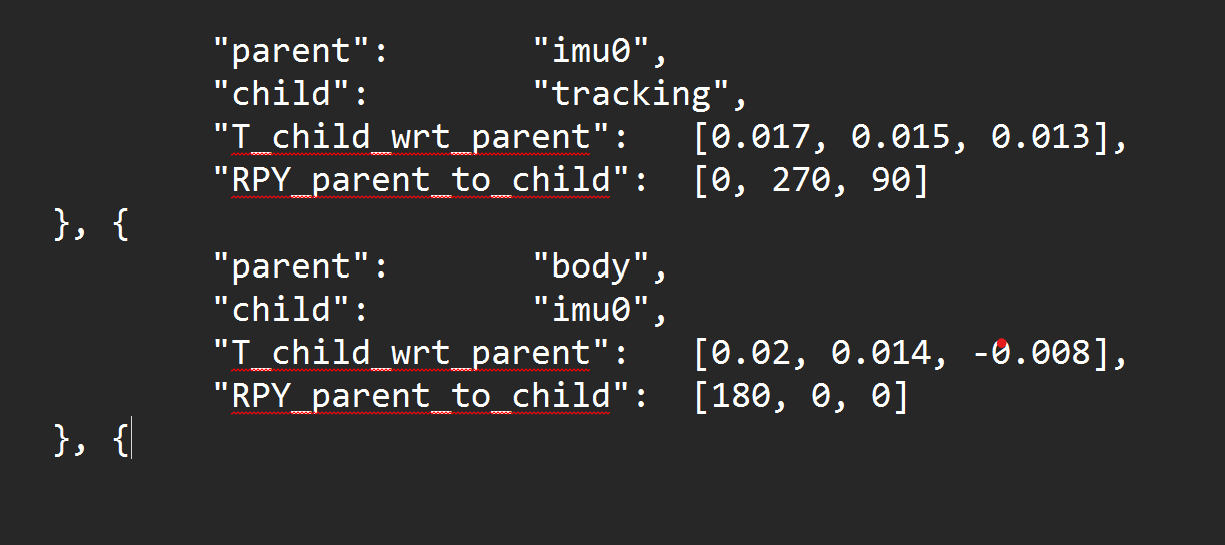
  • Fact Checking my Understanding of the Extrinsic Configuration

    Unsolved
    4
    2
    0 Votes
    4 Posts
    1k Views
    C
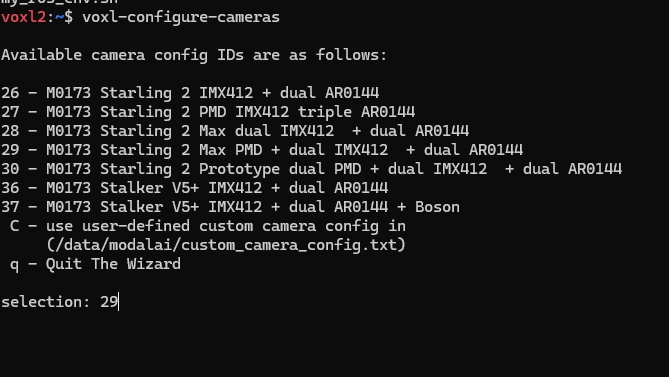
    Updated the SDK to v1.5.0 the problem is still here ¯\(ツ)/¯
  • Longer camera cables

    Unsolved
    1
    0 Votes
    1 Posts
    379 Views
    No one has replied
  • Pinouts for M0188 J10 & J5 connections

    Unsolved
    9
    0 Votes
    9 Posts
    1k Views
    J
    @Alex-Kushleyev That fixed it! Top pin on the M0188 from the view I shared is actually #8, not #1. Thanks for the help!
  • Voxl2 camera RAW

    Unsolved
    6
    0 Votes
    6 Posts
    941 Views
    Alex KushleyevA
    @robertociuch , you can use a tool voxl-record-raw-image which is a part of voxl-mpa-tools package, should be installed by default in the VOXL2 SDK. (see help for details for the tool) This allows you to save any image (whether it is bayer or yuv) at any time from command line. Would that work for you? Alex
  • unable to build voxl-tflite-server in voxl-cross

    Unsolved
    3
    0 Votes
    3 Posts
    655 Views
    P
    @tom that worked, thank you!
  • LIO with TOF LiDAR: Seeking Point Intensity & Noise Data from mpa_to_ros

    Unsolved
    6
    0 Votes
    6 Posts
    1k Views
    J
    @teddy-zaremba Thank you I think Aaron was maybe talking about the depth image that we can get from the tof sensor. I'll check the aligned point cloud but i don't think he has the confidence data (XYZC) Julien
  • Using voxl-configure-mpa erased the parameters_baro_tc.cal file

    Unsolved
    1
    1 Votes
    1 Posts
    366 Views
    No one has replied
  • FLIR Hadron Cable Info Needed

    Unsolved
    3
    0 Votes
    3 Posts
    552 Views
    P
    @Vinny thank you for the informative reply. Cheers
  • Starling 2 Max Motor (0) Not Operational

    Unsolved
    7
    0 Votes
    7 Posts
    1k Views
    Alex KushleyevA
    @daz_22 , thanks for sending the output of the spin script. Just to note, the RPMs are reported as ramping up to around 1000 (by the end of the printout) because during the initial phase (spin-up), the ESC operates in open loop mode, where it drives the motor but does not detect the actual speed. During spin-up the predicted RPM is printed, but it could be false, if the motor is stuck or not even attached. The closed-loop control starts after the smooth spin-up, where the true RPM is reported (however you did not provide those prints, but i suspect the ID0 would just try to restart based on the reported RPM). The MCU in the ESC channel 0 seems to be functional and communicating, so that is good. However, the motor not spinning is not good. From software side, everything looks normal. If you believe that the Starling 2 Max arrived with non-functional ESC / wiring (who knows?), you should submit an RMA request in order to correct the situation. modalai.com/rma . If you think the issue might have been caused due to a crash or something like that and you wish us to fix it, you may still submit the RMA request. Alternatively, you could disassemble the drone to gain access to the ESC and see if you can visually detect the issue with the ESC or wiring. Either ESC channel 0 or wiring seems faulty. Please let me know if you have any other questions. Alex
  • Microhard modem is not bring reconized on laptop

    Unsolved
    4
    0 Votes
    4 Posts
    802 Views
    tomT
    @wrossi17 Can you post a photo of your setup?
  • Google Fi

    Unsolved
    3
    0 Votes
    3 Posts
    550 Views
    Matthew WellnerM
    @bendraper I'm not sure if this is still an issue for you, but you need to get a SIM specifically for data from here: https://fi.google.com/data - After they ship it to you, you can activate it through your Google Fi account using the instructions/activation code that come with the SIM.
  • Quectel-CM error when Initializing a connection (SDK 1.5.0)

    Unsolved
    2
    0 Votes
    2 Posts
    700 Views
    Matthew WellnerM
    I grabbed the /usr/bin/quectel-CM from another VOXL2 on an older SDK (1.4.1) and swapped out the one that came with 1.5.0 and everything is working again...
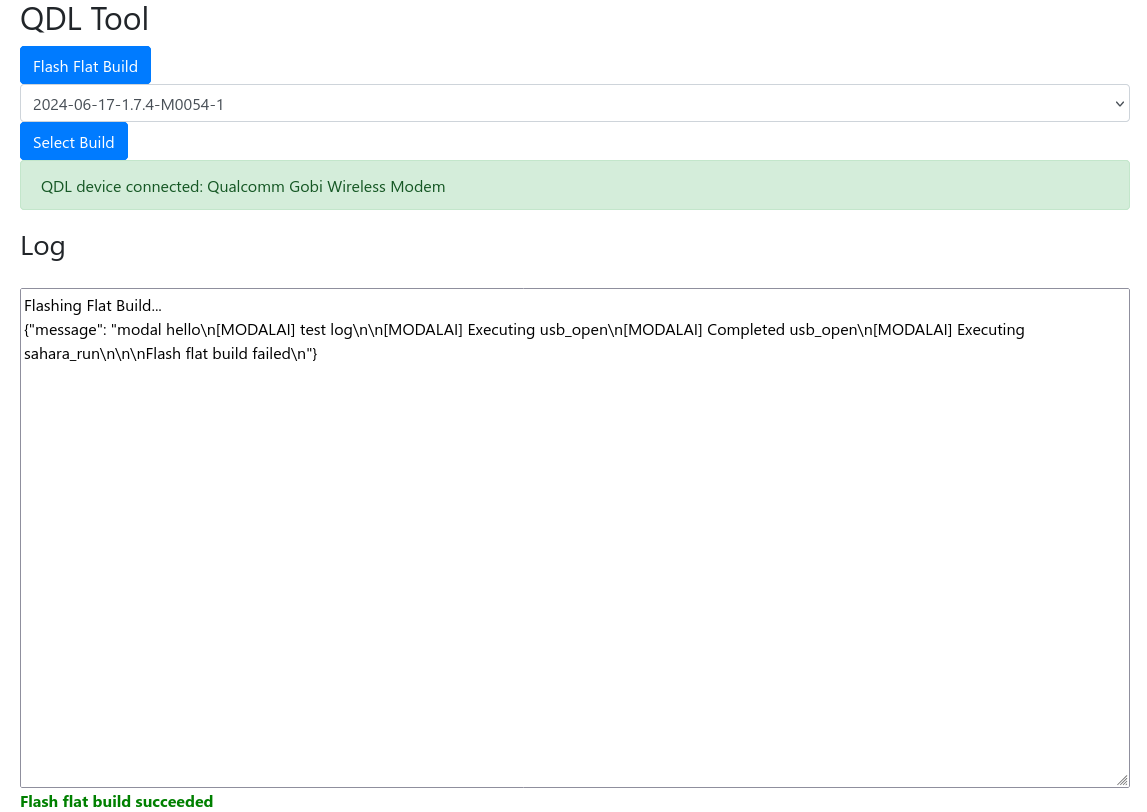
  • Flash Flat Build Fails During sahara_run on M0054-1 (VOXL 2)

    Unsolved
    1
    1
    0 Votes
    1 Posts
    279 Views
    No one has replied