Skip to content
  • Categories
  • Recent
  • Tags
  • Popular
  • Users
  • Groups
Collapse
Brand Logo

ModalAI Forum

  1. ModalAI Support Forum
  2. VOXL SDK and Software
  3. m500 VOXL Flight sdk update to v1.1.x

m500 VOXL Flight sdk update to v1.1.x

Scheduled Pinned Locked Moved Unsolved VOXL SDK and Software
voxl-sdk
26 Posts 4 Posters 10.4k Views 2 Watching
  • Oldest to Newest
  • Newest to Oldest
  • Most Votes
Reply
  • Reply as topic
Log in to reply
This topic has been deleted. Only users with topic management privileges can see it.
  • ModeratorM Moderator

    @Darshit-Desai You are correct, you should use Flight Core v1 instructions for the Flight Core portion of VOXL Flight.

    https://docs.modalai.com/flight-core-firmware/#px4-v114

    Darshit DesaiD Offline
    Darshit DesaiD Offline
    Darshit Desai
    Regular
    wrote on last edited by Darshit Desai
    #3

    @Moderator Is the update procedure the same as this one for v1.14 firmware?

    https://docs.modalai.com/update-flight-core-firmware/#update-procedure

    Also since I dont have the desired cable if I want to fallback to v0.9.5 I don't need to change anything in the firmware right?

    Also when I try to go back v0.9.5 sdk and configure my qvio it always shows this error.

    / # voxl-configure-qvio
    Starting Wizard
     
    Do you want to reset the config file to factory defaults?
    1) yes
    2) no
    #? 1
    wiping old config file
    loading config file
    Creating new config file: /etc/modalai/voxl-qvio-server.conf
     
    Do you want to enable the voxl-qvio-server service to allow
    visual inertial odometry?
    1) yes
    2) no
    #? 1
     
    Now we are going to do a preliminary configuration of /etc/modalai/voxl-qvio-server.conf
     
    Which config voxl-qvio-server use?
    
    imu0_tracking          for VOXL Flight all-in-one board, M500
    imu1_tracking          for VOXL1 and VOXL-CAM, Seeker V1
    imu_px4_tracking       for RB5 Flight 5G
    imu_apps_tracking      for VOXL2, Sentinel
    imu_apps_stereo_lower  for Starling V2 stereo version
    
    1) imu0_tracking	  3) imu_px4_tracking	    5) imu_apps_stereo_lower
    2) imu1_tracking	  4) imu_apps_tracking
    #? 1
    enabling  voxl-qvio-server systemd service
    starting  voxl-qvio-server systemd service
    Done configuring voxl-qvio-server
    / # voxl-inspect-qvio 
    waiting for server
    
     dt(ms) |    T_imu_wrt_vio (m)   |Roll Pitch Yaw (deg)|features|quality| state| error_codes |
       30.2 |    0.00    0.00    0.00|   0.0   -0.0    0.0|     0  |   -1% | FAIL | IMU_MISSING STALLED ^C
    received SIGINT Ctrl-C
    
    closing and exiting
    / #
    
    ModeratorM 1 Reply Last reply
    0
    • Darshit DesaiD Darshit Desai

      @Moderator Is the update procedure the same as this one for v1.14 firmware?

      https://docs.modalai.com/update-flight-core-firmware/#update-procedure

      Also since I dont have the desired cable if I want to fallback to v0.9.5 I don't need to change anything in the firmware right?

      Also when I try to go back v0.9.5 sdk and configure my qvio it always shows this error.

      / # voxl-configure-qvio
      Starting Wizard
       
      Do you want to reset the config file to factory defaults?
      1) yes
      2) no
      #? 1
      wiping old config file
      loading config file
      Creating new config file: /etc/modalai/voxl-qvio-server.conf
       
      Do you want to enable the voxl-qvio-server service to allow
      visual inertial odometry?
      1) yes
      2) no
      #? 1
       
      Now we are going to do a preliminary configuration of /etc/modalai/voxl-qvio-server.conf
       
      Which config voxl-qvio-server use?
      
      imu0_tracking          for VOXL Flight all-in-one board, M500
      imu1_tracking          for VOXL1 and VOXL-CAM, Seeker V1
      imu_px4_tracking       for RB5 Flight 5G
      imu_apps_tracking      for VOXL2, Sentinel
      imu_apps_stereo_lower  for Starling V2 stereo version
      
      1) imu0_tracking	  3) imu_px4_tracking	    5) imu_apps_stereo_lower
      2) imu1_tracking	  4) imu_apps_tracking
      #? 1
      enabling  voxl-qvio-server systemd service
      starting  voxl-qvio-server systemd service
      Done configuring voxl-qvio-server
      / # voxl-inspect-qvio 
      waiting for server
      
       dt(ms) |    T_imu_wrt_vio (m)   |Roll Pitch Yaw (deg)|features|quality| state| error_codes |
         30.2 |    0.00    0.00    0.00|   0.0   -0.0    0.0|     0  |   -1% | FAIL | IMU_MISSING STALLED ^C
      received SIGINT Ctrl-C
      
      closing and exiting
      / #
      
      ModeratorM Offline
      ModeratorM Offline
      Moderator
      ModalAI Team
      wrote on last edited by
      #4

      @Darshit-Desai your firmware should match what was used in the SDK, they are paired together

      why would you go to SDK 0.9.5? It is really old and no longer supported

      Darshit DesaiD 1 Reply Last reply
      0
      • ModeratorM Moderator

        @Darshit-Desai your firmware should match what was used in the SDK, they are paired together

        why would you go to SDK 0.9.5? It is really old and no longer supported

        Darshit DesaiD Offline
        Darshit DesaiD Offline
        Darshit Desai
        Regular
        wrote on last edited by
        #5

        @Moderator I don't have the usb-jst connector for the firmware update and I think 0.95 that was the original factory sdk version

        Darshit DesaiD 1 Reply Last reply
        0
        • Darshit DesaiD Darshit Desai

          @Moderator I don't have the usb-jst connector for the firmware update and I think 0.95 that was the original factory sdk version

          Darshit DesaiD Offline
          Darshit DesaiD Offline
          Darshit Desai
          Regular
          wrote on last edited by
          #6

          @Moderator

          @Moderator said in m500 VOXL Flight sdk update to v1.1.x:

          your firmware should match what was used in the SDK, they are paired together

          What firmware matches the voxl-1 sdk 1.1.2 version

          Darshit DesaiD 1 Reply Last reply
          0
          • Darshit DesaiD Darshit Desai

            @Moderator

            @Moderator said in m500 VOXL Flight sdk update to v1.1.x:

            your firmware should match what was used in the SDK, they are paired together

            What firmware matches the voxl-1 sdk 1.1.2 version

            Darshit DesaiD Offline
            Darshit DesaiD Offline
            Darshit Desai
            Regular
            wrote on last edited by
            #7

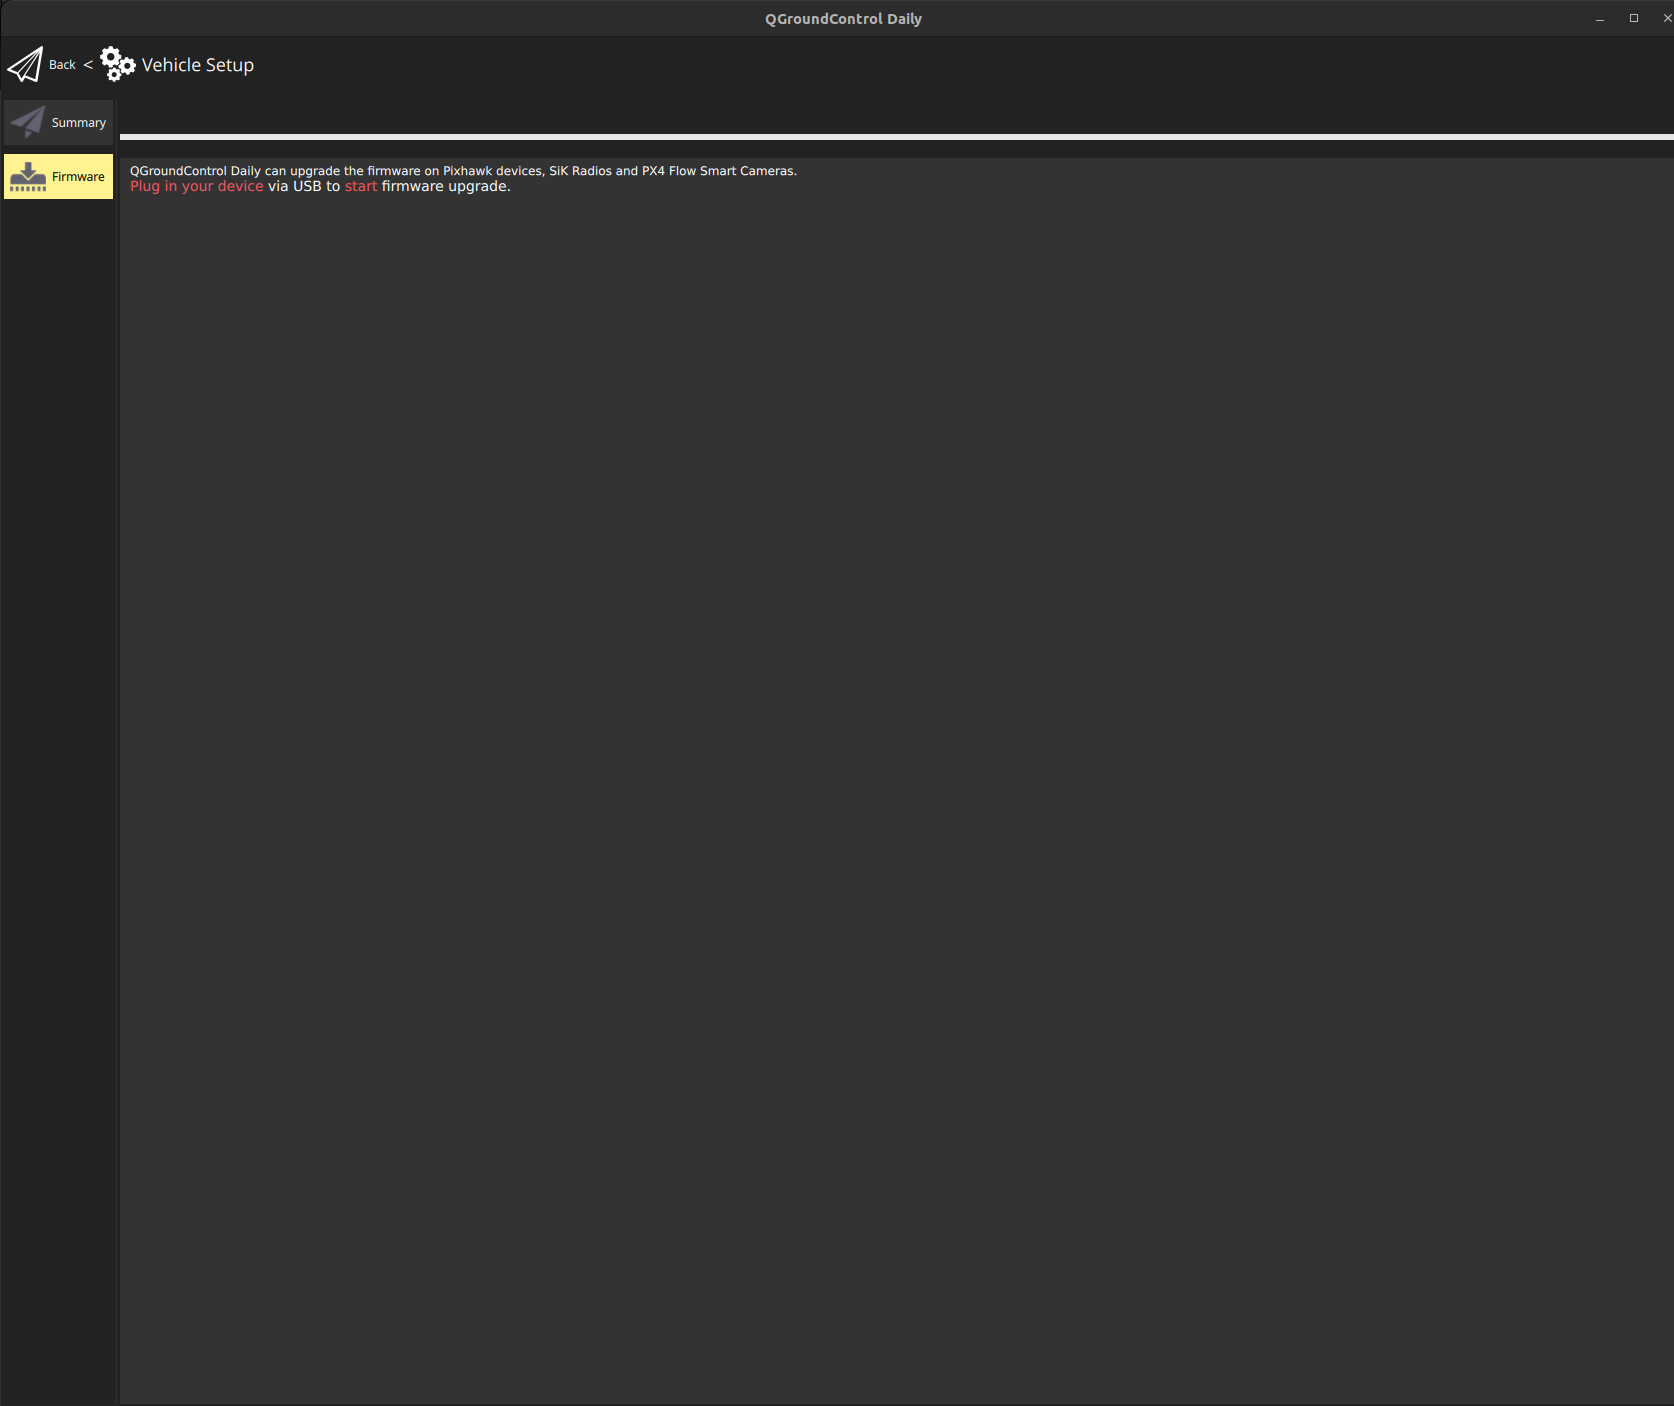
            @Moderator I have got the cable for flight core update, I upgraded the sdk to 1.1.2 again but then I am following the instructions as shown in the below but nothing shows up in the firmware tab

            https://docs.modalai.com/update-flight-core-firmware/#update-using-qgroundcontrol---mainline-builds
            944c8d72-c319-474a-8141-a5e41b310c75-image.png

            tomT 1 Reply Last reply
            0
            • Darshit DesaiD Darshit Desai

              @Moderator I have got the cable for flight core update, I upgraded the sdk to 1.1.2 again but then I am following the instructions as shown in the below but nothing shows up in the firmware tab

              https://docs.modalai.com/update-flight-core-firmware/#update-using-qgroundcontrol---mainline-builds

              944c8d72-c319-474a-8141-a5e41b310c75-image.png

              tomT Offline
              tomT Offline
              tom
              admin
              wrote on last edited by tom
              #8

              @Darshit-Desai The .px4 file is in the SDK release zip:

              for FCv1: voxl_SDK_1.1.2/flight-core/modalai_fc-v1_1.14.0-2.0.63.px4

              Follow the instructions here (ModalAI Build) with the above .px4 file:

              https://docs.modalai.com/update-flight-core-firmware/#update-using-qgroundcontrol---modalai-build

              Darshit DesaiD 1 Reply Last reply
              0
              • tomT tom

                @Darshit-Desai The .px4 file is in the SDK release zip:

                for FCv1: voxl_SDK_1.1.2/flight-core/modalai_fc-v1_1.14.0-2.0.63.px4

                Follow the instructions here (ModalAI Build) with the above .px4 file:

                https://docs.modalai.com/update-flight-core-firmware/#update-using-qgroundcontrol---modalai-build

                Darshit DesaiD Offline
                Darshit DesaiD Offline
                Darshit Desai
                Regular
                wrote on last edited by Darshit Desai
                #9

                @tom Yes but in the firmware page nothing shows up in QGC

                @tom said in m500 VOXL Flight sdk update to v1.1.x:

                https://docs.modalai.com/update-flight-core-firmware/#update-using-qgroundcontrol---modalai-build

                tomT 1 Reply Last reply
                0
                • Darshit DesaiD Darshit Desai

                  @tom Yes but in the firmware page nothing shows up in QGC

                  @tom said in m500 VOXL Flight sdk update to v1.1.x:

                  https://docs.modalai.com/update-flight-core-firmware/#update-using-qgroundcontrol---modalai-build

                  tomT Offline
                  tomT Offline
                  tom
                  admin
                  wrote on last edited by
                  #10

                  @Darshit-Desai Did you unplug power and re-connect power while keeping USB attached?

                  Darshit DesaiD 1 Reply Last reply
                  0
                  • tomT tom

                    @Darshit-Desai Did you unplug power and re-connect power while keeping USB attached?

                    Darshit DesaiD Offline
                    Darshit DesaiD Offline
                    Darshit Desai
                    Regular
                    wrote on last edited by Darshit Desai
                    #11

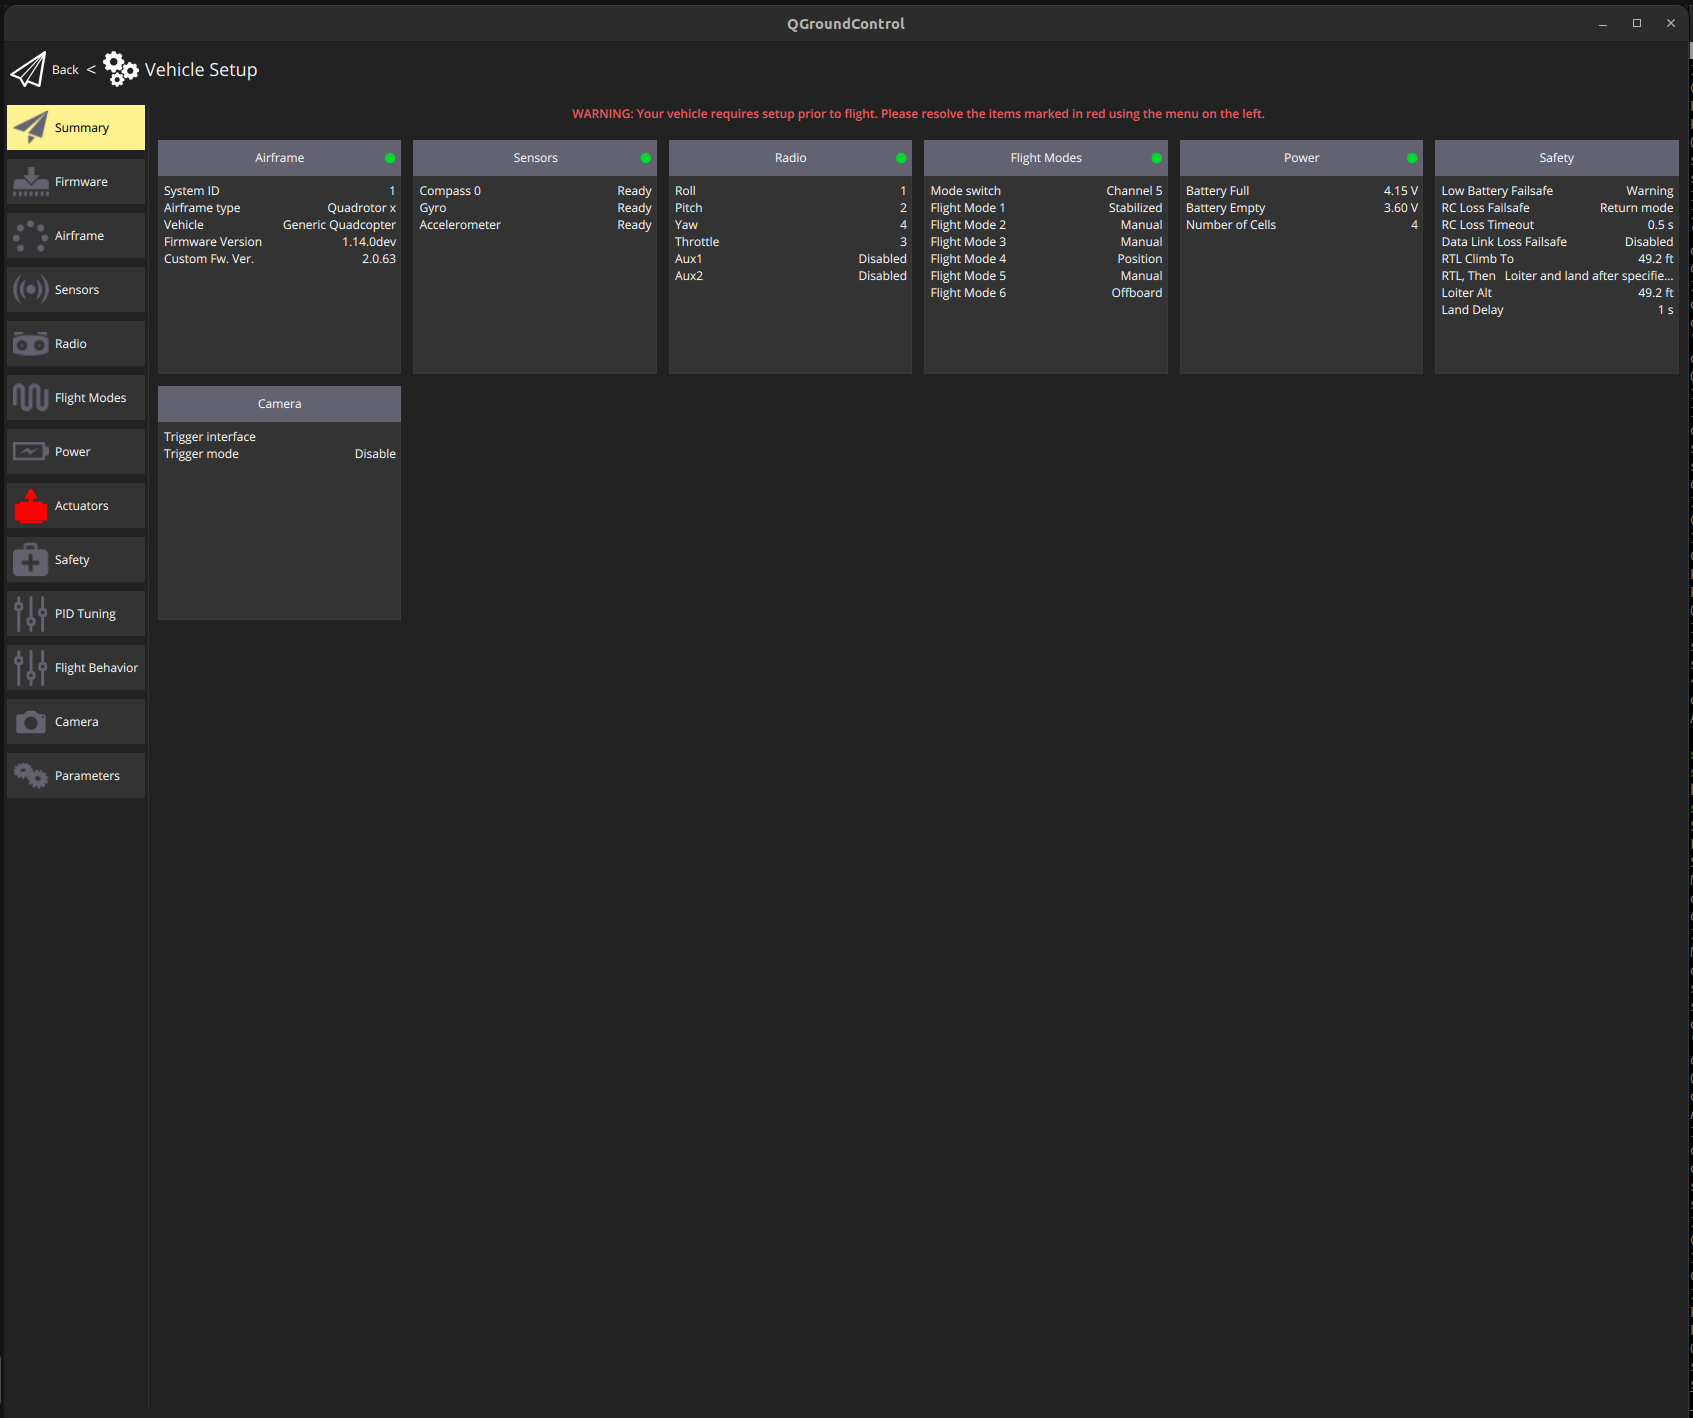
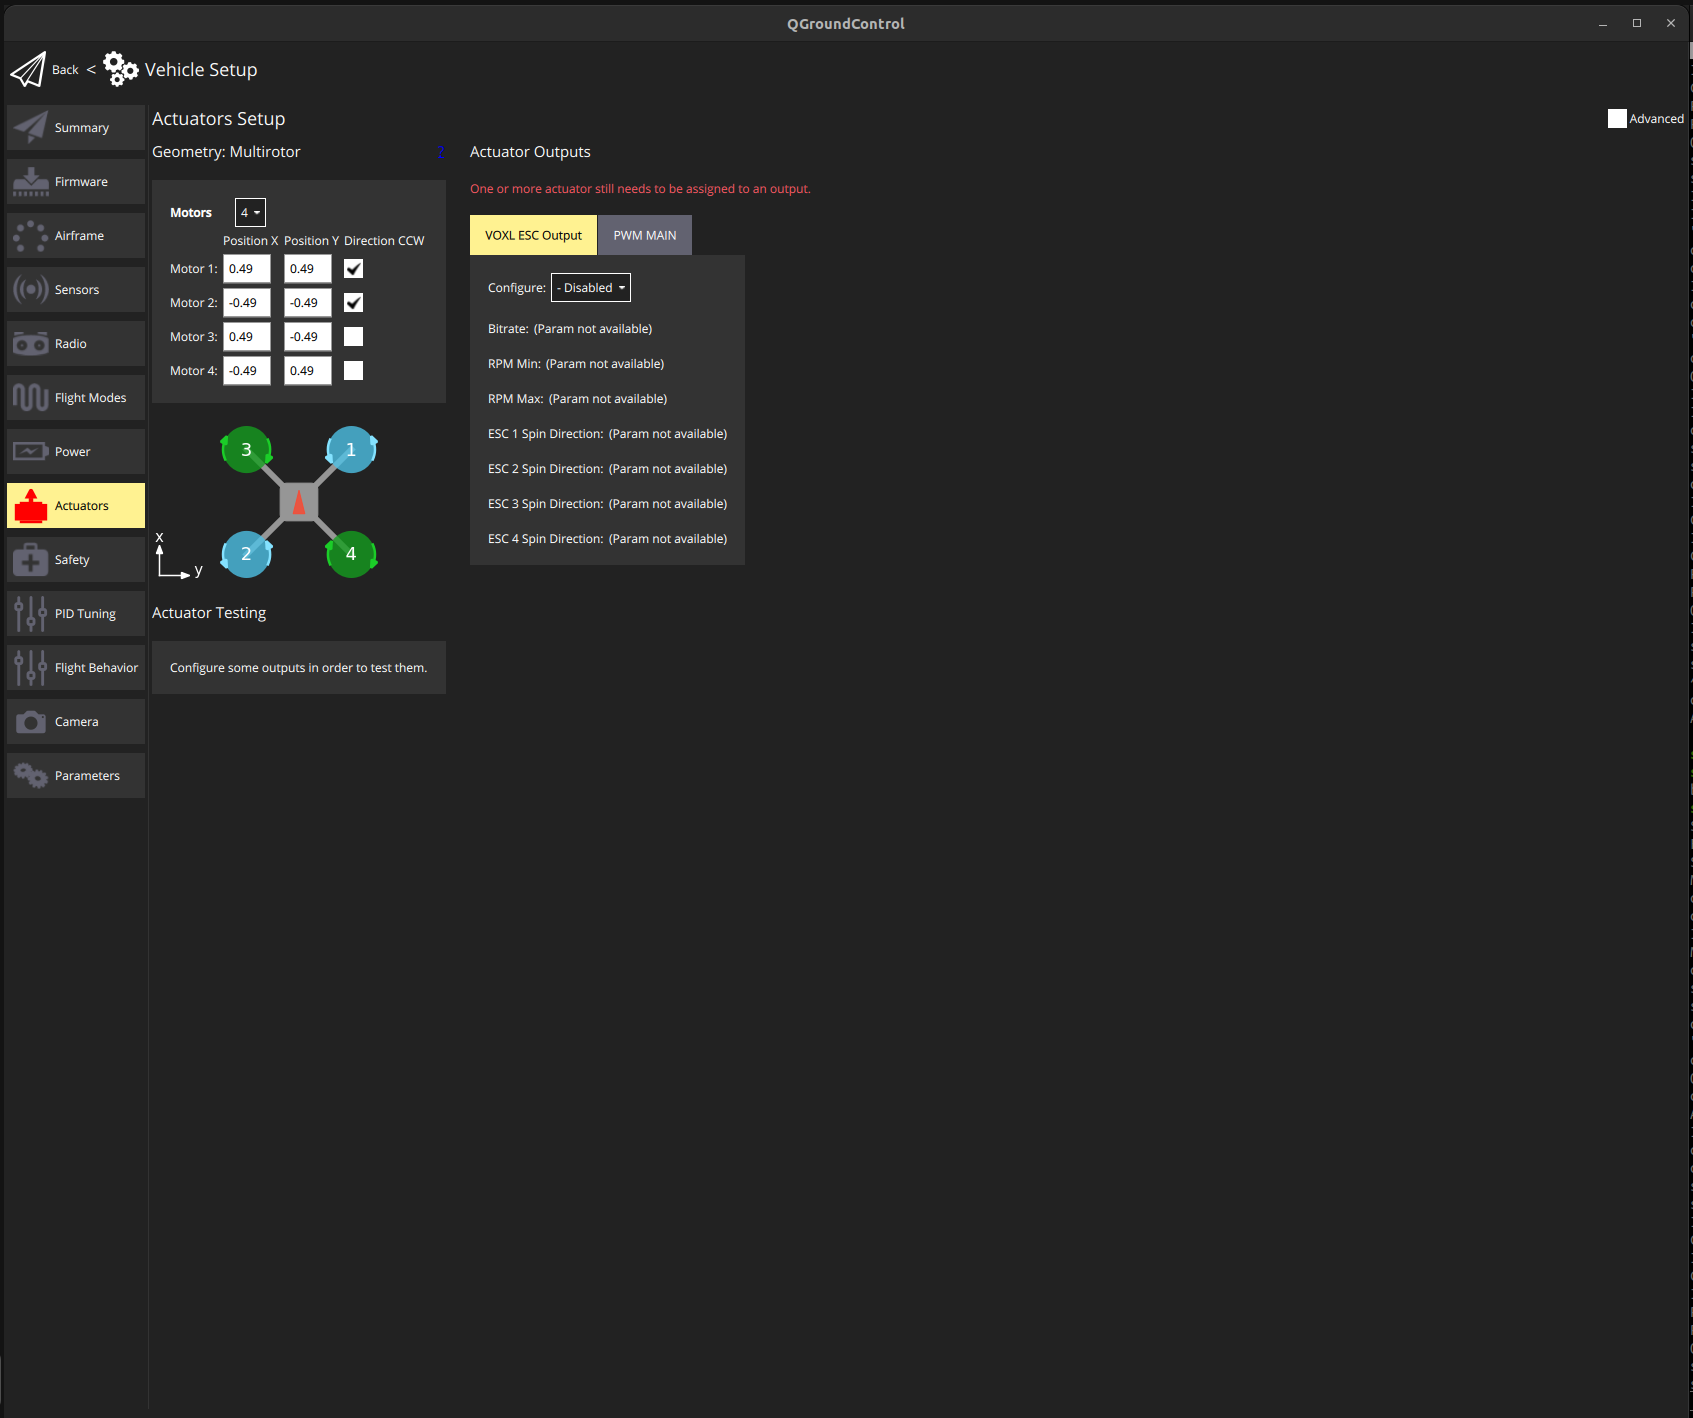
                    @tom I was able to finish the upgrade, but in QGC it shows something about actuators, when I open it opens the esc calibration related page, Do I need to calibrate esc again?
                    7010e546-8d10-4fd0-ab00-f75e514611fc-image.png

                    d038d013-92ff-4af5-b96e-6b71e8e685ad-image.png

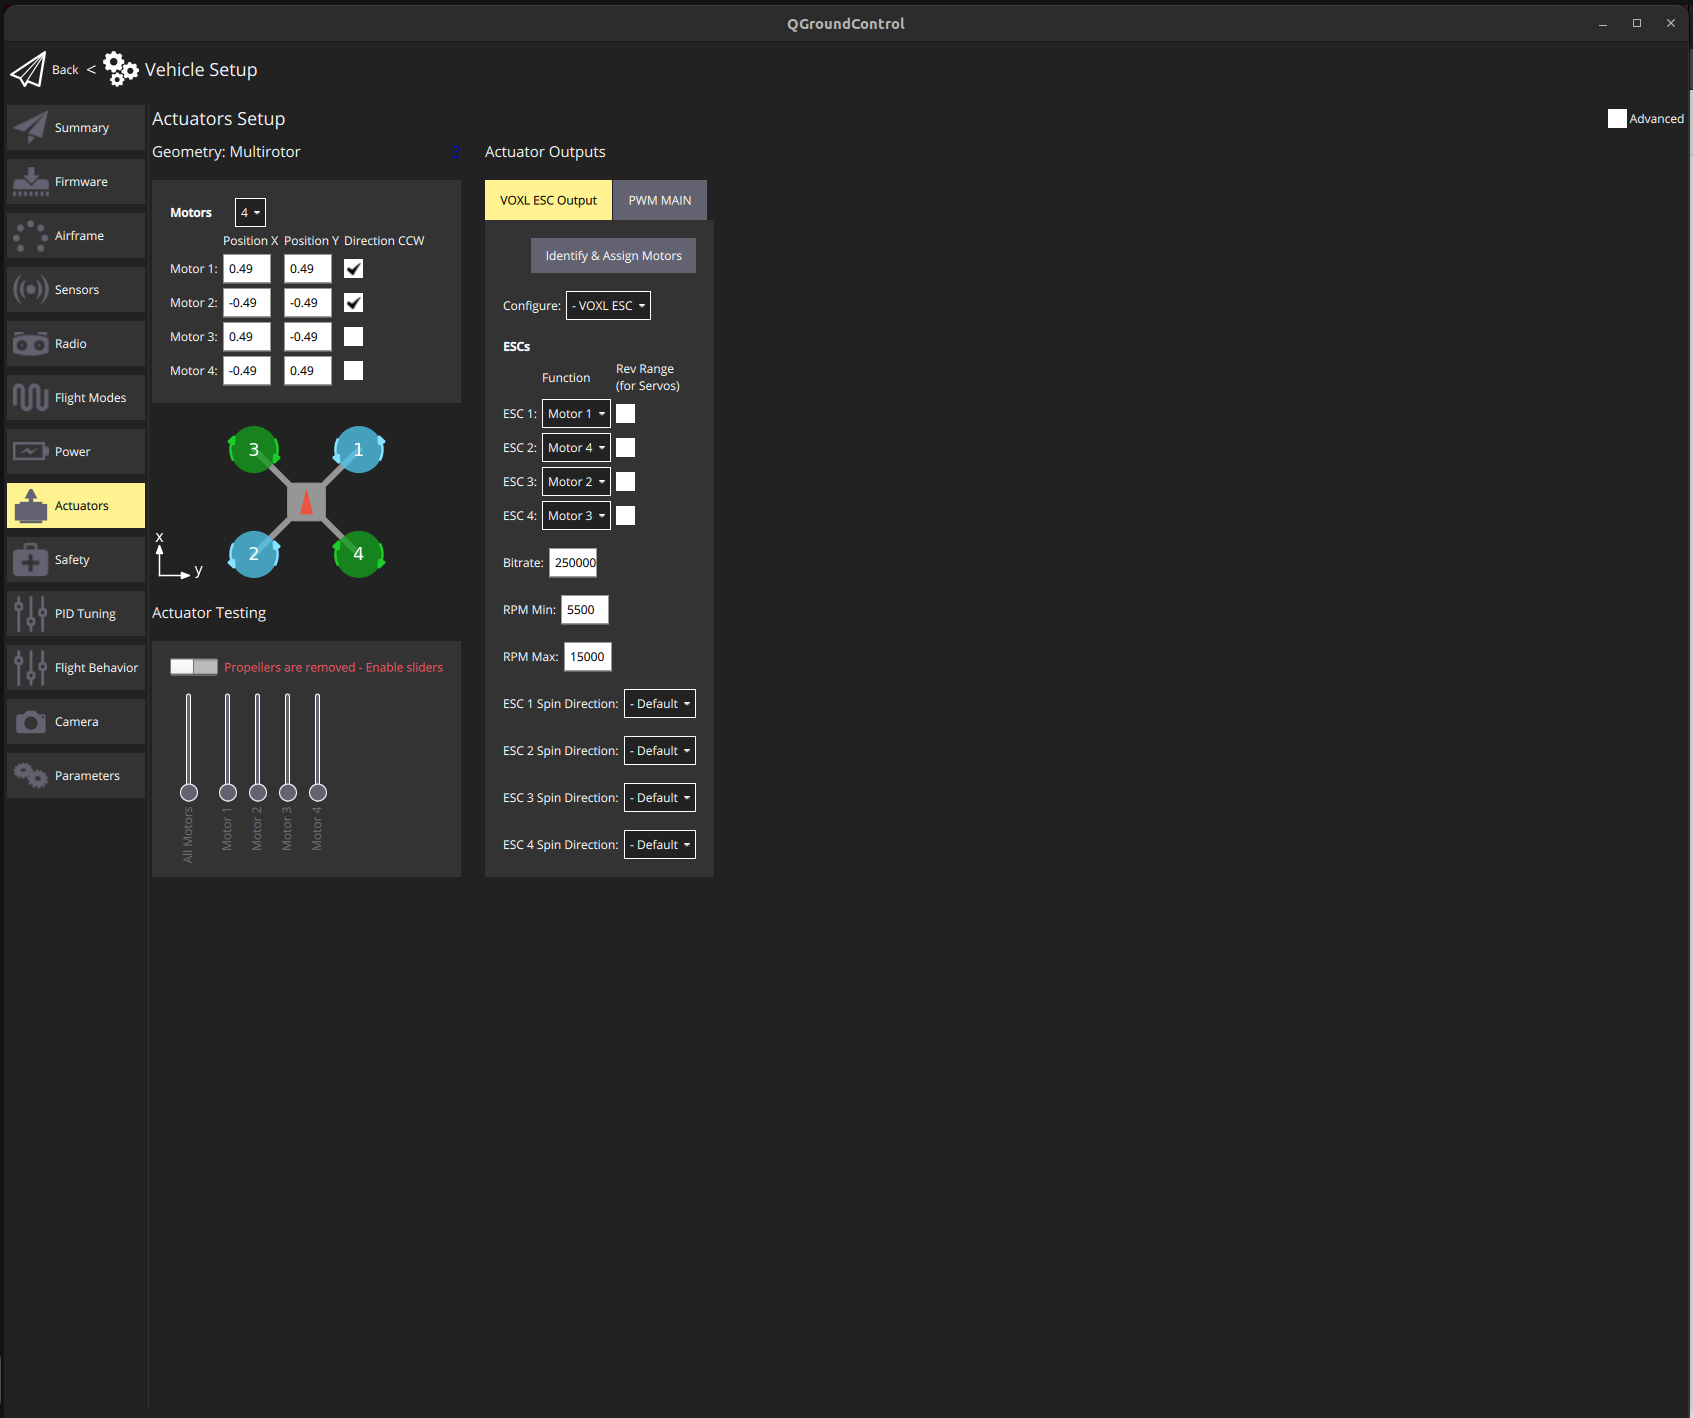
                    Edit: I found this page (https://docs.modalai.com/modal-esc-px4-user-guide/) on ESCs and added the parameters accordingly, the only ones I don't know are the min and max RPM, I am using the voxl 1 m500 with holybro 2216-920kv motors. Also I don't think the motors rotate when I try to using the sliders
                    e4a13997-c405-42af-a8a5-4b56e84ccb89-image.png

                    tomT 1 Reply Last reply
                    0
                    • Darshit DesaiD Darshit Desai

                      @tom I was able to finish the upgrade, but in QGC it shows something about actuators, when I open it opens the esc calibration related page, Do I need to calibrate esc again?

                      7010e546-8d10-4fd0-ab00-f75e514611fc-image.png

                      d038d013-92ff-4af5-b96e-6b71e8e685ad-image.png

                      Edit: I found this page (https://docs.modalai.com/modal-esc-px4-user-guide/) on ESCs and added the parameters accordingly, the only ones I don't know are the min and max RPM, I am using the voxl 1 m500 with holybro 2216-920kv motors. Also I don't think the motors rotate when I try to using the sliders

                      e4a13997-c405-42af-a8a5-4b56e84ccb89-image.png

                      tomT Offline
                      tomT Offline
                      tom
                      admin
                      wrote on last edited by tom
                      #12

                      @Darshit-Desai ~~Can you try loading the FCv1 m500 params from here: https://gitlab.com/voxl-public/voxl-sdk/utilities/voxl-px4-params/-/blob/master/params/v1.14/platforms/M500_FCV1.param~~s

                      Darshit DesaiD 1 Reply Last reply
                      0
                      • tomT tom

                        @Darshit-Desai ~~Can you try loading the FCv1 m500 params from here: https://gitlab.com/voxl-public/voxl-sdk/utilities/voxl-px4-params/-/blob/master/params/v1.14/platforms/M500_FCV1.param~~s

                        Darshit DesaiD Offline
                        Darshit DesaiD Offline
                        Darshit Desai
                        Regular
                        wrote on last edited by
                        #13

                        @tom V1 or V2? Because when I flash firmware it detects v2
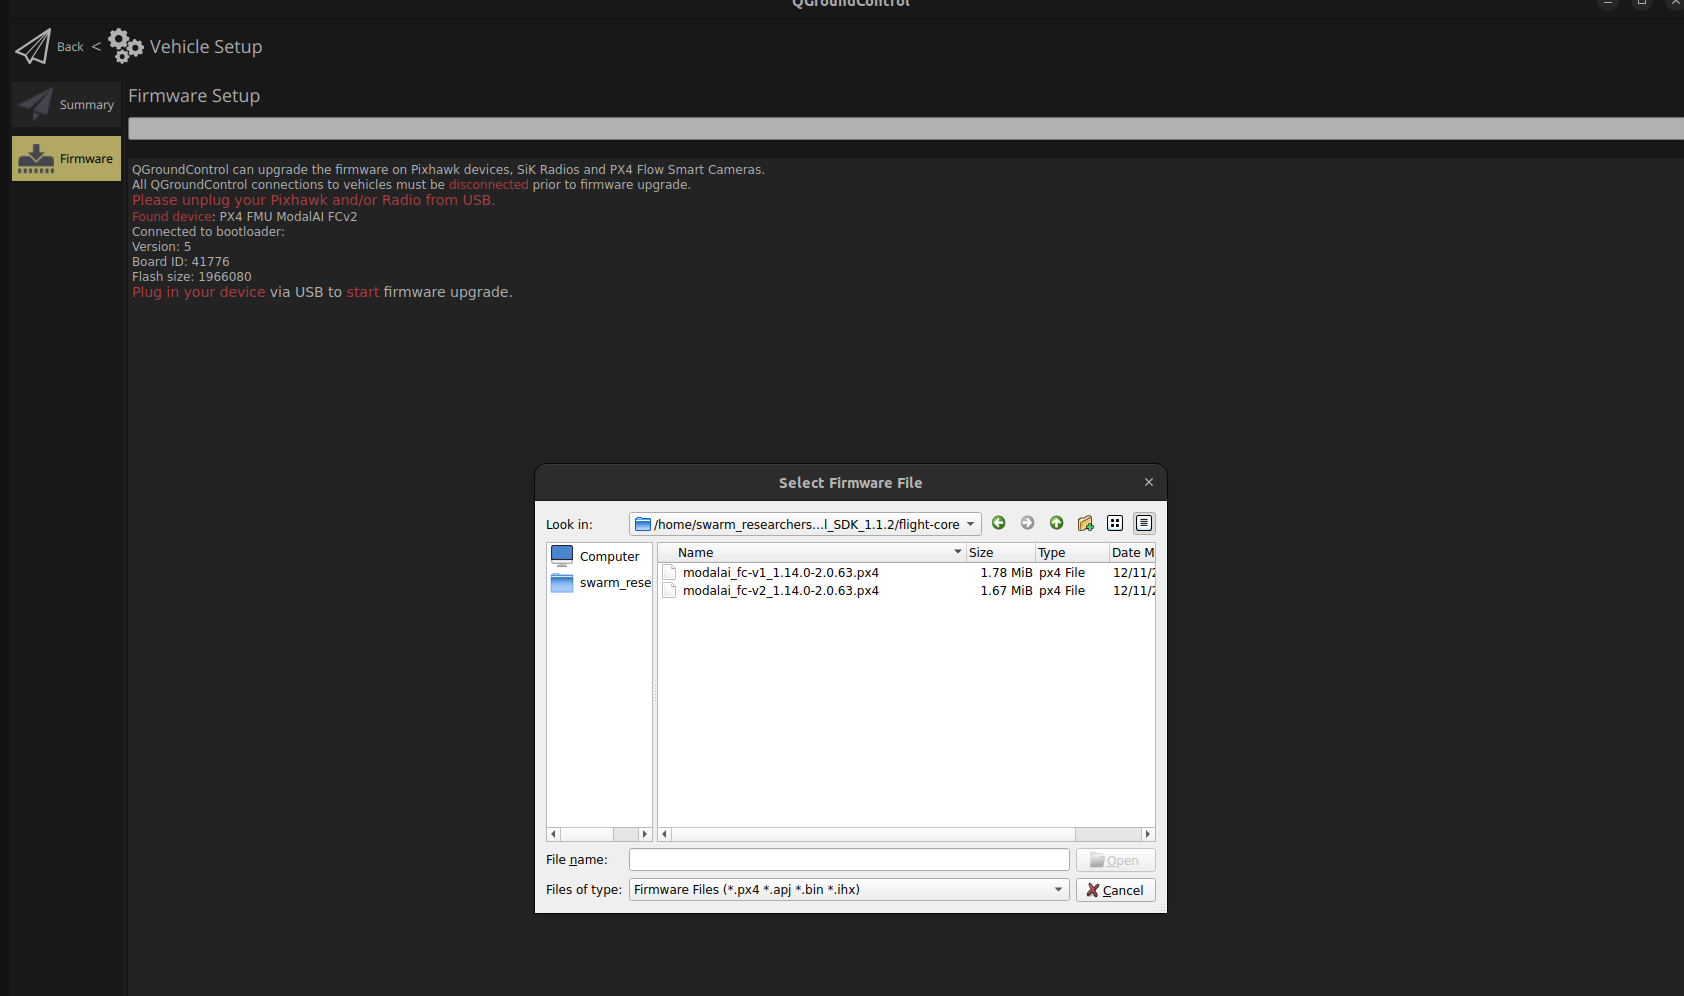
                        6bee05a3-cd22-4d3d-b67e-858f5c631c3b-image.png

                        tomT 1 Reply Last reply
                        0
                        • Darshit DesaiD Darshit Desai

                          @tom V1 or V2? Because when I flash firmware it detects v2

                          6bee05a3-cd22-4d3d-b67e-858f5c631c3b-image.png

                          tomT Offline
                          tomT Offline
                          tom
                          admin
                          wrote on last edited by
                          #14

                          @Darshit-Desai Sorry yes v2 https://gitlab.com/voxl-public/voxl-sdk/utilities/voxl-px4-params/-/blob/master/params/v1.14/platforms/M500_FCV2.params

                          tomT 1 Reply Last reply
                          0
                          • tomT tom

                            @Darshit-Desai Sorry yes v2 https://gitlab.com/voxl-public/voxl-sdk/utilities/voxl-px4-params/-/blob/master/params/v1.14/platforms/M500_FCV2.params

                            tomT Offline
                            tomT Offline
                            tom
                            admin
                            wrote on last edited by
                            #15

                            @tom It's hard for me to follow which hardware you have, so whichever one you have v1 or v2

                            Darshit DesaiD 1 Reply Last reply
                            0
                            • tomT tom

                              @tom It's hard for me to follow which hardware you have, so whichever one you have v1 or v2

                              Darshit DesaiD Offline
                              Darshit DesaiD Offline
                              Darshit Desai
                              Regular
                              wrote on last edited by Darshit Desai
                              #16

                              @tom Yes I am also not sure what came with m500 I recently bought because the earlier ones had v1

                              Edit: The motor issue was resolved with this and I can spin the motors, I will have a flight with the propellers and confirm it

                              Darshit DesaiD 1 Reply Last reply
                              0
                              • Darshit DesaiD Darshit Desai

                                @tom Yes I am also not sure what came with m500 I recently bought because the earlier ones had v1

                                Edit: The motor issue was resolved with this and I can spin the motors, I will have a flight with the propellers and confirm it

                                Darshit DesaiD Offline
                                Darshit DesaiD Offline
                                Darshit Desai
                                Regular
                                wrote on last edited by Darshit Desai
                                #17

                                @tom On the next reboot it's showing esc failure in the logs

                                [13:38:12.651] Info: Kill-switch engaged
                                [13:38:13.768] Info: Kill-switch disengaged
                                [13:39:33.963] Info: Armed by RC
                                [13:39:34.096] Info: logging: opening log file sess114/log100.ulg
                                [13:39:34.296] Critical: Failsafe activated, triggering disarm
                                ESC failure
                                [13:39:34.296] Info: Disarmed by failsafe
                                [13:39:36.780] Info: Armed by RC
                                [13:39:36.781] Info: logging: opening log file sess114/log101.ulg
                                [13:39:37.131] Critical: Failsafe activated, triggering disarm
                                [13:39:37.131] Info: Disarmed by failsafe
                                [13:39:39.424] Info: Armed by RC
                                [13:39:39.465] Info: logging: opening log file sess114/log102.ulg
                                [13:39:39.787] Critical: Failsafe activated, triggering disarm
                                [13:39:39.787] Info: Disarmed by failsafe

                                And the motors try to spin up for a few seconds when arming and then instantly stop

                                When I move this sliders now the motors rotate but when I try to arm the drone using RC it shows the ESC failure error
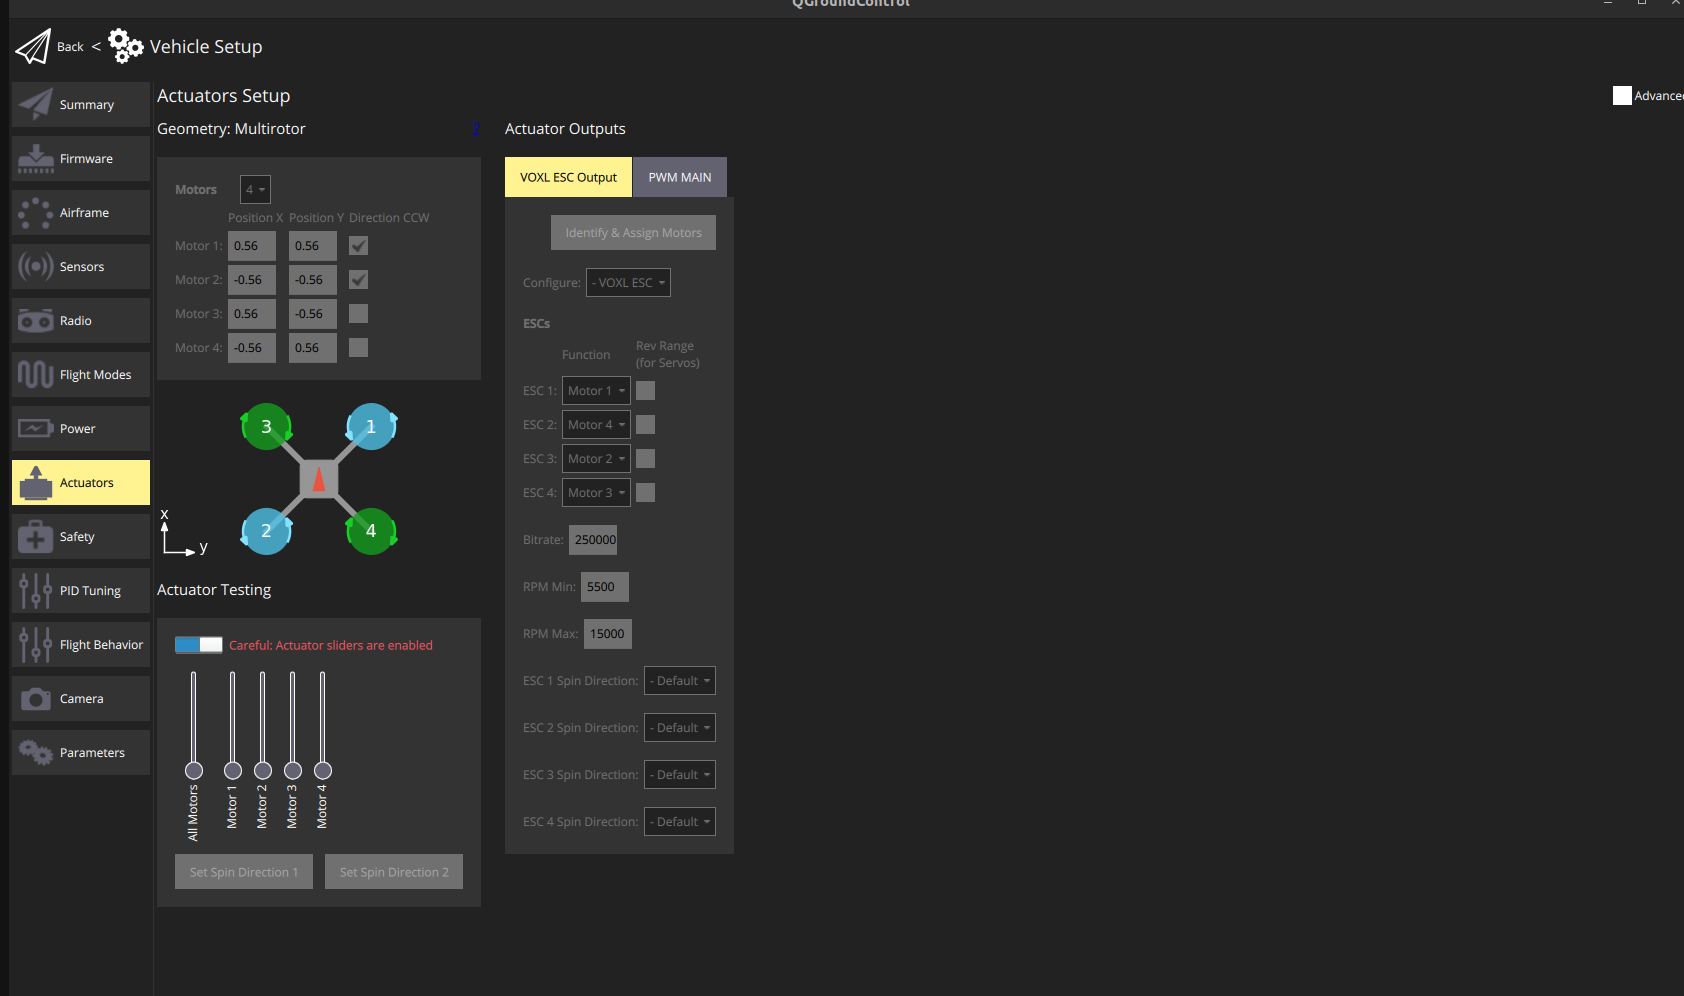
                                a646b685-77d0-4ba3-8d65-72af8e7870ae-image.png

                                tomT 1 Reply Last reply
                                0
                                • Darshit DesaiD Darshit Desai referenced this topic on
                                • Darshit DesaiD Darshit Desai

                                  @tom On the next reboot it's showing esc failure in the logs

                                  [13:38:12.651] Info: Kill-switch engaged
                                  [13:38:13.768] Info: Kill-switch disengaged
                                  [13:39:33.963] Info: Armed by RC
                                  [13:39:34.096] Info: logging: opening log file sess114/log100.ulg
                                  [13:39:34.296] Critical: Failsafe activated, triggering disarm
                                  ESC failure
                                  [13:39:34.296] Info: Disarmed by failsafe
                                  [13:39:36.780] Info: Armed by RC
                                  [13:39:36.781] Info: logging: opening log file sess114/log101.ulg
                                  [13:39:37.131] Critical: Failsafe activated, triggering disarm
                                  [13:39:37.131] Info: Disarmed by failsafe
                                  [13:39:39.424] Info: Armed by RC
                                  [13:39:39.465] Info: logging: opening log file sess114/log102.ulg
                                  [13:39:39.787] Critical: Failsafe activated, triggering disarm
                                  [13:39:39.787] Info: Disarmed by failsafe

                                  And the motors try to spin up for a few seconds when arming and then instantly stop

                                  When I move this sliders now the motors rotate but when I try to arm the drone using RC it shows the ESC failure error

                                  a646b685-77d0-4ba3-8d65-72af8e7870ae-image.png

                                  tomT Offline
                                  tomT Offline
                                  tom
                                  admin
                                  wrote on last edited by
                                  #18

                                  @Darshit-Desai If you upload the px4 log someone on our team can analyze it

                                  Darshit DesaiD 1 Reply Last reply
                                  0
                                  • tomT tom

                                    @Darshit-Desai If you upload the px4 log someone on our team can analyze it

                                    Darshit DesaiD Offline
                                    Darshit DesaiD Offline
                                    Darshit Desai
                                    Regular
                                    wrote on last edited by Darshit Desai
                                    #19

                                    @tom By px4 log you mean the one mentioned in the post earlier, How can I access the log file which is mentioned here in the QGC log?

                                    @Darshit-Desai said in m500 VOXL Flight sdk update to v1.1.x:

                                    [13:38:12.651] Info: Kill-switch engaged
                                    [13:38:13.768] Info: Kill-switch disengaged
                                    [13:39:33.963] Info: Armed by RC
                                    [13:39:34.096] Info: logging: opening log file sess114/log100.ulg
                                    [13:39:34.296] Critical: Failsafe activated, triggering disarm
                                    ESC failure
                                    [13:39:34.296] Info: Disarmed by failsafe
                                    [13:39:36.780] Info: Armed by RC
                                    [13:39:36.781] Info: logging: opening log file sess114/log101.ulg
                                    [13:39:37.131] Critical: Failsafe activated, triggering disarm
                                    [13:39:37.131] Info: Disarmed by failsafe
                                    [13:39:39.424] Info: Armed by RC
                                    [13:39:39.465] Info: logging: opening log file sess114/log102.ulg
                                    [13:39:39.787] Critical: Failsafe activated, triggering disarm
                                    [13:39:39.787] Info: Disarmed by failsafe

                                    tomT 1 Reply Last reply
                                    0
                                    • Darshit DesaiD Darshit Desai

                                      @tom By px4 log you mean the one mentioned in the post earlier, How can I access the log file which is mentioned here in the QGC log?

                                      @Darshit-Desai said in m500 VOXL Flight sdk update to v1.1.x:

                                      [13:38:12.651] Info: Kill-switch engaged
                                      [13:38:13.768] Info: Kill-switch disengaged
                                      [13:39:33.963] Info: Armed by RC
                                      [13:39:34.096] Info: logging: opening log file sess114/log100.ulg
                                      [13:39:34.296] Critical: Failsafe activated, triggering disarm
                                      ESC failure
                                      [13:39:34.296] Info: Disarmed by failsafe
                                      [13:39:36.780] Info: Armed by RC
                                      [13:39:36.781] Info: logging: opening log file sess114/log101.ulg
                                      [13:39:37.131] Critical: Failsafe activated, triggering disarm
                                      [13:39:37.131] Info: Disarmed by failsafe
                                      [13:39:39.424] Info: Armed by RC
                                      [13:39:39.465] Info: logging: opening log file sess114/log102.ulg
                                      [13:39:39.787] Critical: Failsafe activated, triggering disarm
                                      [13:39:39.787] Info: Disarmed by failsafe

                                      tomT Offline
                                      tomT Offline
                                      tom
                                      admin
                                      wrote on last edited by
                                      #20

                                      @Darshit-Desai The logs can be downloaded through QGroundControl: https://docs.px4.io/v1.11/en/getting_started/flight_reporting.html#downloading-logs-from-the-flight-controller

                                      Darshit DesaiD 1 Reply Last reply
                                      0
                                      • tomT tom

                                        @Darshit-Desai The logs can be downloaded through QGroundControl: https://docs.px4.io/v1.11/en/getting_started/flight_reporting.html#downloading-logs-from-the-flight-controller

                                        Darshit DesaiD Offline
                                        Darshit DesaiD Offline
                                        Darshit Desai
                                        Regular
                                        wrote on last edited by
                                        #21

                                        @tom Here's the ulog file link,

                                        https://drive.google.com/file/d/1vuy_Ut0h_rEZDWseDgeywE093CISo9RB/view?usp=sharing

                                        C Darshit DesaiD 2 Replies Last reply
                                        0
                                        • Darshit DesaiD Darshit Desai

                                          @tom Here's the ulog file link,

                                          https://drive.google.com/file/d/1vuy_Ut0h_rEZDWseDgeywE093CISo9RB/view?usp=sharing

                                          C Offline
                                          C Offline
                                          coreyazion
                                          Contributor
                                          wrote on last edited by
                                          #22

                                          @Darshit-Desai Our m500 also showed something needed to be done with the acutator after updgrade to 1.14. But after loading the parameters (assuming you are using fcv2) and then reboot and it is okay.

                                          p.s. I vaguely rember having to do "loading parameters and rebooting" twice to get everything done. But I'm not very sure about this just I have this impression.

                                          Darshit DesaiD 1 Reply Last reply
                                          0

                                          Reading along? Create a free ModalAI Forum account to join in.

                                          With an account you can reply, ask your own question, get an email when a ModalAI engineer answers, and mark the reply that solved it. Your place in each thread is saved between visits.

                                          Questions about VOXL, Flight Core, ESCs and ModalAI drones are answered here by the engineers who build them.

                                          Register Login
                                          Reply
                                          • Reply as topic
                                          Log in to reply
                                          • Oldest to Newest
                                          • Newest to Oldest
                                          • Most Votes


                                          ModalAI
                                          Categories Recent Tags ModalAI.com Docs
                                          © 2026 ModalAI® · Accelerating autonomy for smaller, smarter, safer drones · Powered by NodeBB
                                          • Login

                                          • Don't have an account? Register

                                          • Login or register to search.
                                          • First post
                                            Last post
                                          0
                                          • Categories
                                          • Recent
                                          • Tags
                                          • Popular
                                          • Users
                                          • Groups