
IMU Noise Expectations
-
Hi there, I'm curious about what sort of noise we should expect on the IMUs on the Starling?
Here is the sort of noise I am seeing on my platform:
-
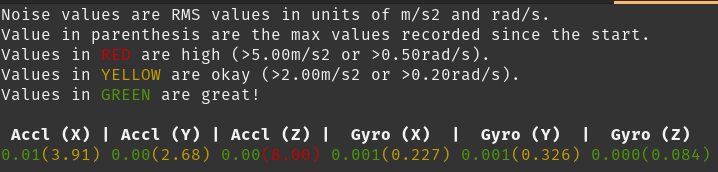
Result of
voxl-inspect-vibration imu_appsduring a flight:
-
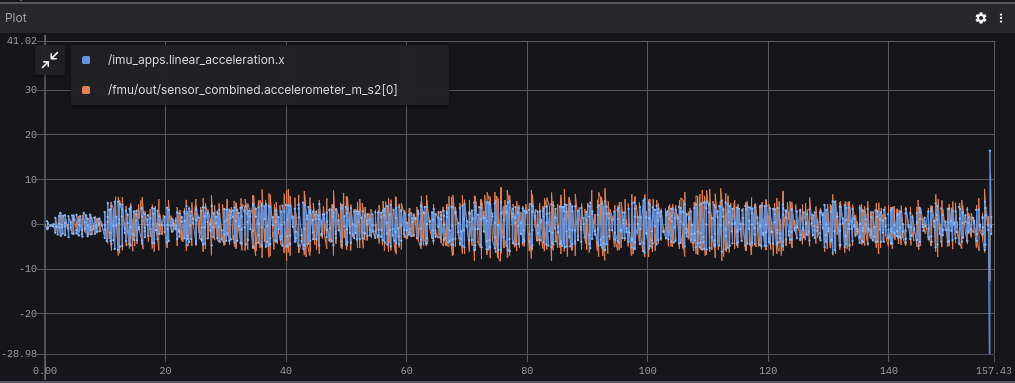
Result of plotting
imu_appsas well asimu_px4. Both have similar levels of noise.
-
-
@Moderator - any guidance here? Wondering if my unit is perhaps defective.
@awoods ,
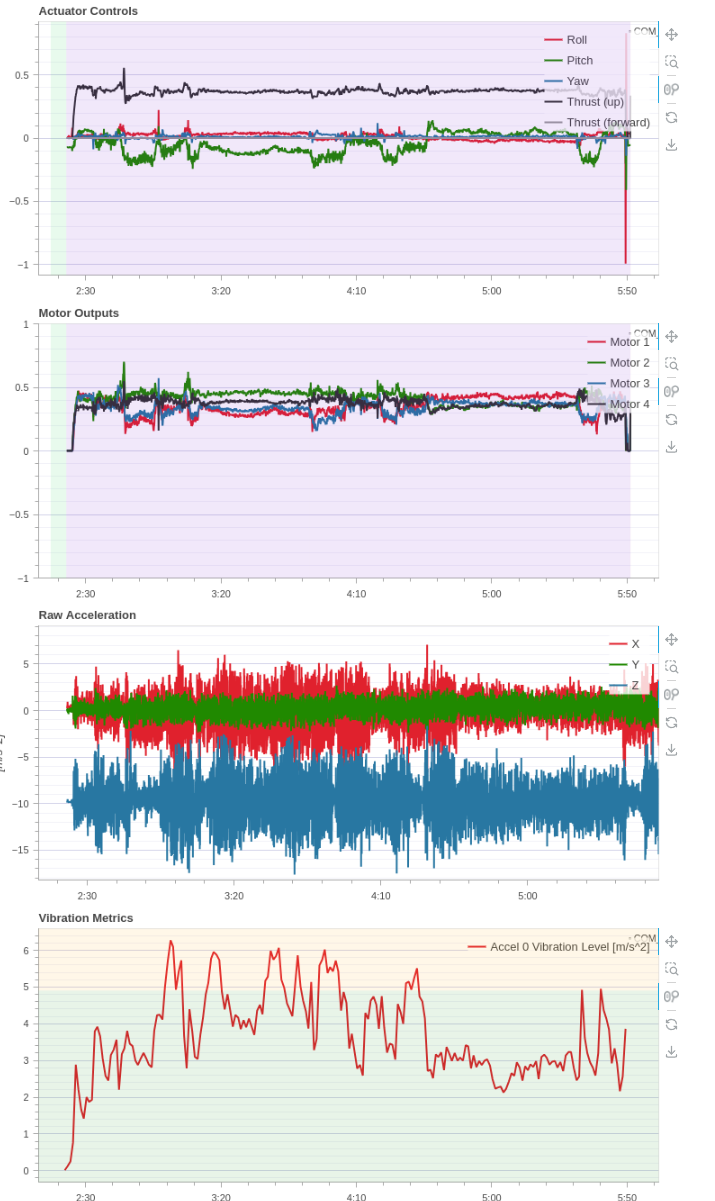
Here is a sample log from one of our recent tests using a Starling platform.
You can review the PX4 log here : https://review.px4.io/plot_app?log=3a4c53fd-db88-4d54-8f2e-5f22e159bfc6
The accelerometer noise looks comparable to yours, perhaps a bit less. The main thing is that motor outputs are pretty clean, very minor oscillations. You can collect a similar log and compare using px4 flight review. Also look at gyro noise which more directly affects motor commands.

Reading along? Create a free ModalAI Forum account to join in.
With an account you can reply, ask your own question, get an email when a ModalAI engineer answers, and mark the reply that solved it. Your place in each thread is saved between visits.
Questions about VOXL, Flight Core, ESCs and ModalAI drones are answered here by the engineers who build them.
Register Login