Skip to content

Development Drones

645 Topics 3.3k Posts

Starling 2, Starling 2 Max, Sentinel, Seeker, m500, RB5, the PX4 Autonomy Developer Kit and Stinger FPV: flying, tuning, repairs and spare parts.

  • Starling 2 Max for indoor use in Japan: radio options, prop guards and payload mounting

    Unsolved
    5
    0 Votes
    5 Posts
    147 Views
    tomT
    On the Wi-Fi questions: The -M36 option ships with an Alfa Network AWUS036EACS (802.11ac AC600, dual band 2.4/5 GHz, Realtek chipset, made in Taiwan). It is listed on the Starling 2 Max datasheet. Yes, you can use a different USB adapter, as long as the VOXL 2 kernel has a driver for its chipset. You cannot install arbitrary vendor drivers without rebuilding kernel modules, so pick an adapter based on one of the Realtek chipsets we support: RTL8812AU or RTL8821CU / RTL8811CU. The adapters we have tested are listed on the VOXL 2 WiFi Setup page. If you find a Japan-certified (Giteki) adapter with one of those chipsets, it should work with voxl-wifi in both Station and SoftAP mode. If you cannot find a certified adapter with a supported chipset, another option is a USB-to-Ethernet adapter on VOXL 2 connected to a small Japan-certified Wi-Fi bridge or travel router on the drone. VOXL 2 only sees Ethernet, so there are no driver constraints. In SoftAP mode the default hostapd country code is US. For use in Japan, set country_code=JP in /data/misc/wifi/hostapd.conf after running voxl-wifi so the radio uses Japanese channel and power rules.
  • Starling 2 Max - Power issues when starting process

    Unsolved
    7
    3
    0 Votes
    7 Posts
    431 Views
    Eric KatzfeyE
    There's some documentation here: https://docs.px4.io/main/en/flight_modes/offboard#ros-2-offboard-control. I would review that to make sure you are following the correct procedures.
  • Need info ASAP on Starling 2 Max (NDAA-compliant vs Blue UAS).

    Unsolved
    1
    0 Votes
    1 Posts
    91 Views
    No one has replied
  • VOXL2 randomly reboots during flight – PMIC reports S3_RESET_PBS_WATCHDOG_TO

    Solved
    4
    0 Votes
    4 Posts
    368 Views
    J
    Title: Starling 2 Max – Flight Performance at 2,800–3,000 m Above Sea Level Hello ModalAI Engineering Team, We are evaluating the Starling 2 Max for research flights inside rose greenhouses in Tabacundo, Ecuador, at approximately 2,800–3,000 meters above sea level. Before purchasing the aircraft, we need to assess whether this operating environment falls within its safe flight-performance limits. Could you please clarify: What is the maximum recommended operating altitude above mean sea level for the Starling 2 Max? Has flight performance been tested or characterized at approximately 3,000 meters above sea level? What reduction in thrust margin or flight endurance should we expect at this altitude? Are there recommended limits for payload, battery configuration, ambient temperature, or mission duration under these conditions? Does ModalAI provide performance curves or engineering data that could help us evaluate this operating scenario? Are there any special safety precautions or configuration changes recommended for high-altitude operation? Our primary concern is maintaining adequate thrust margin and safe, repeatable flight performance inside a confined greenhouse environment. We would appreciate any relevant documentation or test data. Thank you. FloraVision AI Engineering Team Ecuador
  • Boson 640 + Sterling 2 Max

    Unsolved
    1
    0 Votes
    1 Posts
    40 Views
    No one has replied
  • installing Ethernet Expansion and USB Hub on starling 2 max without ToF

    Unsolved
    1
    0 Votes
    1 Posts
    306 Views
    No one has replied
  • Starling 2 intermittently rebooting / VOXL losing power and ESC LEDs stopping

    Unsolved
    3
    1 Votes
    3 Posts
    303 Views
    VinnyV
    Hi @marcos-correa Apologies for the delays here, I was out on leave for a couple weeks. It sounds like the M0141 issue you might be having is very similar to this one: https://forum.modalai.com/topic/1356/sentinel-drone-randomly-reboots/2?_=1790714717250 It's important to use 5mm spacers between any VOXL 2 plug-in board, especially if it only picks up J3 and not J5, since that leave all the pins on J5 vulnerable to contacting circuitry from whatever plug-in board is installed. Symptoms from that contact are most certainly proven to be resets and brown outs, as we have seen that before. If you are already using spacers between your board, then I'd need to think about other potential root causes. Hope this helps. Thanks! Vinny
  • Starling 2 Motor EOL (M10000633) replacement & Battery specs for EU sourcing

    Unsolved
    4
    0 Votes
    4 Posts
    326 Views
    ModeratorM
    It looks like we have one M10000633 on hand. Reach out to https://modalai.com/contact and see if they can get it to you
  • Purchasing Starling 2

    Unsolved starling
    2
    0 Votes
    2 Posts
    303 Views
    PQLP
    Michael, They take approximately 60 days to deliver once you put in a order.
  • Starling 2 Max runs hot

    Unsolved
    1
    0 Votes
    1 Posts
    106 Views
    No one has replied
  • SDK 1.6.4 on a Stinger X8: lepton0_encoded never publishes H265 frames

    Unsolved
    1
    0 Votes
    1 Posts
    112 Views
    No one has replied
  • Camera Calibration – Starling 2 Max

    Solved
    5
    0 Votes
    5 Posts
    374 Views
    V
    @tom thank you
  • plz

    Unsolved
    2
    0 Votes
    2 Posts
    207 Views
    Eric KatzfeyE
    Most of this can be answered by our documentation here: https://docs.modalai.com/. If after reading through that you still have any specific questions feel free to reach out here on the forum. The short answer to most of your questions is "yes".
  • Possible camera orientations for Starling 2 Max dev drone

    Unsolved
    3
    0 Votes
    3 Posts
    369 Views
    Dylan GreshamD
    Hi @tom, That's exactly what I was looking for, thank you!
  • 0 Votes
    3 Posts
    412 Views
    tomT
    Hi @alraj, 05c6:900e QUSB_BULK is not EDL (that is 9008). It is the SoC crash-dump mode, so the board is attempting to boot and failing before the OS comes up. Since Sahara/Firehose completed with the correct M0054-2 image, the flash contents are unlikely to be the problem. In past cases a board that returns to 900e after a successful QDL has not been recoverable by reflashing (https://forum.modalai.com/topic/1468 and https://forum.modalai.com/topic/3263), and a similar Sentinel case came back from RMA as a damaged main board (https://forum.modalai.com/topic/2131). Two things worth ruling out first. Pull the VOXL 2 out of the drone and boot it bare with every camera and add-on disconnected, since a mis-seated camera connector produced this same 900e state once (https://forum.modalai.com/topic/3230). Then re-check the steps at https://docs.modalai.com/voxl2-unbricking/#if-the-device-still-shows-900e-or-boot-loops-after-a-successful-flash and repeat the flash once. If it still comes back as 900e, an RMA is the next step: https://www.modalai.com/pages/rma. Include the serial number and QDL log. Keep the crash dump private, support can request it if needed.
  • Re-configure VOXL2 1.4 for GHOST Receiver/Transmitter?

    Solved sentinel
    14
    0 Votes
    14 Posts
    1k Views
    Maxwell SchaeferM
    The ExpressLRS receiver requires* one additional wire. The ghost atto only connects one wire to the VOXL RC RX pin, but the ELRS receiver will also require a connection to the VOXL RC TX pin, otherwise the wiring is identical. Pre-crimped wires can be found easily for the JST GH connectors (J19) to make adding connections simple. *You could leave the receiver's RX line (the VOXL's RC TX) disconnected; this would make updates and other control using the voxl-elrs application impossible but basic RC functionality would work.
  • Camera Intrinsics, VIO and more..

    Unsolved starling
    7
    0 Votes
    7 Posts
    2k Views
    Dinesh Varun KandiyappanD
    @alex-kushleyev Thanks for the response! A control model is a simple MLP (multi-layer perceptron) Input observation space: PX4 odometry topics, ToF depth/Depth estimation model, object detections. Output action space: PX4 offboard commands ( position and yaw for now, but we might extend to velocity/Collective thrust and body rates)
  • Does Startling 2 Max have ASDA and FAR 52.240-1 compliance

    Unsolved starling
    1
    0 Votes
    1 Posts
    128 Views
    No one has replied
  • Battery Data Collection

    Unsolved stinger
    4
    0 Votes
    4 Posts
    319 Views
    Vipul BansalV
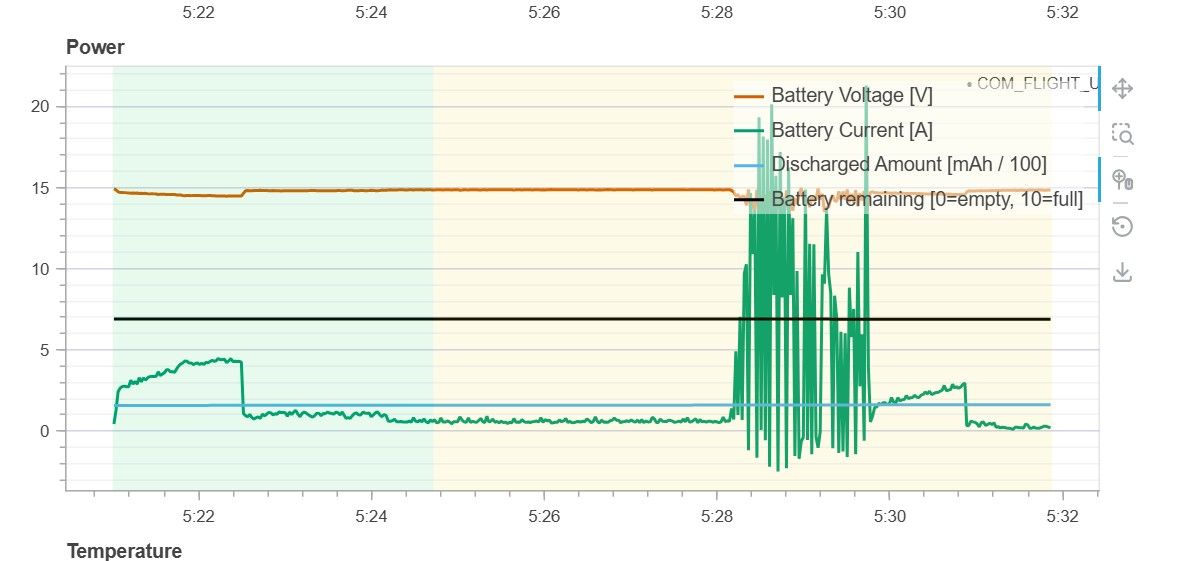
    I want to develop a battery management system to read live battery data and use it into a software that plans launch, path, return and control of the drone
  • QDL - 'received non-successful result'

    Unsolved sentinel
    2
    0 Votes
    2 Posts
    637 Views
    P
    RMA'd the VOXL2 board, it was found to be unrepairable.