Skip to content

Development Drones

642 Topics 3.3k Posts

Starling 2, Starling 2 Max, Sentinel, Seeker, m500, RB5, the PX4 Autonomy Developer Kit and Stinger FPV: flying, tuning, repairs and spare parts.

  • Seeker User Manual

    Solved seeker
    2
    0 Votes
    2 Posts
    256 Views
    tomT
    Please reach out here: https://www.modalai.com/pages/blue-uas-cleared-fpv-customer-intake-form
  • Starling 2 Purchase

    Unsolved
    1
    0 Votes
    1 Posts
    138 Views
    No one has replied
  • Sentinel Receiver/Transmitter Retrofit

    Unsolved sentinel
    2
    0 Votes
    2 Posts
    751 Views
    J
    Wanted to check in again. Any advice on swapping spektrum RC for ghost atto on voxl2?
  • Starling 2 components

    Unsolved starling
    2
    0 Votes
    2 Posts
    1k Views
    A
    Hi, I would like to know what wifi module is on the drone. The one mounted on the drone is different than AlfaNetworks? Adam
  • Unable to execute autonomous waypoint mission using QGroundControl

    Unsolved
    1
    0 Votes
    1 Posts
    762 Views
    No one has replied
  • Recording

    Unsolved fpv
    2
    0 Votes
    2 Posts
    1k Views
    ModeratorM
    Hi Christopher We currently support two forms of recording, both at the pilot internal to the VRX onboard storage on goggles to the SD Card We do have on our list to implement recording at the UAS itself, but that will need to be in a future software update.
  • Stinger FPV Cam Assembly Model/Shop Ambiguity

    Unsolved stinger
    2
    0 Votes
    2 Posts
    1k Views
    A
    Similarly, I cannot find the model for the new "slim" VTX mount, only the older, taller one.
  • Parts needed to add M0178 ToF sensor to Starling 2 Max - C28 configuration

    Unsolved starling
    3
    0 Votes
    3 Posts
    1k Views
    Adrian HidalgoA
    Hello Timothy, Excellent! That is certainly possible to do. Yes, with some configuration it can be compatible. You will need to reconfigure MPA from the C28 camera config to the C29 camera config. They will need a new front camera bezel(M10001278), TOF safety shield(M10000537) and everything in MSU-M0178-1-01. Most of the hardware can be reused but as a precaution would also recommend QTY. 4 M10000884(M1.6X6 Screws) & QTY. 4 M10000882(M2.2X10 Screws). If you would like to proceed with the purchase, please email contact@modalai.com with the contents above. Regards.
  • Drone Issues

    Unsolved stinger
    2
    0 Votes
    2 Posts
    1k Views
    Eric KatzfeyE
    @ralinaresg What SDK version is loaded on the Stinger?
  • Starling 2 Max C28 vs C29

    Unsolved starling
    9
    0 Votes
    9 Posts
    2k Views
    Timothy ZinwotaT
    @Alex-Kushleyev said in Starling 2 Max C28 vs C29: @jbiscan21 , yes you can add the TOF sensor to Starling 2 Max, but you will also need a new front plastic mount that will hold the hires and tracking cameras as well as the new TOF sensor. You can order the mount (which will be a drop in replacement for the original camera mount) with the TOF sensor. If you do want to proceed with the TOF sensor + plastics order, we will need to double check that all the necessary screws are included. You would need to send an email for a custom order to start this off and mention this thread and that we need to include mounting hardware. https://www.modalai.com/pages/contact-us (related post : https://forum.modalai.com/topic/5157/c29-configuration) See more detailed pictures. [image: 1778622521915-06f55cf3-051e-4cf8-8029-dc558eddf484-image.png] [image: 1778622565955-d6b9c715-eb34-4012-8785-f8c317d4e743-image.png] [image: 1778622615250-74789adc-815b-4c67-9663-aae23dc96106-image.png] Alex @Alex-Kushleyev We are trying to purchase the TOF sensor for our Starling 2 max c28 configuration. The sales department asked to make a post on the forum for technical information which I did here Can you confirm if we can also reference this post to make the purchase for our drone with the required parts included? We'd like to place an order as soon as possible. Thank you, Timothy Zinwota University of Nevada, Las Vegas.
  • Starling 2 replacement piece

    Unsolved starling
    2
    2
    0 Votes
    2 Posts
    2k Views
    Alex KushleyevA
    @ey , we are working on making a replacement plastic kit available. It looks like you may have gotten a response from our team already, but moving forward we should have some kits available soon. Alex
  • Modal starling2 downward camera

    Unsolved starling
    2
    0 Votes
    2 Posts
    2k Views
    Alex KushleyevA
    @Arunabh-Sharma , I believe the extrinsics file is correct. Here is an extrinsics file for Starling 2 (which can support up to 3 tracking cameras, depending on configuration). https://gitlab.com/voxl-public/voxl-sdk/utilities/voxl-mpa-tools/-/blob/master/misc_files/usr/share/modalai/extrinsic_configs/D0014_Starling_2.conf tracking_down is the camera we want and the extrinsics are: "parent": "imu_apps", "child": "tracking_down", "T_child_wrt_parent": [-0.08825, -0.0045, 0.0269], "RPY_parent_to_child": [0, 0, 180] [image: 1782188708958-54bec293-dddc-48e7-903b-47dda8c48787-image.png] I have labeled the camera X and Y axes on the down-facing rear camera and the rotation matches up with 180 degree yaw with respect to the drone's body axes (X=forward, Y=right, Z= down) Please note something that may add to the confusion. The front facing tracking camera is technically upside down (using our standard convention that i labeled for the down-facing camera), however we rotate the image 180 degrees in the camera itself during image read-out, so that the image looks right side up without any software work. This 180 degree rotation is selected in voxl-camera-server.conf with a rotation parameter, which instructs voxl-camera-server to set a special register in the camera to reverse the image readout. This is why you will see tracking_front and hires cameras having the same rotation extrinsics, while the tracking_front camera is physically upside down. Some more info about our extrinsics and conventions : https://docs.modalai.com/configure-extrinsics/ Alex
  • Burnt board components

    Unsolved fpv
    4
    1
    0 Votes
    4 Posts
    3k Views
    R
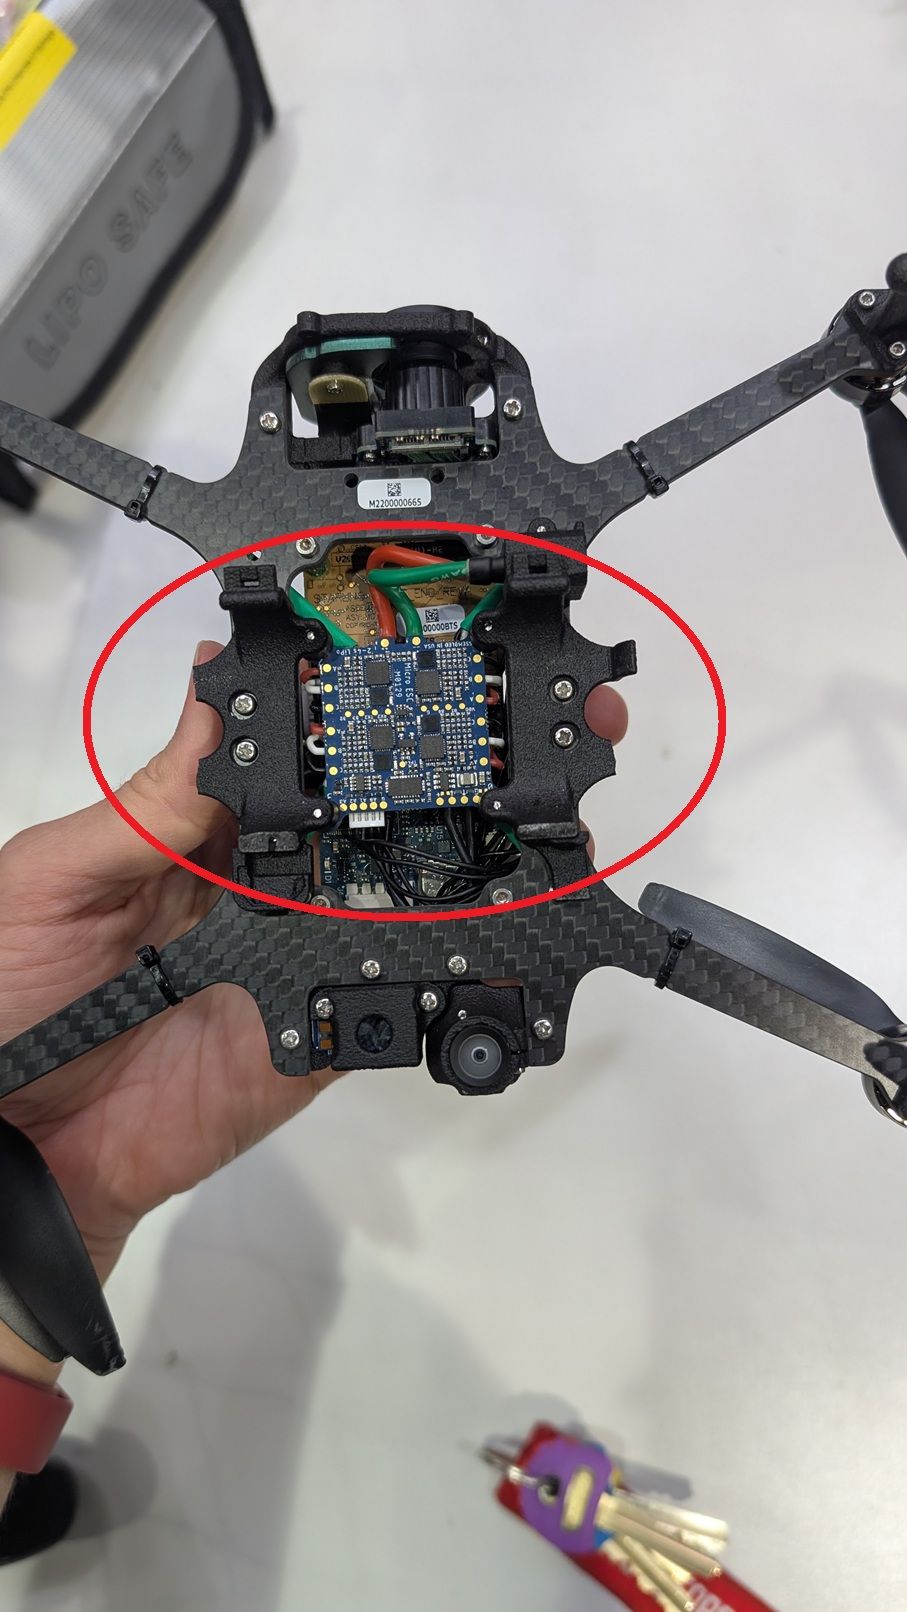
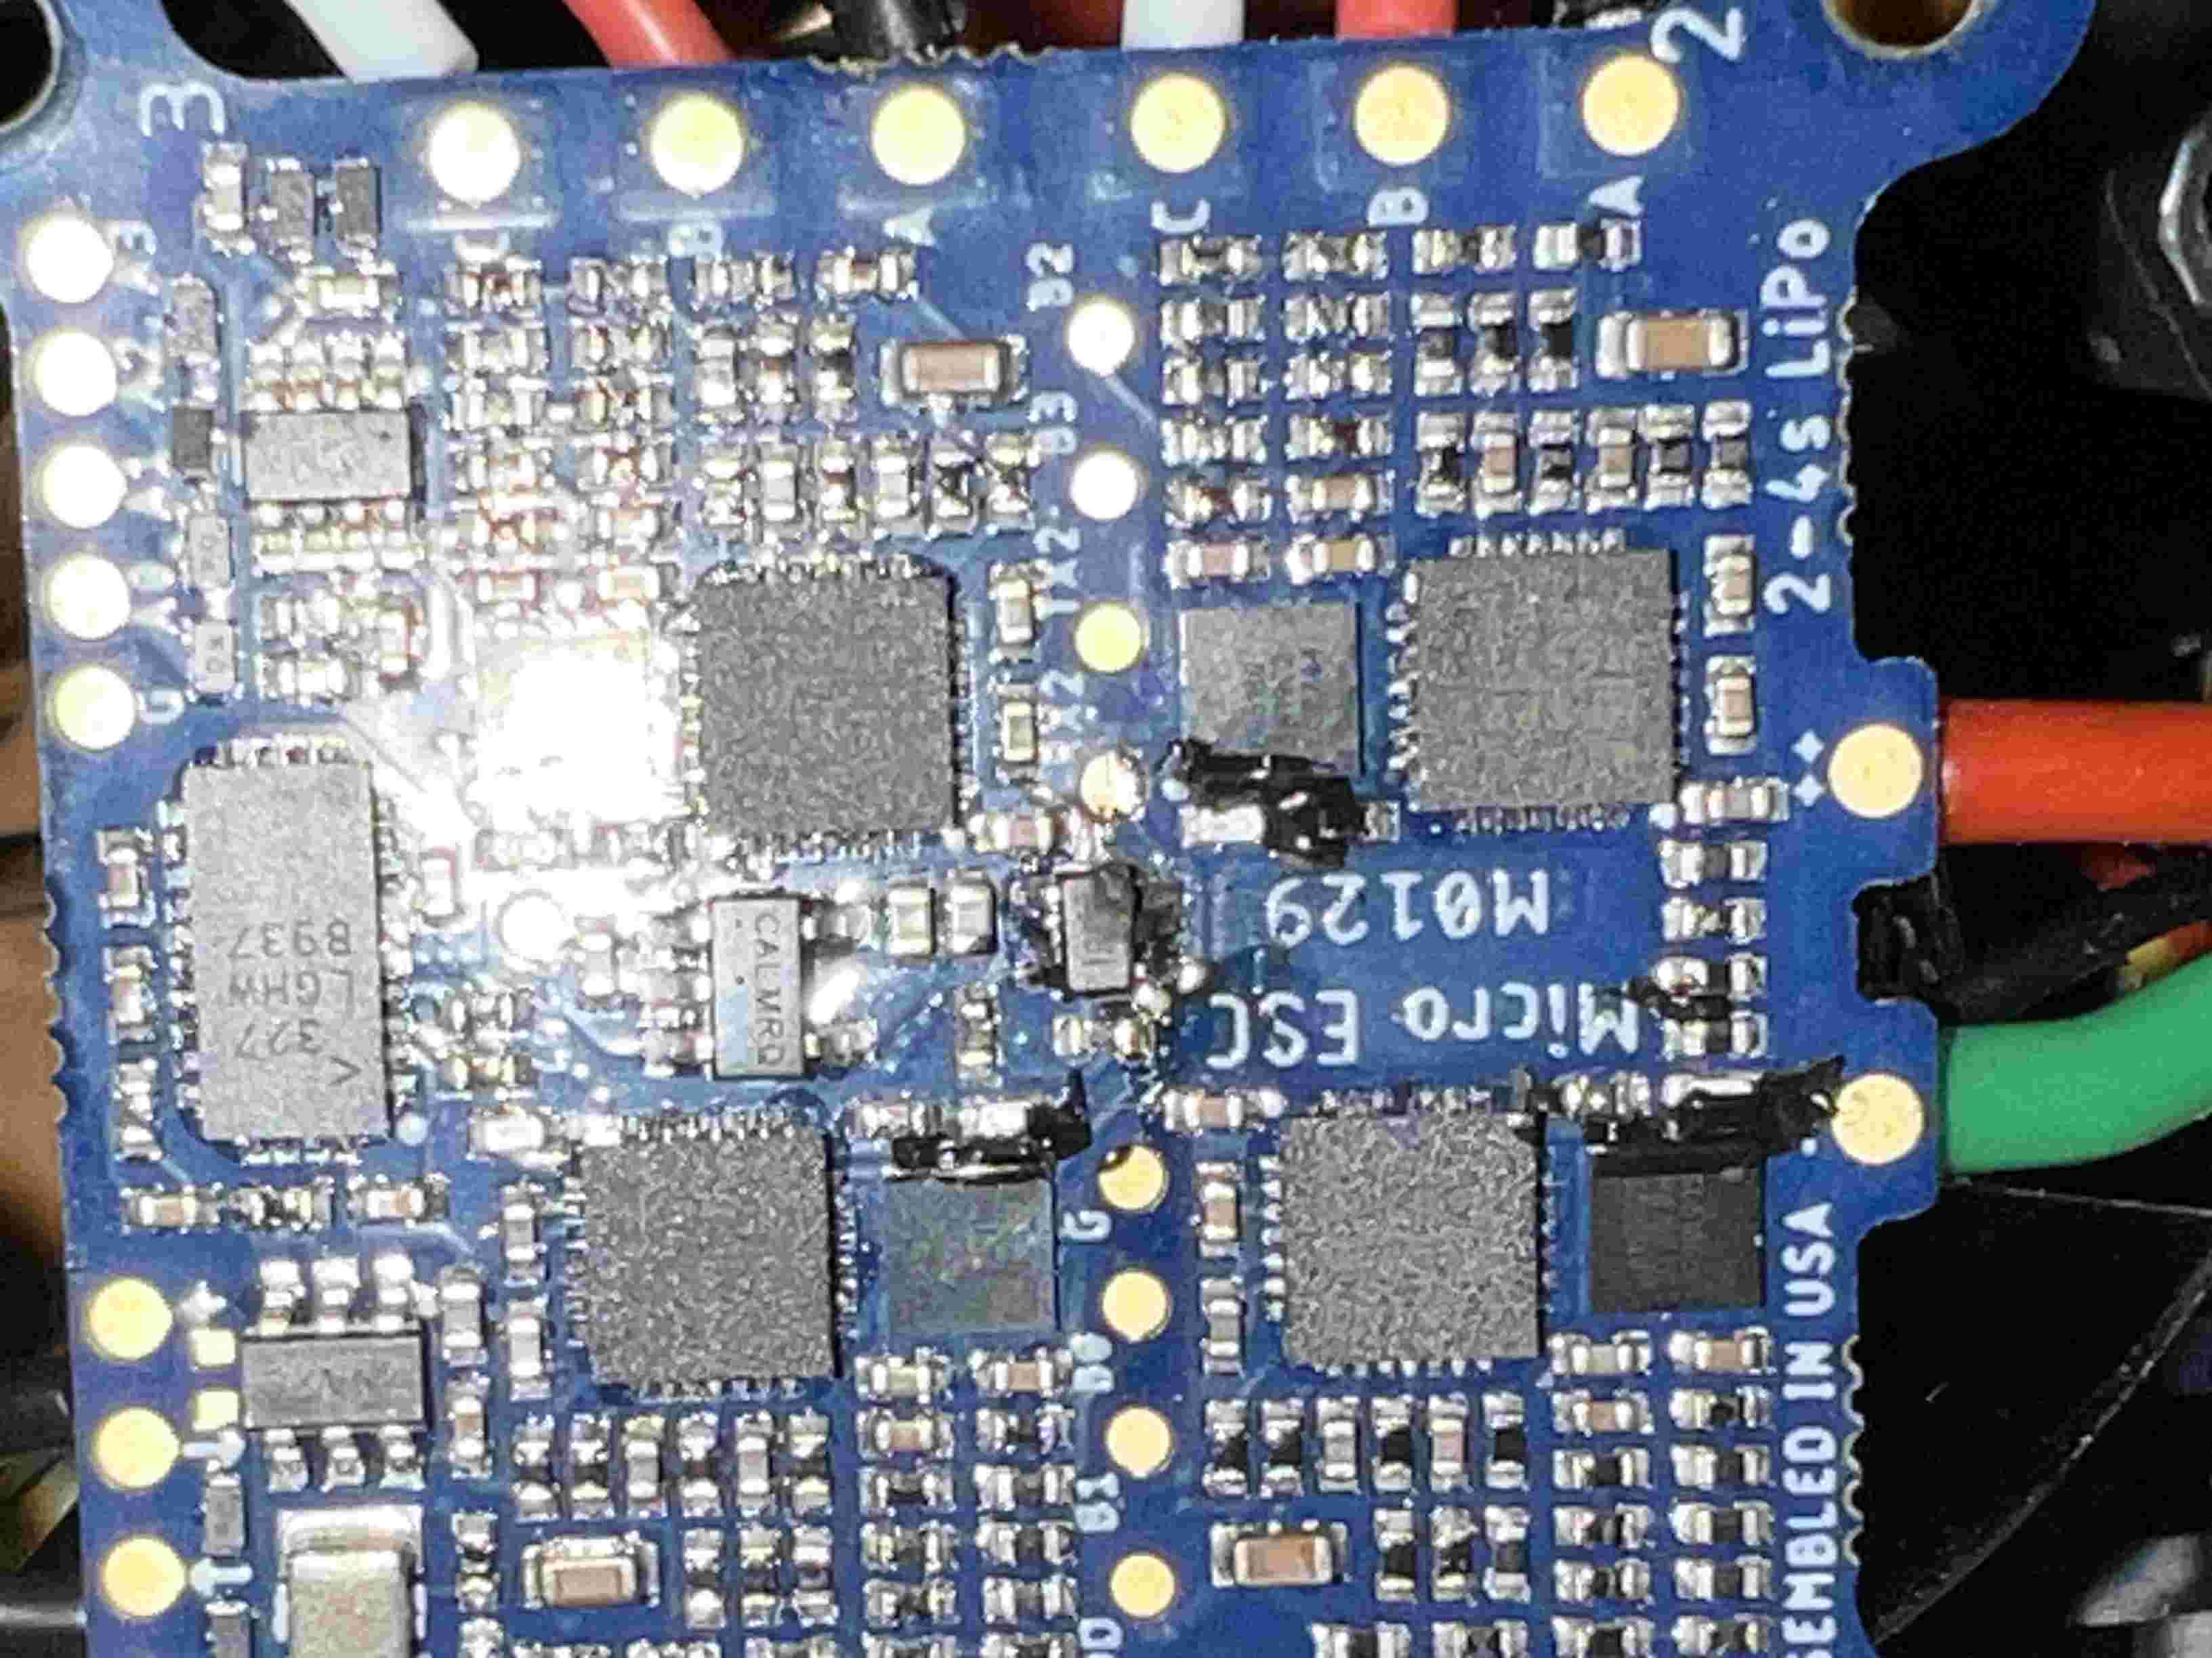
    @Alex-Kushleyev Thank you. We will do, but for future reference: @Alex-Kushleyev said in Burnt board components: what type of vehicle was the ESC a part of? Singer Vision FPV 3.5" @Alex-Kushleyev said in Burnt board components: what was the behavior of the motor that was not functioning properly? Not operating a full power with intermittent operation @Alex-Kushleyev said in Burnt board components: did the whole ESC stop working or only one channel, which was originally struggling? Only one channel @Alex-Kushleyev said in Burnt board components: did you notice the burned component when the ESC arrived or did it burn after arrival? We didn't noticed or inspected it. @Alex-Kushleyev said in Burnt board components: was the black paint already on the ESC when you received it? We didn't notice or checked
  • VIO position estimation is off

    Unsolved
    1
    0 Votes
    1 Posts
    873 Views
    No one has replied
  • Issues with controller and drone

    Unsolved starling
    22
    0 Votes
    22 Posts
    3k Views
    Eric KatzfeyE
    @daniellee This log shows a normal flight happening in altitude hold mode. RC inputs are coming in and motors are spinning. Was there some issue with the flight this log was captured from?
  • Skip threadlocker

    Unsolved stinger
    1
    0 Votes
    1 Posts
    539 Views
    No one has replied
  • Inquiry: Starling 2 Max — ROS2 / Jetson Orin Nano & RFID integration

    Unsolved fpv
    10
    0 Votes
    10 Posts
    4k Views
    Eric KatzfeyE
    @Mustafa_Cayci You can get the Starling 2 Max with a ToF sensor for depth mapping indoors (The sensors don't really work outdoors). https://www.modalai.com/products/starling-2-max?variant=49129974923568
  • Spektrum RC Bind Issues after SDK Update

    Unsolved sentinel
    3
    0 Votes
    3 Posts
    2k Views
    J
    So I'm guessing this has to do with the following I noticed in the changelog: 1.7.4 (voxl2_SDK_1.1.3) BSP: add voxl-fysnc-mod kernel module add voxl-gpio-mod kernel module --- GPIO now exporting to /sys/class/gpio convert SE13 from 4W to 2W UART, freeing GPIO36/37 add voxl-platform-mod kernel module --- see /sys/module/voxl_platform_mod/parameters add new target 'M0054-2' support (same rootfs as M0054-1) new kernel new devcfg.mbn In system image 1.7.1 (SDK v1.1.2) on the drone that has no rc issues, recipes-kernel/linux-msm/files/dts/common/m0xxx-modalai-gpio.dtsi has: &soc { b2b_conn_gpio_init { compatible = "modalai,voxl-b2b"; pinctrl-names = "default"; pinctrl-0 = <&tck22912G_ctrl_pin &b2b_pin7 &b2b_pin9 &b2b_pin17 &b2b_pin19 &b2b_pin38 &b2b_pin40 &hs_b2b_pin41 &hs_b2b_pin42 &hs_b2b_pin43 &hs_b2b_pin44 &hs_b2b_pin46 &hs_b2b_pin47 &hs_b2b_pin50 &hs_b2b_pin51 &hs_b2b_pin78 &hs_b2b_pin79 &hs_b2b_pin80 &hs_b2b_pin81 &hs_b2b_pin82 &j10_lvl_shf_ctrl_pin>; status = "ok"; }; rc_in_enable_init { compatible = "modalai,voxl-rc-in"; pinctrl-names = "default"; pinctrl-0 = <&rc_in_3v3_en_pin>; status = "ok"; }; }; In image 1.7.4 (SDK 1.1.3), recipes-kernel/linux-msm/files/dts/common/m0xxx-modalai-gpio.dtsi: &soc { voxl_gpio { compatible = "modalai,voxl-gpio"; pinctrl-names = "default"; pinctrl-0 = <&tck22912G_ctrl_pin &b2b_pin7 &b2b_pin9 &b2b_pin17 &b2b_pin19 &b2b_pin38 &b2b_pin40 &hs_b2b_pin41 &hs_b2b_pin42 &hs_b2b_pin43 &hs_b2b_pin44 &hs_b2b_pin46 &hs_b2b_pin47 &hs_b2b_pin50 &hs_b2b_pin51 &hs_b2b_pin78 &hs_b2b_pin79 &hs_b2b_pin80 &hs_b2b_pin81 &hs_b2b_pin82 &hs_b2b_pin95 &hs_b2b_pin96 &j10_lvl_shf_ctrl_pin &rc_in_3v3_en_pin &ds2_led_red &ds2_led_green &ds2_led_blue &id_som_1 &id_som_2 &id_mai_3 &id_mai_4>; modalai,gpio-init-output-high = <0 1 53 56 57 85 86 87 88 89 124 152 157 159>; modalai,gpio-init-output-low = <36 37 46 54 55 67 82 83 84 131 153 154 155>; modalai,gpio-init-input = <48 49 50 51 52>; status = "ok"; }; voxl_fsync { compatible = "modalai,voxl-fsync"; pinctrl-names = "default"; pinctrl-0 = <&camera_sync_110 &camera_sync_111 &camera_sync_112 &camera_sync_113 &camera_sync_114>; status = "ok"; }; }; And then in image 1.8.06 (SDK v1.6.3) that is on the drone with the bind issues, recipes-kernel/linux-msm/files/dts/common/m0xxx-modalai-gpio.dtsi: &soc { voxl_gpio { compatible = "modalai,voxl-gpio"; pinctrl-names = "default"; pinctrl-0 = <&tck22912G_ctrl_pin &b2b_pin7 &b2b_pin9 &b2b_pin17 &b2b_pin19 &b2b_pin38 &b2b_pin40 &hs_b2b_pin41 &hs_b2b_pin42 &hs_b2b_pin43 &hs_b2b_pin44 &hs_b2b_pin46 &hs_b2b_pin47 &hs_b2b_pin50 &hs_b2b_pin51 &hs_b2b_pin78 &hs_b2b_pin79 &hs_b2b_pin80 &hs_b2b_pin81 &hs_b2b_pin82 &hs_b2b_pin95 &hs_b2b_pin96 &j10_lvl_shf_ctrl_pin &rc_in_3v3_en_pin &ds2_led_red &ds2_led_green &ds2_led_blue &id_som_1 &id_som_2 &id_mai_3 &id_mai_4 &camera_sync_110 &camera_sync_111 &camera_sync_112 &camera_sync_113 &camera_sync_114>; modalai,gpio-init-output-high = <0 1 53 56 57 67 85 86 87 88 89 124 152 157 159>; modalai,gpio-init-output-low = <36 37 54 55 82 83 84 131 153 154 155>; modalai,gpio-init-input = <48 49 50 51 52 110 111 112 113 114>; status = "ok"; }; voxl_fsync { compatible = "modalai,voxl-fsync"; pinctrl-names = "default"; status = "ok"; }; }; So the gpio initialization process changed and rc_in_enable_init was removed between SDK v1.1.2 and v1.1.3, and between SDK v1.1.3 and v1.6.3, GPIO pin 67 got moved from modalai,gpio-init-output-low to modalai,gpio-init-output-high and GPIO pin 46 got removed from modalai,gpio-init-output-low. https://gitlab.com/voxl-public/system-image-build/meta-voxl2-bsp/-/commit/538c324713548174c8c1694680e9cba7f2d47bcb https://gitlab.com/voxl-public/system-image-build/meta-voxl2-bsp/-/commit/ccd3893e062b03d05885da5a279be2f8d2f6c97c Idk which change is responsible for the binding issues. I'd like to avoid flashing v1.1.3 to narrow it down. Can someone explain how the pins are meant to function for my set-up (M0094 + M0054, rc already bound)?
  • GNSS EMI Mitigation Guidelines

    starling
    7
    0 Votes
    7 Posts
    2k Views
    Alex KushleyevA
    Hi @bschulzhf You need to copy the new sensormodule file with the correct slot id (number at the end) to /usr/lib/camera and (re)move the existing one, so that it does not get picked up by the camera pipeline. Good idea to back up your existing configuration before making changes. Also more general details here : https://docs.modalai.com/configure-cameras/#connect-a-new-camera Alex
  • 0 Votes
    6 Posts
    1k Views
    Hector GutierrezH
    @ApoorvThapliyal : the problem (Error message: "set_position_target_local_ned: coordinate frame 0 unsupported") appeared in QGC after updating VOXL SDK from 1.5.0 to 1.6.3. The error blocked me from being able to use QGC to calibrate or arm the drone. Stopping and restarting voxl-vision-hub solved the problem. For now I'm using voxl-vision-hub as it comes on SDK 1.6.3 (no changes yet) and have not made changes to the .conf file (yet).