
MAV_1_MODE not changing from Onboard on QGC
-
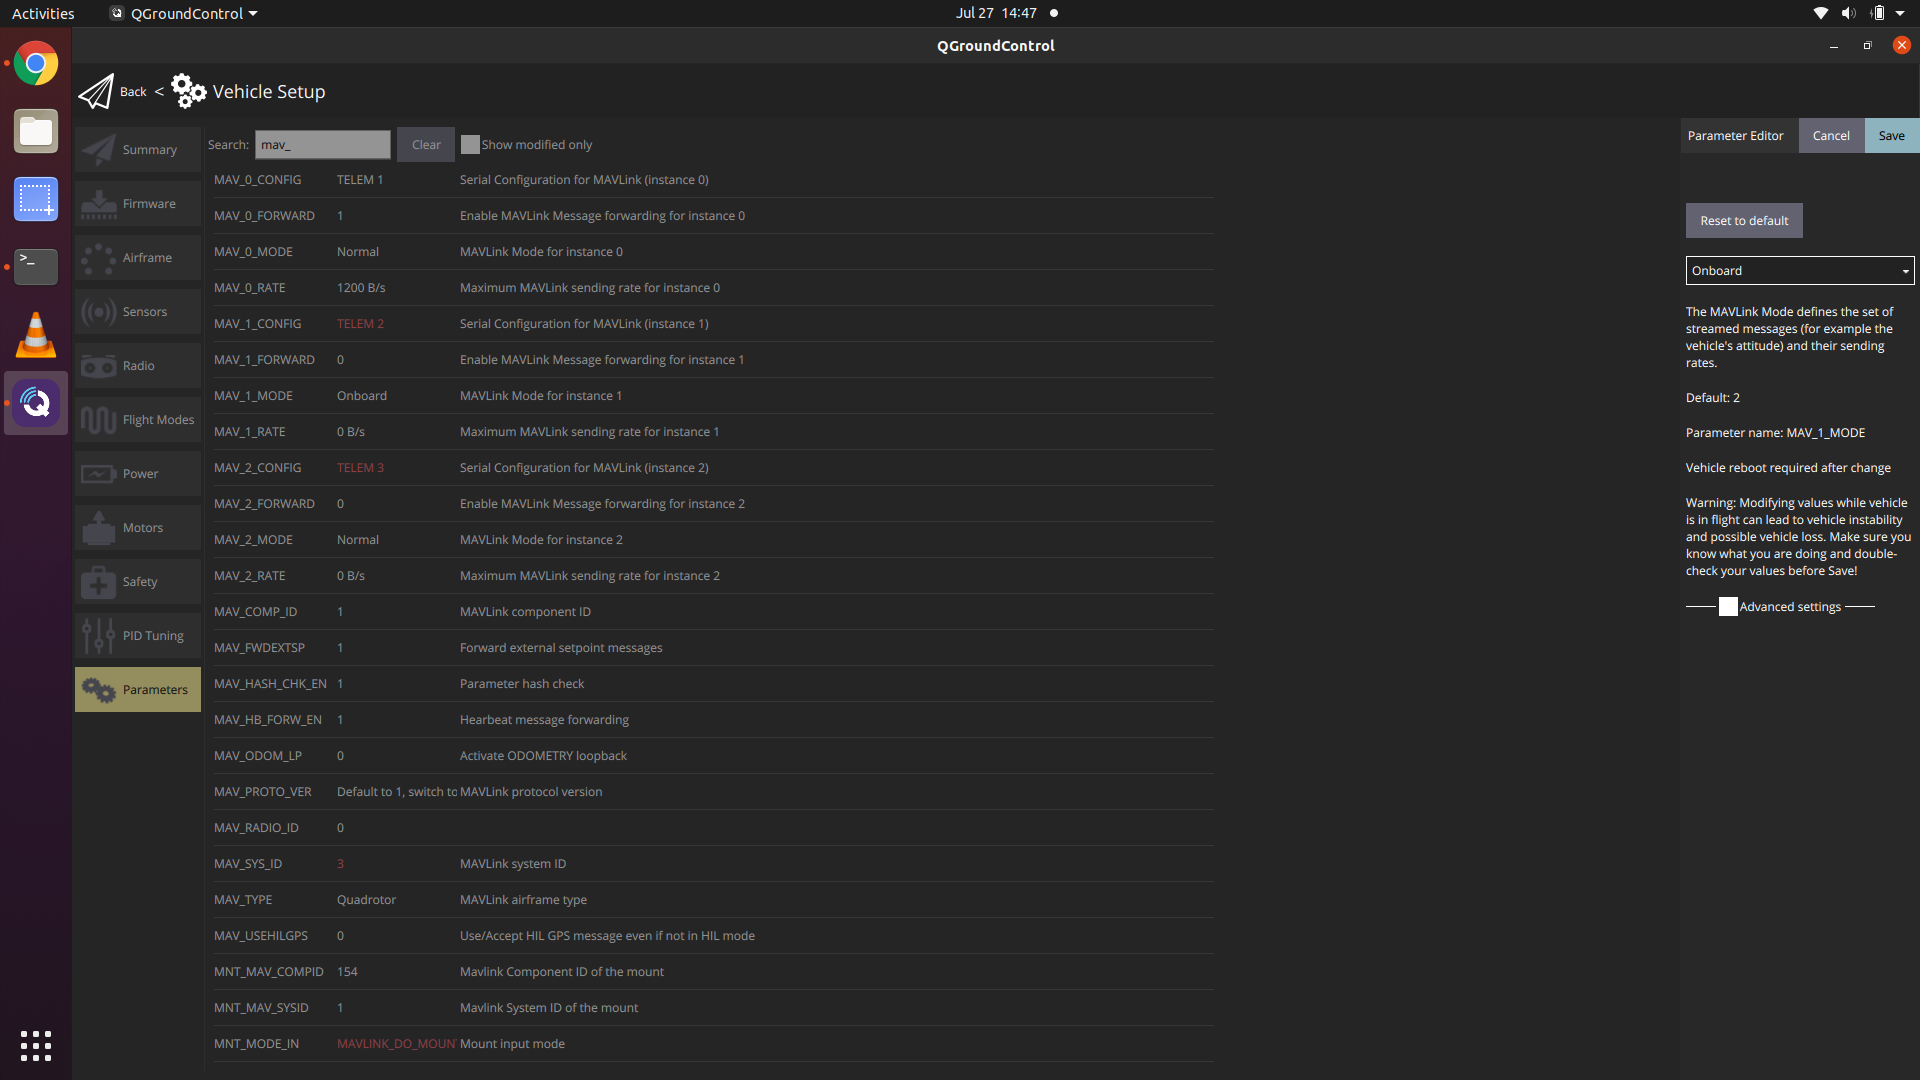
Hello, I am trying to establish a gimbal connection with mavlink according to https://docs.px4.io/master/en/peripherals/mavlink_peripherals.html, and I am trying to change the PX4 parameter MAV_1_Mode from Onboard to Normal. However, every time I try, the QGC immediately switches the mode back to Onboard. Is there a setting preventing this change? Rebooting is not effective.
-
If you have an M500, it contains either a VOXL Flight, and there's an internal UART from the PX4 processor (STM32F7) to the Snapdragon processor running linux.
This is setup on MAV1, and if changed would halt comms between the two systems.
https://github.com/PX4/PX4-Autopilot/blob/master/boards/modalai/fc-v1/init/rc.board_defaults#L23

Reading along? Create a free ModalAI Forum account to join in.
With an account you can reply, ask your own question, get an email when a ModalAI engineer answers, and mark the reply that solved it. Your place in each thread is saved between visits.
Questions about VOXL, Flight Core, ESCs and ModalAI drones are answered here by the engineers who build them.
Register Login