@yu-zhang Hi! I got quite confuse with this topic but, I would like to know. Did it work using the new Holybro motors with 920kv? I guess all the answers from Adrian were to get to make them work.
I ask because it has been difficult to find the motors I need for the m500.
Regards.
@modaltb I see. It's good to know the story
If 22027 is the default one, it will be all right.
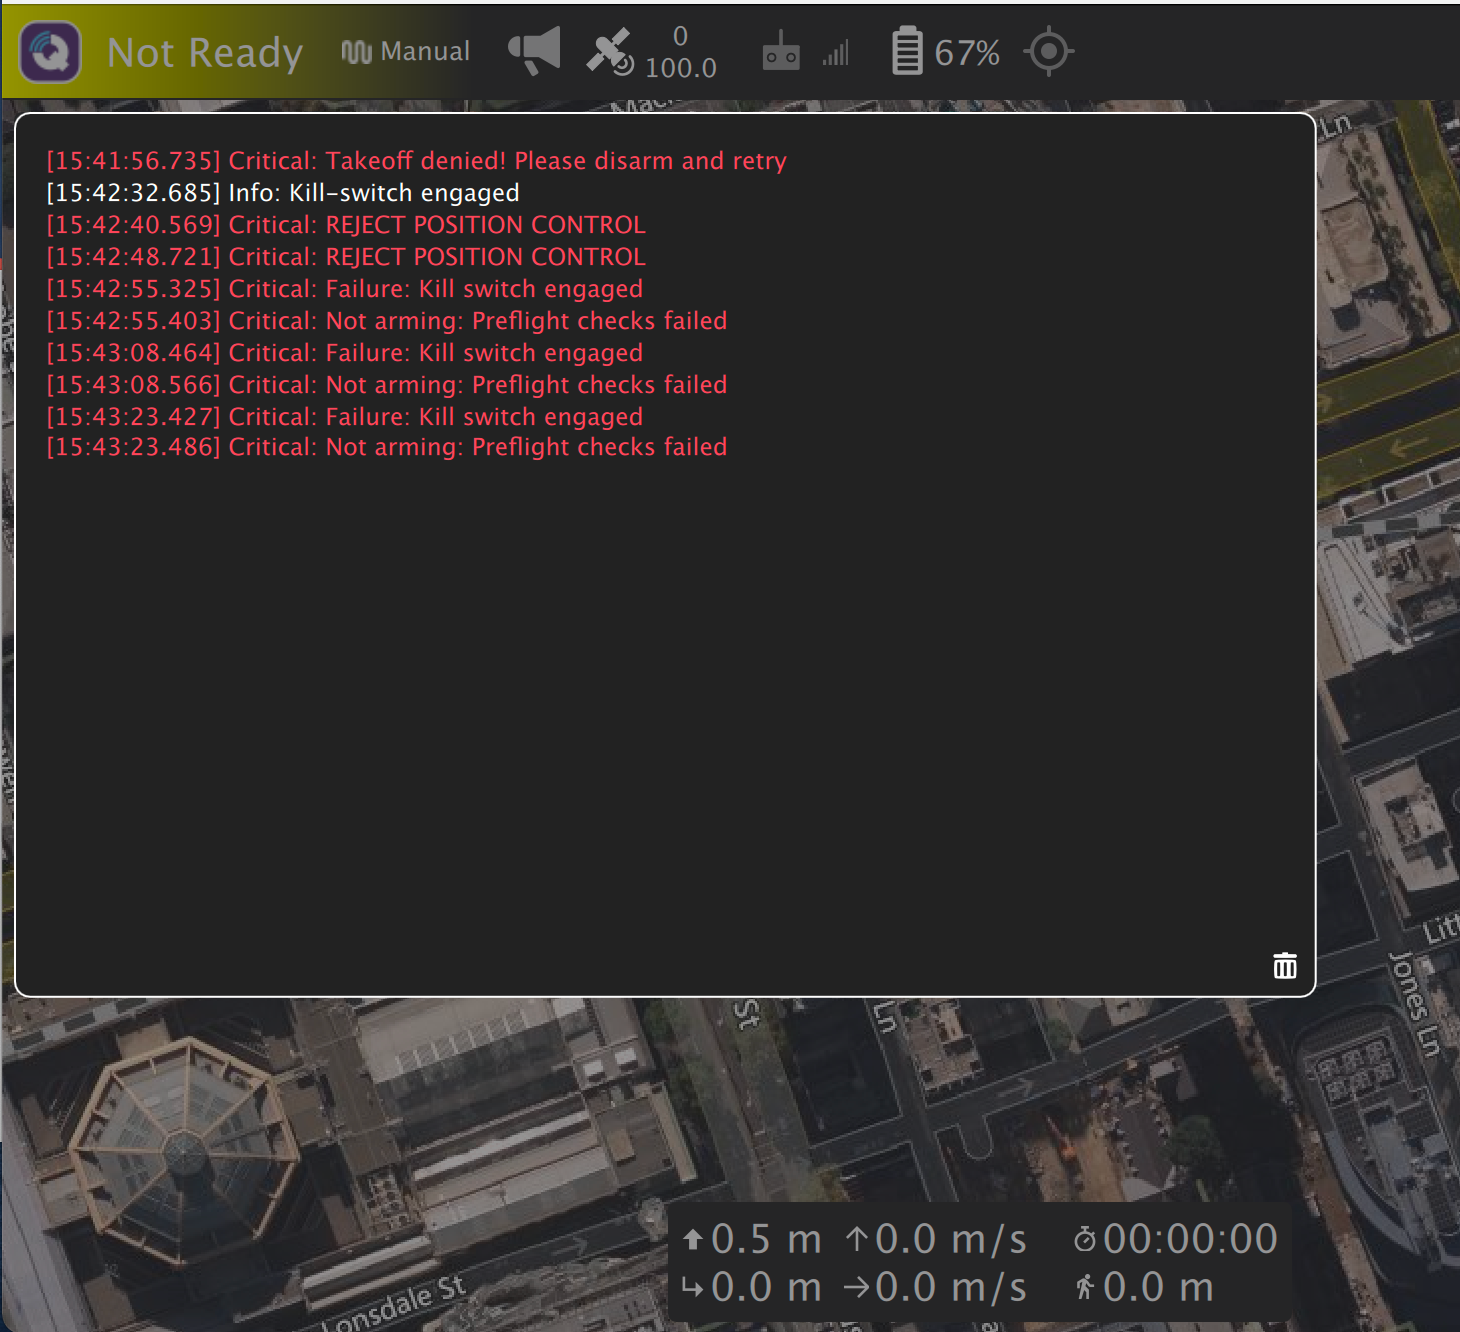
To be honest, I didn't touch the CBRK_IO_SAFETY before, and it's a bit weird why it was automatically modified for some reason.
Actually, I was trying to refresh a re-compiled 1.11.3-0.2.3 with my modification (increasing GPS log rate). So, I guess it might reset the value to 0 by PX4 default.
Anyways, thanks so much!
Hi @Chad-Sweet thanks for that, and it seems it could work by setting a higher value of the maximum speed in QGC. I will test it again to see if it could work to achieve a fast speed in the mission mode
@modaltb All right, I see. It does sound tough.
Instead, I think I may have a chance to only enable the stabilization by manually pre-set a fixed angle for the gimbal. If so, I don't need to connect to VOXL-flight, and I could just need to think about a separate power supply for the gimbal, right?
voxl-cross 1.7 is a build containing some new gcc toolchains for projects that are not yet on stable. The cross image is meant to be able to be easily built by any user, hence why it was built and installed when you installed the docker image. We've just pushed that image to the downloads page should you need to download it from there.
As for the docker image docs, you are correct they are out of date right now, we're planning to update them soon and have been delaying doing so because we've been making changes to them.
@modalab , I would try to add a gimbal with a camera or other sensors attached on the m500. So, simply extending the brittle tubing on the landing gear legs is quite unsafe for a gimbal set.
I think the extended landing gear on RB5 is the best option for the gimbal purpose. So, will you make the extended landing gear available in the upcoming release? If so, it would be much better to add an installation video for both RB5 and m500.
Hi @stevet Late to reply, and thanks so much for your instruction! It's great news for M1 developers like me
I will have a try if it works well, and let you know then.