
Need Urgent Support ASAP regarding Starling Max 2 Controller Arming issue
-
Hardware: (board / drone / SKU, serial # if you have it) Starling Max 2
Software version: (paste the output of
voxl-version) VOXLConfiguration / services: (paste the output of
voxl-inspect-services)What I am trying to do: The drone keeps drifting once takes off. Started with drone sensors calibration via QGround application which was successfully completed but drone was till drifting. Then performed the controller calibration which was successfully completed but now the controller does not arm the drone. The controller has connection to the drone and i can see the kill switch and mode switch updates reported on QGround application whereas the manual arm does not work.
What actually happens: (error messages, behavior)
After the controller calibration.Steps to reproduce: Calibrated via Q-Ground
Calibrate controller via QGround Application.Logs / pictures: (attach files; PX4 logs -> https://logs.px4.io)
Not sure how to retrieve this -
Hi @oiler251 , please follow these steps to diagnose the issue. It looks like Step 1 is ok, but double check it anyway.
Step 1: Check the RC protocol setting
SSH or ADB into the drone and check
/etc/modalai/voxl-px4.conf:cat /etc/modalai/voxl-px4.confLook for the
RCsetting. It must match your controller's protocol. For Ghost/GHST receivers (the Starling Max 2's default), it should read:RC=GHSTIf it shows
SPEKTRUM,SBUS, or anything else, change it toGHST(or whatever protocol your controller uses), then reboot:rebootThis exact issue caused arming failures for other Starling Max 2 users after running ESC or RC calibration — see this thread and this one for confirmed resolutions.
Step 2: Re-check RC calibration (switch channels)
If the protocol is correct, the calibration itself may have missed the switch channels. When you re-run RC calibration in QGroundControl, make sure you move all switches (kill switch, mode switch, and any others) through their full range when prompted. Channels 5–8 need to be swept or the calibration will leave them in a bad state.
Step 3: Check the specific arming failure reason in QGC
Connect to QGroundControl and attempt to arm. QGC will display a specific pre-arm failure message (e.g., "RC not calibrated", "Throttle too high", "Kill switch engaged"). That message will tell you exactly what PX4 is blocking on.
Common blockers:
- Throttle not at zero — left stick must be fully down before arming
- Kill switch active — ensure it's in the "disarmed" (off) position
- RC not calibrated — re-run calibration as above
Regarding the original drift issue:
Drift after takeoff is usually caused by an IMU or accelerometer calibration issue, or by flying in a mode that requires GPS/VIO when neither is available (or not configured). Once you get arming working, if drift persists, share the output of
voxl-inspect-servicesand a flight log — that will help diagnose whether it's a sensor calibration or an estimation/navigation issue.How to retrieve PX4 logs (for when you need them):
Option 1 — ADB over USB:
adb shell ls /data/px4/log          # list sessions
adb pull /data/px4/log/sess001/log001.ulg .
Option 2 — SCP over WiFi (replace IP with your drone's IP):
scp -r root@192.168.x.x:/data/px4/log ./px4_logsOption 3 — QGroundControl:
Go to Analyze → Log Download while connected over WiFi.Then upload the
.ulgfile to https://logs.px4.io for analysis.
Please try Step 1 first and report what the RC setting shows — that's resolved this exact symptom in at least two prior cases.
Sources
- Starling 2 Max Not Arming (forum post/19806) — RC protocol set to SPEKTRUM instead of GHST; confirmed fix
- Drone not flying manually with ORQA FPV.Ctrl controller (forum post/19647) — same RC protocol fix confirmed by ModalAI staff
- Arming Issues with Controller (forum post/3641) — controller switches visible in QGC but arm gesture not working
- Starling 2 Max does not roll and pitch in position mode — related flight behavior thread
- Downloading PX4 ulog files (forum post/7053) — log retrieval methods
- VOXL PX4 docs — official VOXL 2 PX4 documentation
-
Hi @alex-kushleyev Alex
I will follow the instructions tomorrow morning.
Regarding Channels 5–8 need to be swept during calibration, one of the steps ask for both joystick to be in certain position and left and right top button. In that case, do I press/toggle channel 5-8 all at once or one after another. The instructions were not clear, so I believe that may have caused the calibration at bad state as you mentioned. Would you mind provide steps particularly for channel 5-8 for Ghost RC.
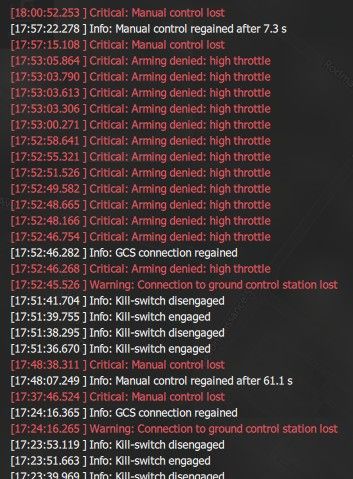
Also, are you available over the phone tomorrow if support needed.It looks like arming denied due to high throttle. I had throttle pulled all the way down and to the right for arming propeller as that is how it used to arm prior calibration.
-
Please refer to the standard PX4 calibration procedure for the RC. For example, more details here https://docs.px4.io/main/en/config/radio . You may also just need to clear your RC parameters from PX4.
You can also try to clear your calibration since it's normally not required : https://docs.qgroundcontrol.com/v4.4.3/en/qgc-user-guide/setup_view/radio.html
"
TIPYou can clear all parameter/tuning channel mappings by selecting menu Tools > Clear RC to Param at the top right of the Parameters screen.
" -
@alex-kushleyev
Thank you for additional information. I will try these instructions tomorrow morning and update you accordingly. -
@alex-kushleyev
I followed the instruction steps and still arming issue. Below are the steps result.
Step 1: The RC=GHST
Step 2: Re-run Calibration as per the instruction as well as per the video. Calibration Successful.
Step 3: Manual arm gesture does not report any error but if I set arm to channel 7, I can see Arming denied: high throttle message.
I also tried tried clear all RC to Param and does not arm the drone.Please, advise how can we troubleshoot further.
-
Is it mode 1 or mode 2 for Ghost RC calibration? Mine is mode 1 by default.
-
When you lower your throttle stick on the RC and look at the RC tab in QGC, does the throttle slider actually decrease or is it mapped to pitch? If you are assuming that throttle is the left stick (up down), that is Mode 2. Mode 1 would put throttle on the right joystick, so that seems like your issue.
-
I realized it would be mode 2 for Ghost joystick with left stick as throttle.
The drone arms with the controller now. The drone is tethered to a fixture inside our lab (GPS denied ambience) and when arm and takes off at manual mode, I can control less now. It use to be more controller with height adjustment and maneuvering clock wise or anti clock wise at 3 ft height. It is like jumping up and down and drift front, back, left and right.
Do I have to disable any sensors? -
@alex-kushleyev
Now is back to normal setting as it used to be whereas i still see the drift issue after take off.
Can you support how to configure it to hold position once take off?
My demo will be inside the building in big 20' x 30' closed area and I can not run this with drift in any direction after take off and hit the boundary net.
Can you advise how i can resolve this drifting issue?
Reading along? Create a free ModalAI Forum account to join in.
With an account you can reply, ask your own question, get an email when a ModalAI engineer answers, and mark the reply that solved it. Your place in each thread is saved between visits.
Questions about VOXL, Flight Core, ESCs and ModalAI drones are answered here by the engineers who build them.
Register Login