
Immediate crashes in HITL
-
Here is a readout of the
qshell dsp_hitl statuscommand, just to validate the connection: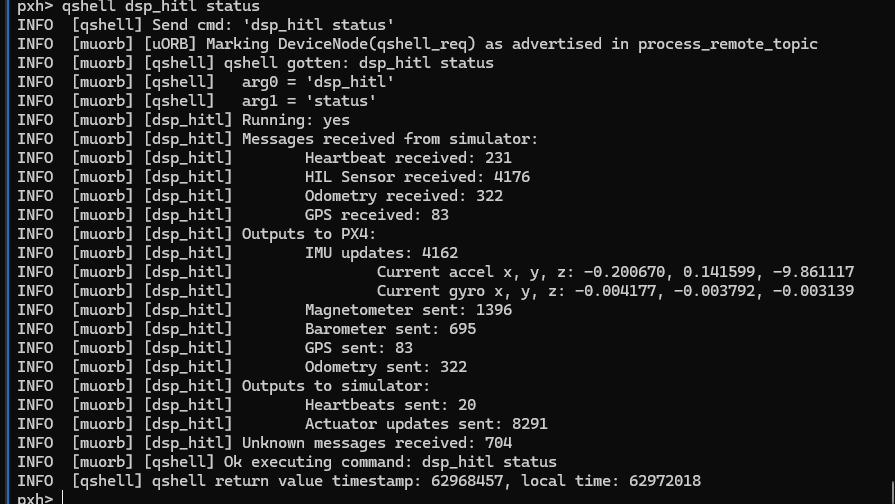
-
Here is a readout of the
qshell dsp_hitl statuscommand, just to validate the connection:@shawn_ricardo What command did you use to start HITL? Are you trying hold mode with GPS?
-
@shawn_ricardo What command did you use to start HITL? Are you trying hold mode with GPS?
Hi @Eric-Katzfey,
To start HITL, I used
voxl-px4-hitlI ran the commands:
1) qshell commander arm
2) qshell commander takeoff
which will eventually go into HOLD mode.
As far as the sensor positioning input, I'm assuming that I'm using GPS because I followed this instruction to turn off qvio:
NOTE: Ensure that voxl-qvio-server is disabled. If it is enabled, it will confuse gazebo due to gazebo sending fake sensor data to the qvio algorithm and causing poor flight dynamics in HITL. This can be done with the systemctl disable voxl-qvio-server command.Here are the services running via
voxl-inspect-services. Note thatvoxl-px4is not running because the sim is not running: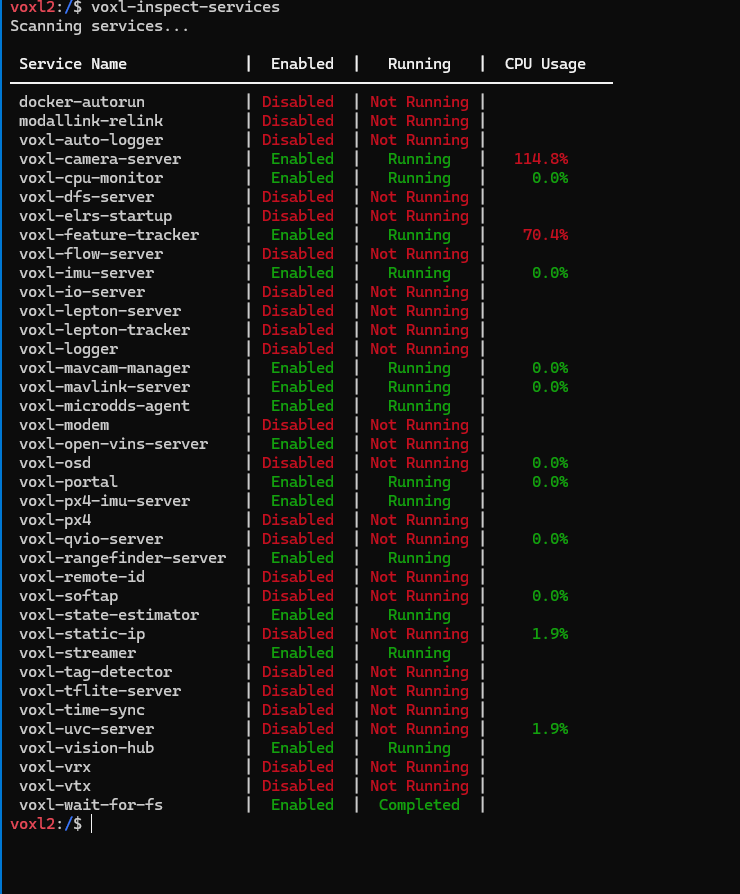
-
@Eric-Katzfey , would you happen to recommend next troubleshooting steps?
-
@Eric-Katzfey , would you happen to recommend next troubleshooting steps?
@shawn_ricardo I'll try it on my setup and see what happens.
-
@Eric-Katzfey , would you happen to recommend next troubleshooting steps?
@shawn_ricardo I just tried it and it worked fine. But I had all services disabled except for voxl-wait-for-fs, voxl-mavlink-server, and voxl-cpu-monitor. So maybe try that.
-
@Eric-Katzfey , would you happen to recommend next troubleshooting steps?
@shawn_ricardo Can you capture the log of startup messages for voxl-px4-hitl so I can look for any error messages, or incorrect settings?
-
Hi @Eric-Katzfey ,
I've tried those settings and the drone is able to stay hovering much long than expected. the positioning appears to be better, as well.
What service(s) might be getting in the way of HITL performance?
Also, I noticed during flight the drone vibrates significantly in HITL as soon as I publish offboard commands while in HOLD mode according to PX4's offboard guidelines. As soon as I stop publishing to
/fmu/in/trajectory_setpoint, the vibrations stop. It is as if the drone is toggling between offboard and hold modes.I have "offboard_mode" set to "off" in /etc/modalai/voxl-vision-hub.conf. I am running my own ros2 offboard node. I've enabled
voxl-cpu-monitor,voxl-microdds-agent,voxl-modem, andvoxl-wait-for-fs. I am running the deb package ofvoxl_mpa_to_ros2. The command I am running isros2 run voxl_mpa_to_ros2 voxl_mpa_to_ros2_nodeI've tested the ability to publish offboard commands while in position hold mode in a completely separate px4 sim environment (just regular PX4 sim) and verified that drone position does not "vibrate" while offboard commands are being publishing and hold mode is the active mode.
What could be the cause of this behavior issue?
-
Hi @Eric-Katzfey ,
I've tried those settings and the drone is able to stay hovering much long than expected. the positioning appears to be better, as well.
What service(s) might be getting in the way of HITL performance?
Also, I noticed during flight the drone vibrates significantly in HITL as soon as I publish offboard commands while in HOLD mode according to PX4's offboard guidelines. As soon as I stop publishing to
/fmu/in/trajectory_setpoint, the vibrations stop. It is as if the drone is toggling between offboard and hold modes.I have "offboard_mode" set to "off" in /etc/modalai/voxl-vision-hub.conf. I am running my own ros2 offboard node. I've enabled
voxl-cpu-monitor,voxl-microdds-agent,voxl-modem, andvoxl-wait-for-fs. I am running the deb package ofvoxl_mpa_to_ros2. The command I am running isros2 run voxl_mpa_to_ros2 voxl_mpa_to_ros2_nodeI've tested the ability to publish offboard commands while in position hold mode in a completely separate px4 sim environment (just regular PX4 sim) and verified that drone position does not "vibrate" while offboard commands are being publishing and hold mode is the active mode.
What could be the cause of this behavior issue?
@shawn_ricardo To figure out which service could be causing the issue just try starting each one and see which one causes the issue.
-
@shawn_ricardo To figure out which service could be causing the issue just try starting each one and see which one causes the issue.
Okay, I'll keep this in mind as I develop toward offboard control. If I find any more information, I'll follow up here.
Just a side note: I don't see this behavior in real-world flight during manual or position, seems to be isolated to HITL at this point in time.
Thanks!

Reading along? Create a free ModalAI Forum account to join in.
With an account you can reply, ask your own question, get an email when a ModalAI engineer answers, and mark the reply that solved it. Your place in each thread is saved between visits.
Questions about VOXL, Flight Core, ESCs and ModalAI drones are answered here by the engineers who build them.
Register Login