
Indoor Altitude Estimate Divergence
-
Hey All,
Testing indoors I've had several instances of altitude estimate divergence requiring reversion to manual control and an emergency landing on a starling 2 max.
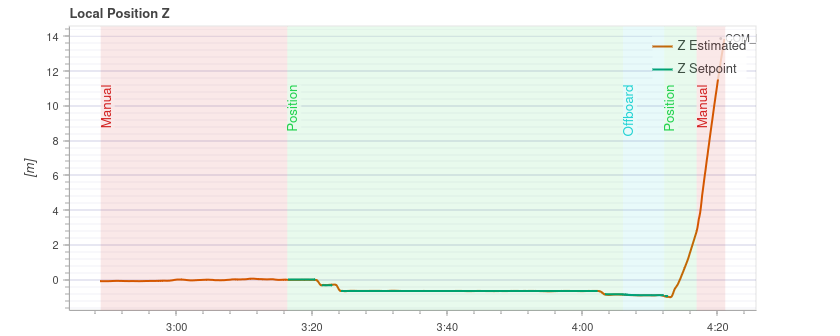
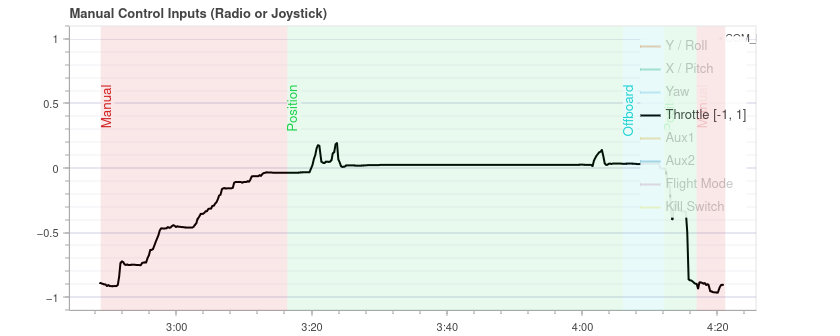
It seems that the error begins when I activate the offboard mode with the default figure 8 loaded.
My assumption is that as the drone yaws it loses some of the VIO points and is uncertain about its altitude causing a rapid climb in offboard and position modes.What would the best way be to correct this issue?
- I could try to add visual markers (i.e. april tags) to the warehouse walls to provide more references?
- Does the starling 2 max use both forward and downward facing cameras for VIO? I thought I saw a post about this feature being enabled in the nightly builds but am unsure.
- Should I expect these issues to improve inherently by moving into a more visually active space (inside an unoccupied office area)? I am hesitant to fly in more confined areas without being confident in the aircraft estimate and position holding reliability.
Kind regards,
Griffin -
Hey All,
Testing indoors I've had several instances of altitude estimate divergence requiring reversion to manual control and an emergency landing on a starling 2 max.
It seems that the error begins when I activate the offboard mode with the default figure 8 loaded.
My assumption is that as the drone yaws it loses some of the VIO points and is uncertain about its altitude causing a rapid climb in offboard and position modes.What would the best way be to correct this issue?
- I could try to add visual markers (i.e. april tags) to the warehouse walls to provide more references?
- Does the starling 2 max use both forward and downward facing cameras for VIO? I thought I saw a post about this feature being enabled in the nightly builds but am unsure.
- Should I expect these issues to improve inherently by moving into a more visually active space (inside an unoccupied office area)? I am hesitant to fly in more confined areas without being confident in the aircraft estimate and position holding reliability.
Kind regards,
Griffin@admin @Moderator Any suggestions on how to prevent this altitude divergence? This happens somewhat regularly and requires reversion to manual control.
Reading along? Create a free ModalAI Forum account to join in.
With an account you can reply, ask your own question, get an email when a ModalAI engineer answers, and mark the reply that solved it. Your place in each thread is saved between visits.
Questions about VOXL, Flight Core, ESCs and ModalAI drones are answered here by the engineers who build them.
Register Login