
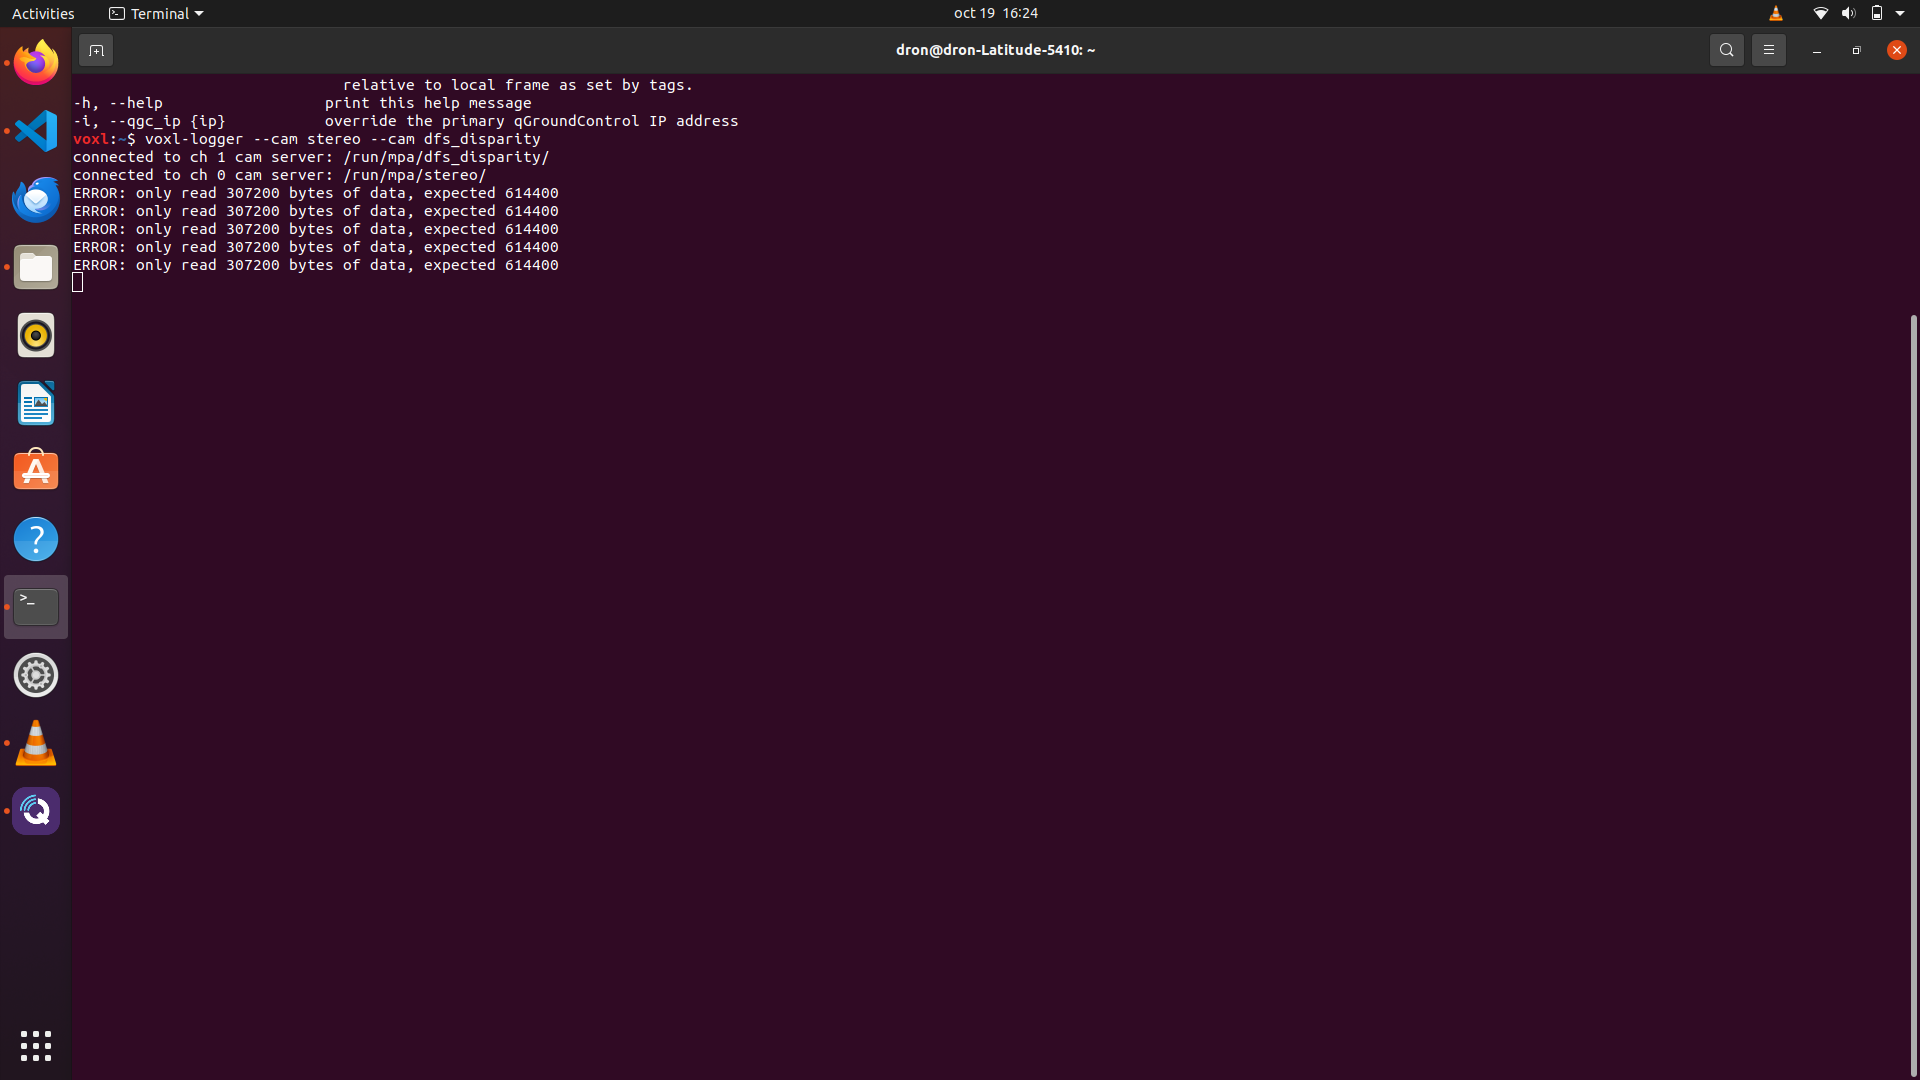
Error while voxl-logger --cam stereo -cam dfs_disparity
-
I'm trying to use the obstacle avoidance for a proyect but I got some errors, the more recent one is this one
I try following this guide:https://docs.modalai.com/voxl-vision-px4-collision-prevention-0_9/
But I couldn't get through this part: Debugging Collision PreventionBut even though I decided to enable the voa to qgc and my drone keeps connecting and disconnecting and when I activate the obstacle avoidance its says I have an error in the pre arm check and the obstacle avoidance it's not ready

Reading along? Create a free ModalAI Forum account to join in.
With an account you can reply, ask your own question, get an email when a ModalAI engineer answers, and mark the reply that solved it. Your place in each thread is saved between visits.
Questions about VOXL, Flight Core, ESCs and ModalAI drones are answered here by the engineers who build them.
Register Login