
Tracking Camera's Pose Relative to Drone
-
I need to know the camera's position and orientation relative to the drone's body frame. This is so I can calculate its homogenous transformation relative to the drone, and then combine that camera imagery to localize detected objects in 3D space.
I need to know the values of dx, dz and theta from this image:
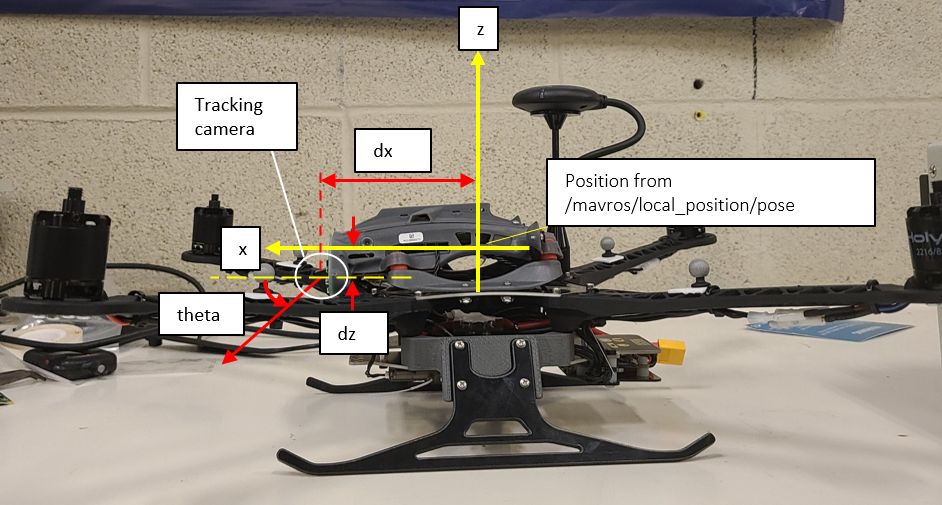
I'm assuming that the camera is centered laterally, so dy=0 (please correct me if this is incorrect), and that there is no roll or yaw with regards to its orientation. Hence the theta is the pitch or how much the camera is rotated along the y axis. Positive direction of y axis in image is out of the page. -
Hi,
If you're running the rb5 flight with VOXL SDK on it, you can see the relations between elements in
/etc/modalai/extrinsics.conf, if not you can see the file that would've been put there here. We don't havetracking-->bodyrelation defined directly but we havetracking-->px4 imuandpx4_imu-->bodyallowing you to calculate the relation. -
Hi,
If you're running the rb5 flight with VOXL SDK on it, you can see the relations between elements in
/etc/modalai/extrinsics.conf, if not you can see the file that would've been put there here. We don't havetracking-->bodyrelation defined directly but we havetracking-->px4 imuandpx4_imu-->bodyallowing you to calculate the relation.Thanks, that's exactly what I'm looking for

Reading along? Create a free ModalAI Forum account to join in.
With an account you can reply, ask your own question, get an email when a ModalAI engineer answers, and mark the reply that solved it. Your place in each thread is saved between visits.
Questions about VOXL, Flight Core, ESCs and ModalAI drones are answered here by the engineers who build them.
Register Login