
VOXL2 Camera Calibration fails and bad QVIO tracking
-
Drone specification:
I am currently using Starling 2 Max with
- Dual 4k & Dual Tracking & ToF (C29)
- Microhard pMDDL2450 WiFi
- Ghost Atto 2.4GHz
- SKU: MRB-D0012-4-V2-C29-M11-T9-K3 (NOTE: This SKU is from the order receipt, which is different from the one shown when connected to the drone)
system-image: 1.8.06-M0054-14.1a-perf
kernel:       #1 SMP PREEMPT Wed Oct 22 04:13:18 UTC 2025 4.19.125
hw platform:  M0054
mach.var:     1.0.1
SKU:          MRB-D0012-4-V2-C29-T9-M22-X0
voxl-suite:   1.6.3
Cause:
I recently flashed my VOXL2 board by following "Unbricking your VOXL2" page. This wipes all calibration files, of which I generated new ones by calibrating the drone again.
However, I am having issue getting a successful camera calibration with the same error every time:
Re-projection error reported by calibrateCamera: 1.26416
Calibration Failed
Max reprojection error: 0.60
This is most likely due to motion blur, please try again.
Exiting Cleanly
I have tried to debug by following these suggestions below:
https://forum.modalai.com/post/22010
https://forum.modalai.com/post/22066
https://forum.modalai.com/post/21909
However, none of these fixes the max reprojection error.Finally, I manually write the files:
- /data/modalai/opencv_tracking_front_intrinsics.yml
- /data/modalai/opencv_tracking_down_intrinsics.yml
by using the camera matrix from the trial with smallest reprojection error (close to ~0.6).
Current Issue:
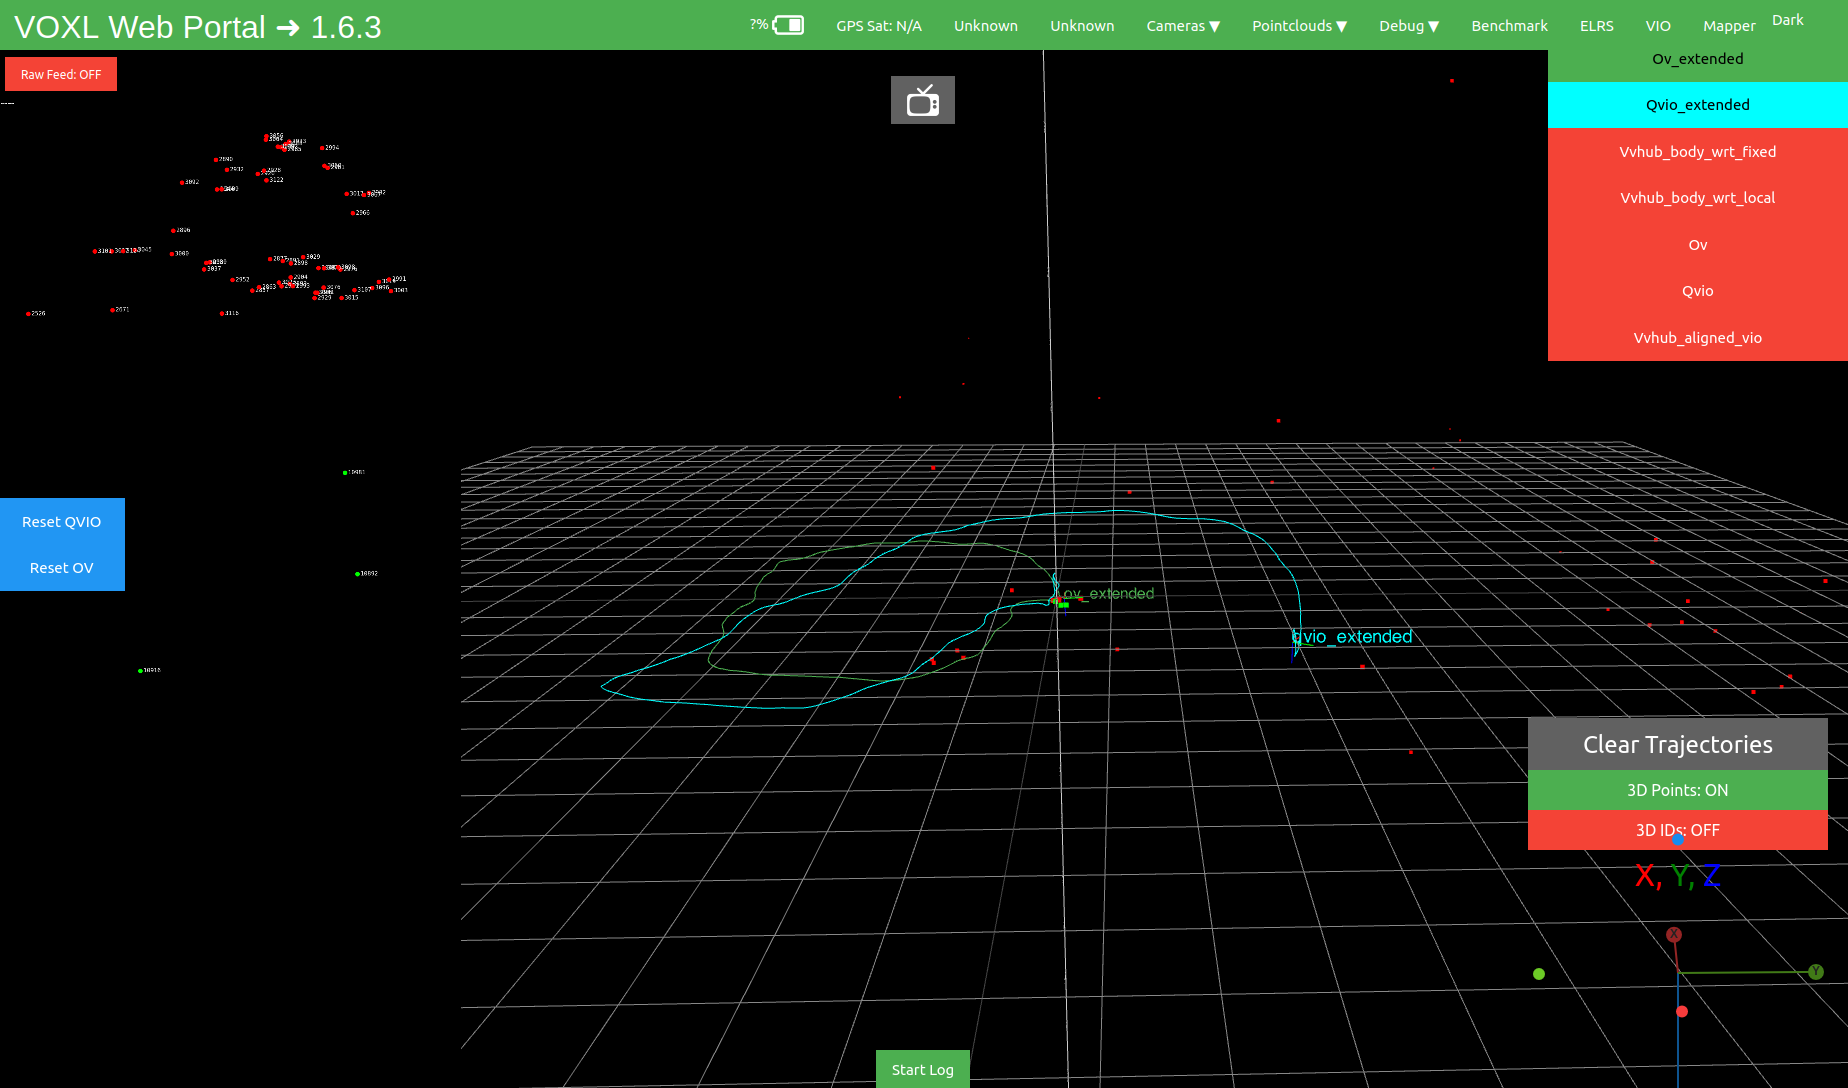
My problem now is that, since the calibration files use bad camera matrices, the qvio tracking of the drone is inaccurate and drifts a lot. Here, I tested the front and downward camera by walking around in circle and returning the drone to the exact starting position. The result shows a lot of drift in both qvio_extended and ov_extended
My questions are:
- Could the reflash have altered camera driver versions, exposure/gain settings, or
voxl-camera-serverconfig from factory defaults? - Is there a way to compare my current per-camera intrinsics files against known-good factory defaults for the M0054 platform?
- Are there other config I should try to change to aid the camera calibration process?
- Is there any other open-source code that allows me to manually calibrate the camera?
Thank you for your time and help!
Reading along? Create a free ModalAI Forum account to join in.
With an account you can reply, ask your own question, get an email when a ModalAI engineer answers, and mark the reply that solved it. Your place in each thread is saved between visits.
Questions about VOXL, Flight Core, ESCs and ModalAI drones are answered here by the engineers who build them.
Register Login