
Cannot arm Starling in Position mode
-
I'm trying to arm Starling without GPS and have calibrated the VIO camera, but QGC just shows "MAV_CMD_COMPONENT_ARM_DISARM component temporarily rejected" without any other messages when I try to arm it in position mode. I didn't see any useful logs when I ran "voxl-px4 -d" too.
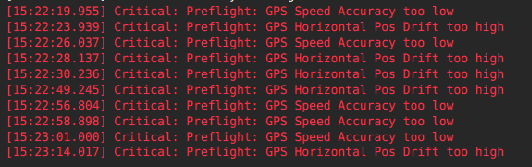
I tested that I can arm it in manual mode, although I have never successfully armed it in position mode before. Even when I tried with GPS, it kept giving me preflight failures (GPS speed accuracy, drift,etc.).
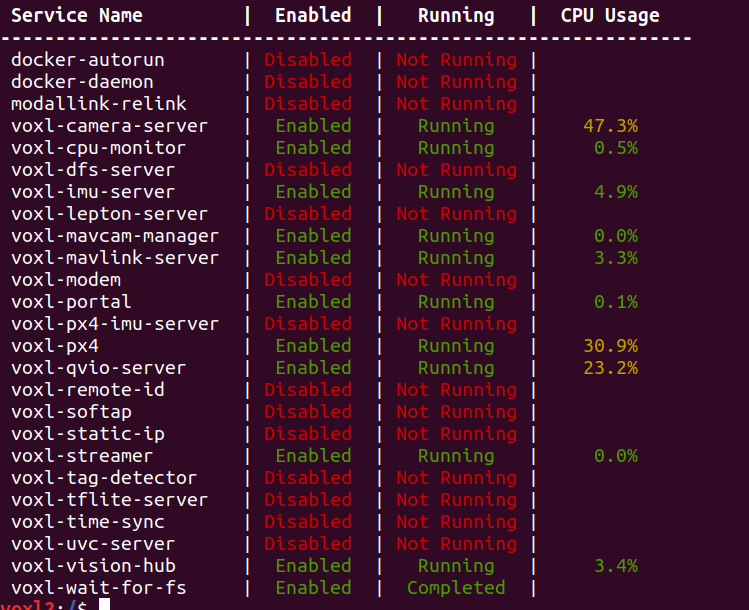
For this case without GPS, I'm running the following services
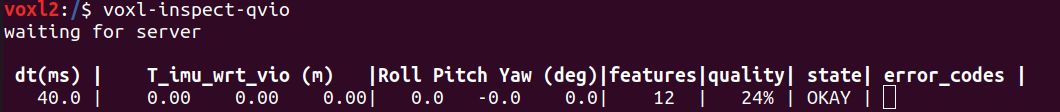
I can see that qvio is running
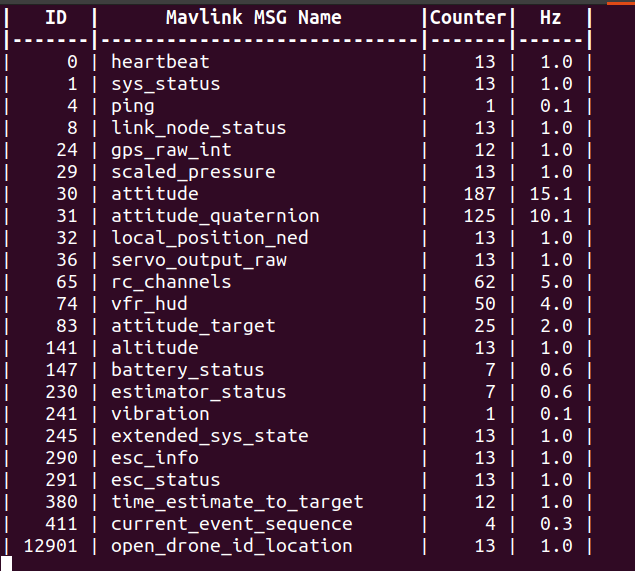
The mavlink messages are also being sent (mavlink_to_gcs)
So I'm not sure why it doesn't arm?
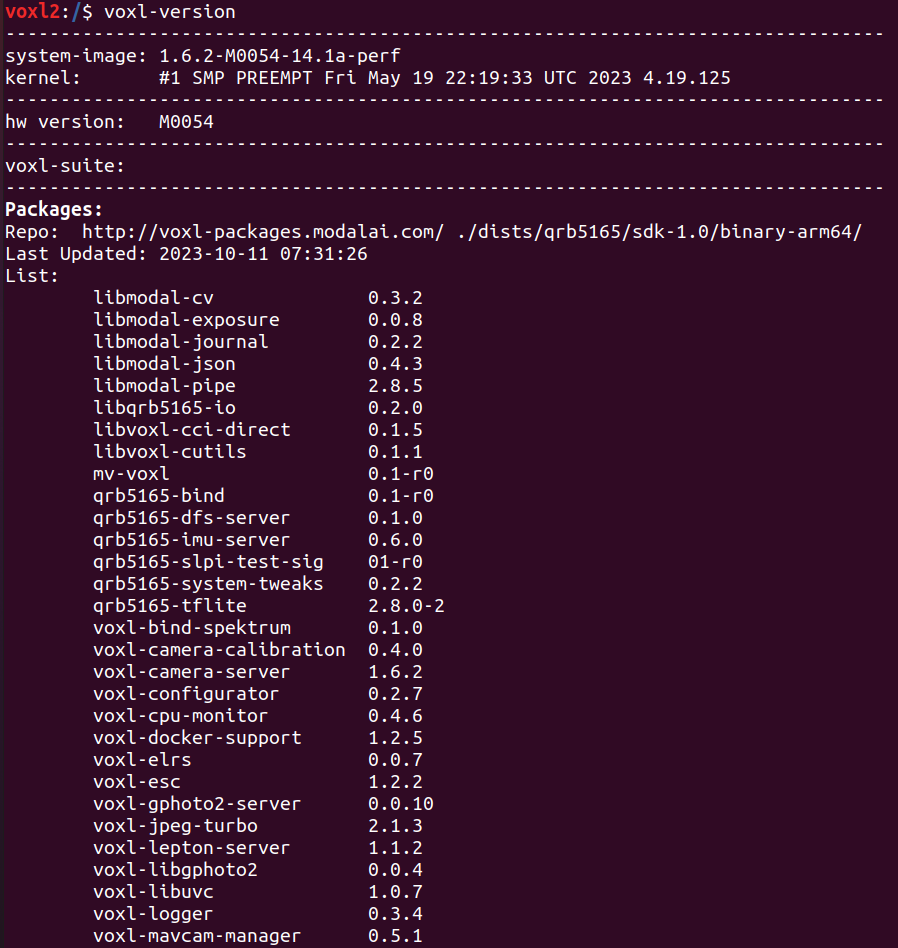
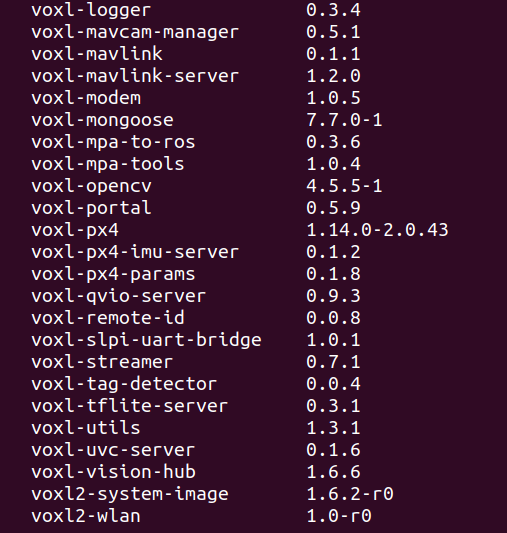
voxl-version: (I just realised the voxl-suite doesn't show 1.0.0? I had re-flashed VOXL SDK 1.0 on this previously)
-
I'm trying to arm Starling without GPS and have calibrated the VIO camera, but QGC just shows "MAV_CMD_COMPONENT_ARM_DISARM component temporarily rejected" without any other messages when I try to arm it in position mode. I didn't see any useful logs when I ran "voxl-px4 -d" too.
I tested that I can arm it in manual mode, although I have never successfully armed it in position mode before. Even when I tried with GPS, it kept giving me preflight failures (GPS speed accuracy, drift,etc.).
For this case without GPS, I'm running the following services
I can see that qvio is running
The mavlink messages are also being sent (mavlink_to_gcs)
So I'm not sure why it doesn't arm?
voxl-version: (I just realised the voxl-suite doesn't show 1.0.0? I had re-flashed VOXL SDK 1.0 on this previously)
@kerct did you remove the GPS? It is showing errors related to GPS
You can upload your PX4 log to logs.px4.io and it will likely tell you

Reading along? Create a free ModalAI Forum account to join in.
With an account you can reply, ask your own question, get an email when a ModalAI engineer answers, and mark the reply that solved it. Your place in each thread is saved between visits.
Questions about VOXL, Flight Core, ESCs and ModalAI drones are answered here by the engineers who build them.
Register Login