
Vision failure everytime during takeoff
-
My next step is to share some PX4 params (pid settings, cutoff filters) that got my sentinel stable, but I need my team to validate before sending. I’m not clear if this will solve everything but will at least be a good data point. I’m hoping to get this tested tomorrow and will share
-
@Tamas-Pal-0 ...
I still have nothing to report as far as finding root cause of something, after our tune tweaks I was up and going. I am still testing though for this use case to see if there's some edge case I'm not seeing, I'm just a bit slow with this debugging.
As far as sharing my params that got me flying, I don't even know if my approach here is valid, you have different motor/prop setup, and frames aren't identical, battery type?...
My lawyer told me to tell you "not to use these since we don't have the same setup and the author/developer in the post here isn't really a pilot so...." You've been warned by the lawyer!

# Pitch PID
1	1	MC_PITCH_P	5.5	9
1	1	MC_PITCHRATE_P	0.065	9
1	1	MC_PITCHRATE_I	0.150	9
1	1	MC_PITCHRATE_D	0.002	9
1	1	MC_PITCHRATE_K	1.0	9

# Roll PID
1	1	MC_ROLL_P	5.5	9
1	1	MC_ROLLRATE_P	0.065	9
1	1	MC_ROLLRATE_I	0.150	9
1	1	MC_ROLLRATE_D	0.002	9
1	1	MC_ROLLRATE_K	1.0	9

# Yaw PID
1	1	MC_YAW_P	2.0	9
1	1	MC_YAWRATE_P	0.15	9
1	1	MC_YAWRATE_I	0.10	9
1	1	MC_YAWRATE_D	0.0	9
1	1	MC_YAWRATE_K	1.0	9

################################################################################
# Noise management
################################################################################
1	1	MOT_SLEW_MAX	0.0	9
1	1	IMU_DGYRO_CUTOFF	30.0	9
1	1	IMU_ACCEL_CUTOFF	30.0	9
1	1	IMU_GYRO_CUTOFF	30.0	9
Checkout out noise management here... I've had some nasty flights due to cutoff frequencies.
-
@Tamas-Pal-0 ...
I still have nothing to report as far as finding root cause of something, after our tune tweaks I was up and going. I am still testing though for this use case to see if there's some edge case I'm not seeing, I'm just a bit slow with this debugging.
As far as sharing my params that got me flying, I don't even know if my approach here is valid, you have different motor/prop setup, and frames aren't identical, battery type?...
My lawyer told me to tell you "not to use these since we don't have the same setup and the author/developer in the post here isn't really a pilot so...." You've been warned by the lawyer!
# Pitch PID
1	1	MC_PITCH_P	5.5	9
1	1	MC_PITCHRATE_P	0.065	9
1	1	MC_PITCHRATE_I	0.150	9
1	1	MC_PITCHRATE_D	0.002	9
1	1	MC_PITCHRATE_K	1.0	9

# Roll PID
1	1	MC_ROLL_P	5.5	9
1	1	MC_ROLLRATE_P	0.065	9
1	1	MC_ROLLRATE_I	0.150	9
1	1	MC_ROLLRATE_D	0.002	9
1	1	MC_ROLLRATE_K	1.0	9

# Yaw PID
1	1	MC_YAW_P	2.0	9
1	1	MC_YAWRATE_P	0.15	9
1	1	MC_YAWRATE_I	0.10	9
1	1	MC_YAWRATE_D	0.0	9
1	1	MC_YAWRATE_K	1.0	9

################################################################################
# Noise management
################################################################################
1	1	MOT_SLEW_MAX	0.0	9
1	1	IMU_DGYRO_CUTOFF	30.0	9
1	1	IMU_ACCEL_CUTOFF	30.0	9
1	1	IMU_GYRO_CUTOFF	30.0	9
Checkout out noise management here... I've had some nasty flights due to cutoff frequencies.
-
Any chance you could post a link to a video of a flight to help us understand the failure mode even more? Sorry to this going, but we're struggling to find a smoking gun.
@modaltb I am using your parameters here and disbaled the modalai_esc driver. The video link is here
https://drive.google.com/file/d/1cbBXsEFMLztR7F1_en4i77F1ww4LbQ1t/view?usp=sharing -
OK thanks for the data. This is where I'm at now with my VOXL2 / VOXL2 IO setup sentinel, it's not super clean yet but but flyable for sure:
https://www.youtube.com/watch?v=1INto92k-v0I'm getting our team to do a real tune and early this week and will post info.
-
OK thanks for the data. This is where I'm at now with my VOXL2 / VOXL2 IO setup sentinel, it's not super clean yet but but flyable for sure:
https://www.youtube.com/watch?v=1INto92k-v0I'm getting our team to do a real tune and early this week and will post info.
-
Hi @Tamas-Pal-0 ,
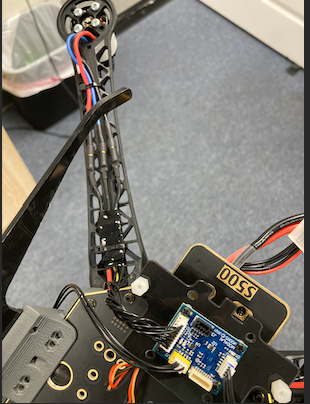
These are BLHeli 20A, should be similar/same as the ones from this kit: https://shop.holybro.com/spare-parts-s500-kit_p1251.html
Here's my setup:
-
Hi @Tamas-Pal-0 ,
These are BLHeli 20A, should be similar/same as the ones from this kit: https://shop.holybro.com/spare-parts-s500-kit_p1251.html
Here's my setup:
-
On my setup yes that was all I needed to do, but we are still going to do a "full proper tune" on our S500 based frame (Sentinel dev drone) and I will confirm with you that we are getting performance as expected after this and share a video. Our flight test team will be doing that this week, thanks for the patience!!!

Reading along? Create a free ModalAI Forum account to join in.
With an account you can reply, ask your own question, get an email when a ModalAI engineer answers, and mark the reply that solved it. Your place in each thread is saved between visits.
Questions about VOXL, Flight Core, ESCs and ModalAI drones are answered here by the engineers who build them.
Register Login