
TOF detecting non-existing objects
-
Hi everyone,
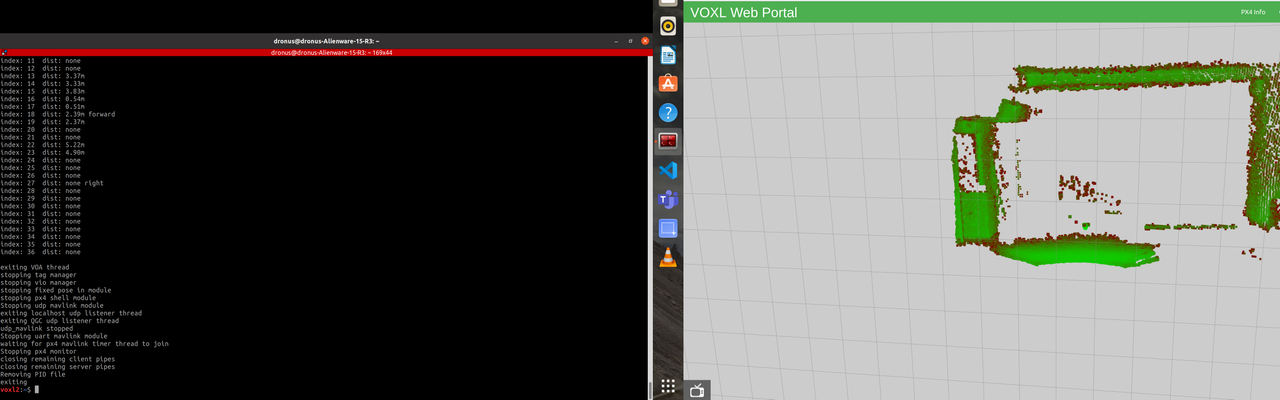
I am trying to detect obstacles with a TOF sensor on VOXL2 by placing it in front of the drone. However, as you can see in the picture below, the sensor is detecting a fake object (distant ~0.5m) even if there's nothing in front of the drone. Are there any parameters in the .conf files where I can tune the confidence of the sensor or apply some sort of filtering?
Reading along? Create a free ModalAI Forum account to join in.
With an account you can reply, ask your own question, get an email when a ModalAI engineer answers, and mark the reply that solved it. Your place in each thread is saved between visits.
Questions about VOXL, Flight Core, ESCs and ModalAI drones are answered here by the engineers who build them.
Register Login