
Read Point Cloud Data by ROS (voxl-dfs-server, voxl_mpa_to_ros, MV SDK)
-
Hi
Do you plan to include the interface for voxl-dfs-server in the voxl_mpa_to_ros?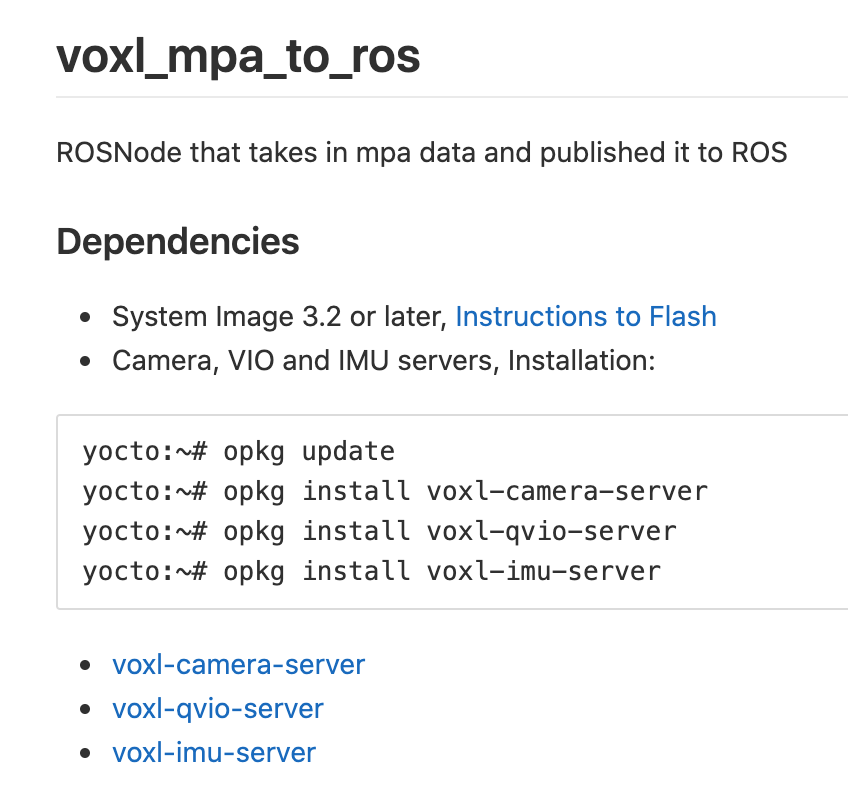
On the other hand, I try to use the voxl-camera-server + voxl_mpa_to_ros + dfs_ros_example(https://github.com/ATLFlight/dfs-ros-example) to get the point cloud data for ROS.
The dfs_ros_example requires mvDFS.h. Therefore MV SDK needs to be installed. For your info, I'm developing ROS applications in a docker container deployed on VOXL.
But I met the following issure:root@apq8096:~/yoctohome# dpkg -i mv_1.2.13_8x74.deb dpkg: error processing archive mv_1.2.13_8x74.deb (--install): package architecture (armhf) does not match system (arm64) Errors were encountered while processing: mv_1.2.13_8x74.debHowever, I can see the MV SDK is preinstalled when I flash the system image 3.2.0.
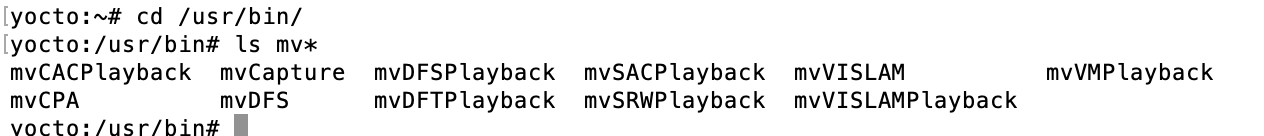
How do you manage to install it? I want to install it again in the docker container.
My current environment:
System Image 3.2.0 + Docker(Ubuntu18.04, ROS melodic)yocto:~# opkg list-installed | grep "libmodal" libmodal_json - 0.3.4 libmodal_pipe - 1.7.9 yocto:~# opkg list-installed | grep "voxl" libvoxl_io - 0.5.4 voxl-camera-server - 0.5.5 voxl-dfs-server - 0.0.7 voxl-docker-support - 1.1.1 voxl-imu-server - 0.7.8 voxl-mpa-tools - 0.1.6 voxl-nodes - 0.1.2 voxl-qvio-server - 0.2.1 voxl-streamer - 0.2.1 voxl-utils - 0.5.9 voxl-vision-px4 - 0.8.1

Reading along? Create a free ModalAI Forum account to join in.
With an account you can reply, ask your own question, get an email when a ModalAI engineer answers, and mark the reply that solved it. Your place in each thread is saved between visits.
Questions about VOXL, Flight Core, ESCs and ModalAI drones are answered here by the engineers who build them.
Register Login