
Collision prevention depth calculation results in empty image
-
I'm on the latest version of voxl-dfs-server, and I'm attempting to get collision prevention working, but I went through the code and it seems like the disparity computation is resulting in an empty matrix. In result, it's detecting no objects.
I've also tried placing a board infront of the camera and moved it around, but no luck.
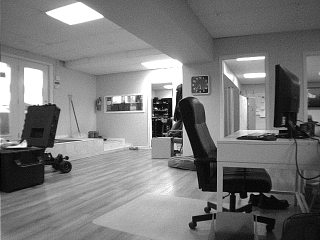
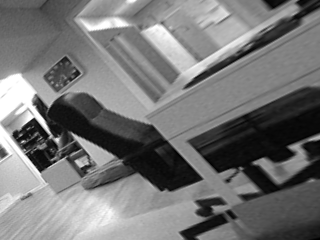
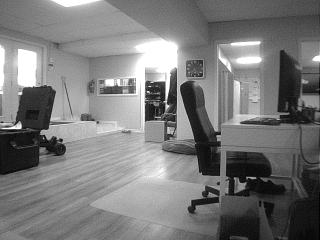
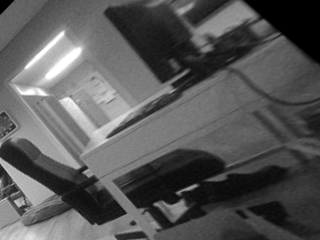
I've attached the dsp image, as well as the input from the stereo cameras. I've calibrated the cameras today.
Thanks!

Reading along? Create a free ModalAI Forum account to join in.
With an account you can reply, ask your own question, get an email when a ModalAI engineer answers, and mark the reply that solved it. Your place in each thread is saved between visits.
Questions about VOXL, Flight Core, ESCs and ModalAI drones are answered here by the engineers who build them.
Register Login