
voxl-mapper does not show the trajectory
-
Hello Modalai. I'm currently testing voxl-mapper with tracking and TOF camera. The camera server and vixion-px4 are functioning properly.
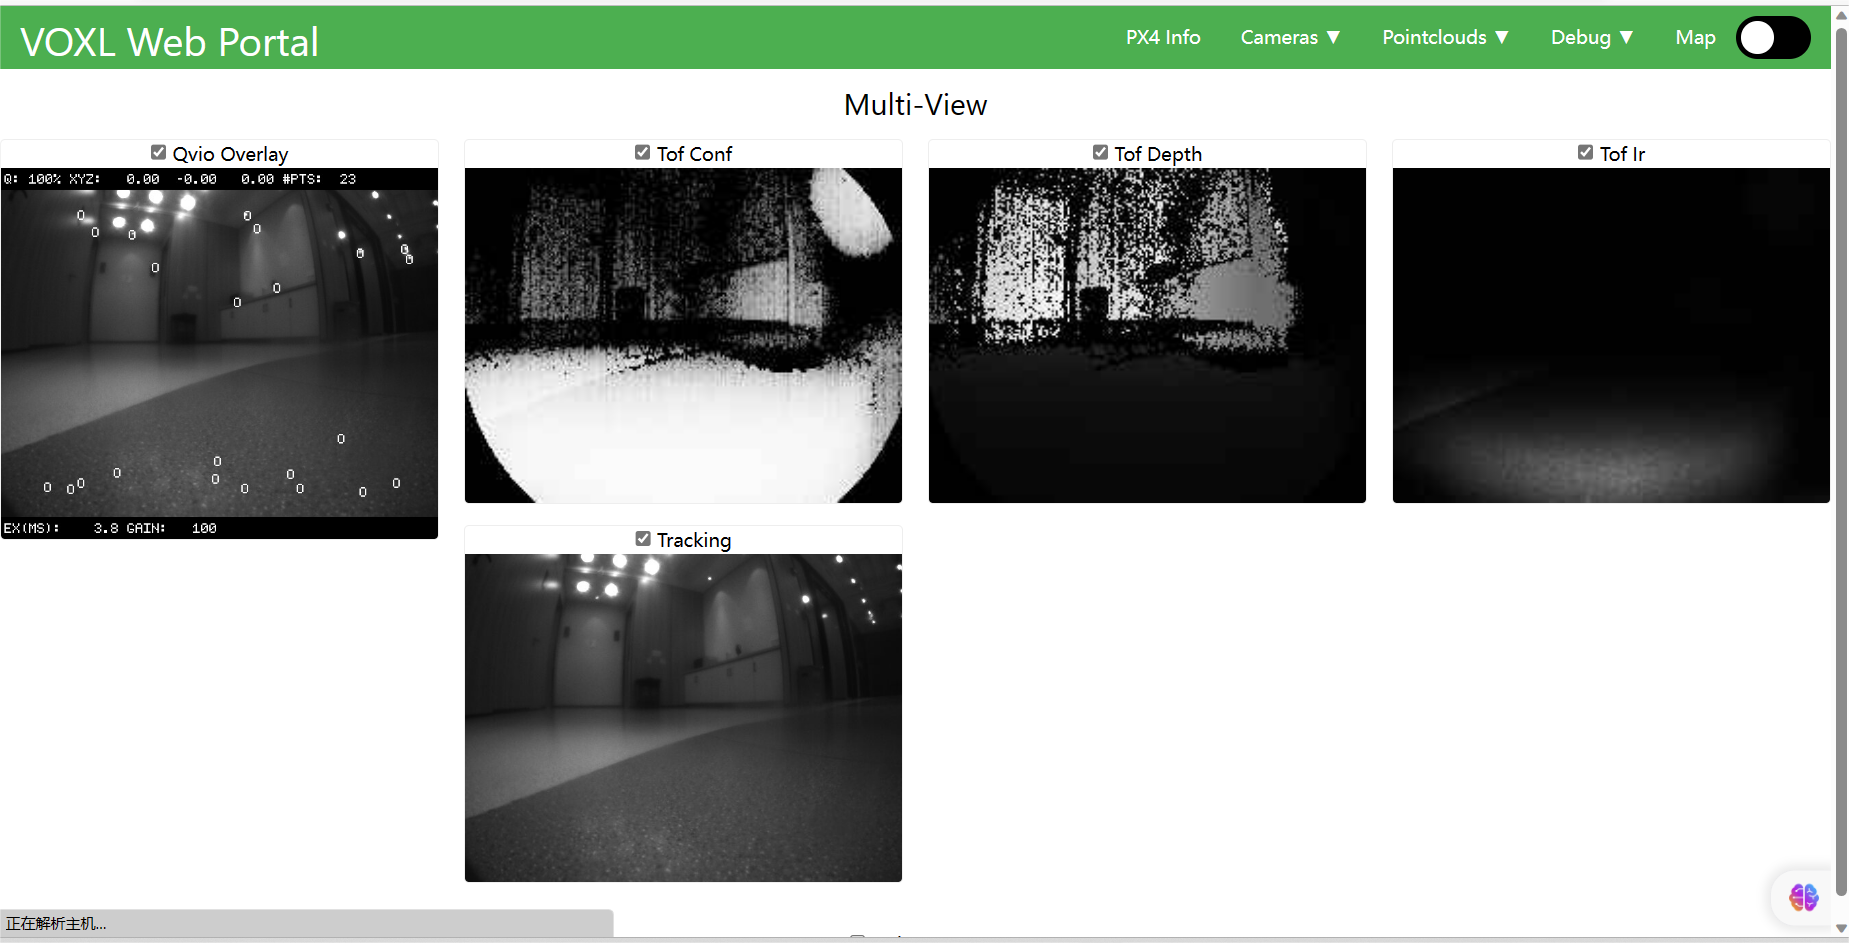
I was able to take off in position mode and switch to offboard mode successfully. However, when I click on a point in Portal UI, it fails to generate the trajectory and there's only the point:
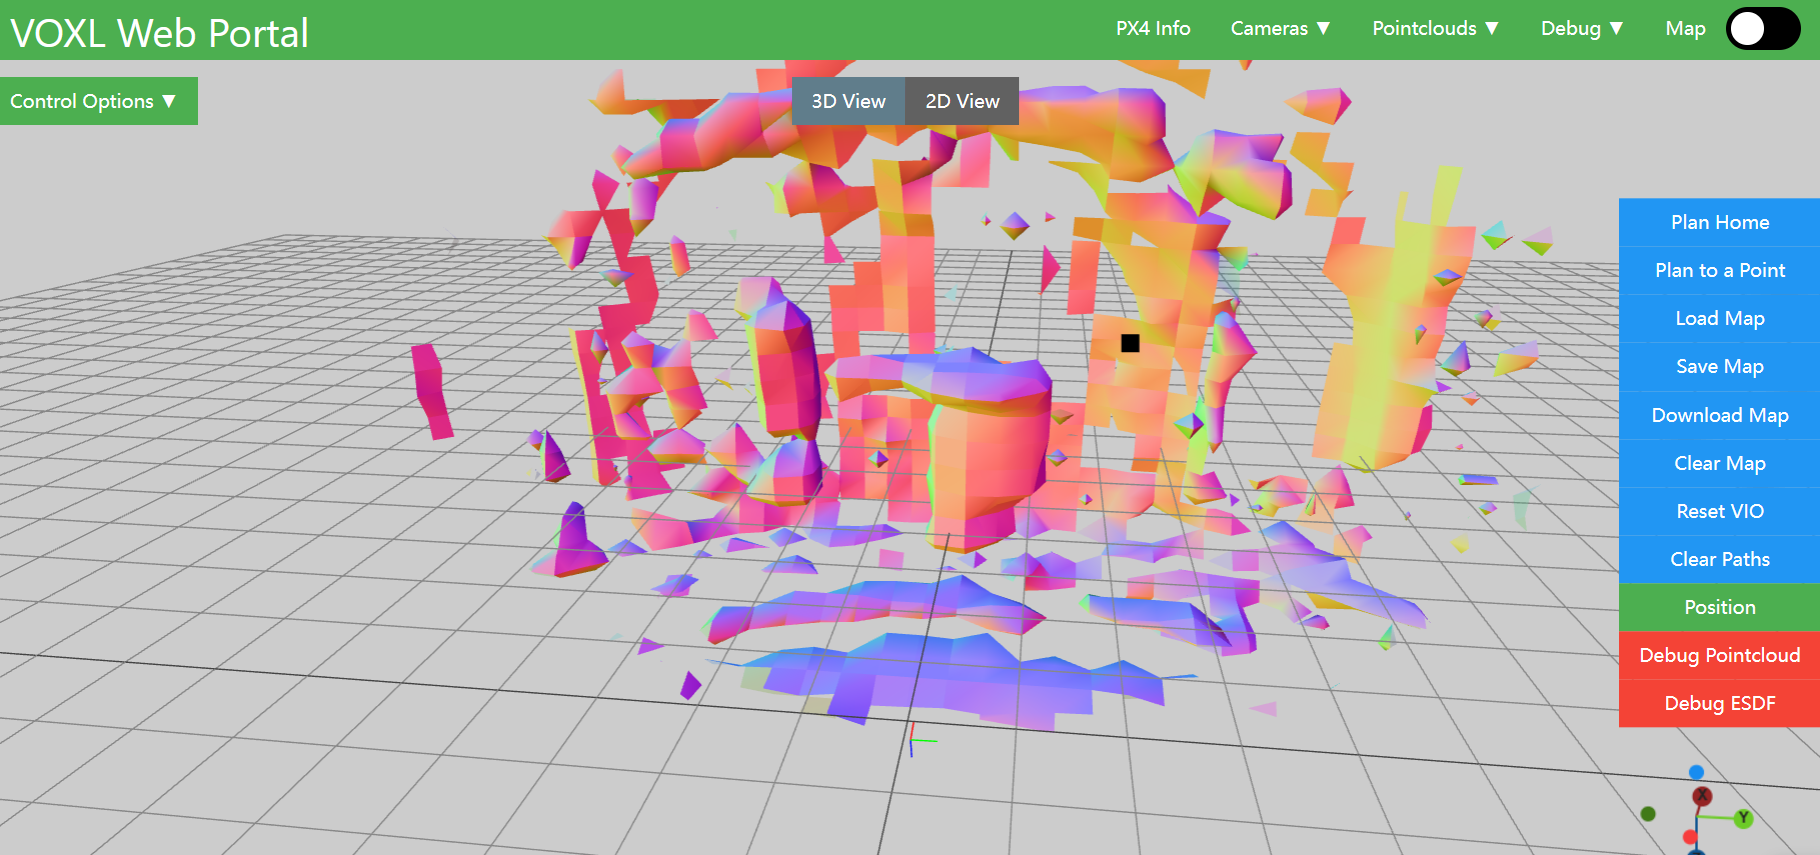
The terminal displays the following error message:
Using start pose of: x:  -0.03, y:   0.02, z:   0.09
Using goal pose of: x:  -0.74, y:   1.67, z:  -2.11
Starting RRTConnect planner
ERROR: End point is in collision
I 'm certain that the end-point is in right position(the value of z is negative, which means that it's off the ground). But why there is no trajectory?
-
I came across a former-topic discussing a similar issue to mine.
BTW, about a month ago, when I tried using voxl-mapper based on your YouTube video (hands-on test without flying), it was able to generate the path successfully.
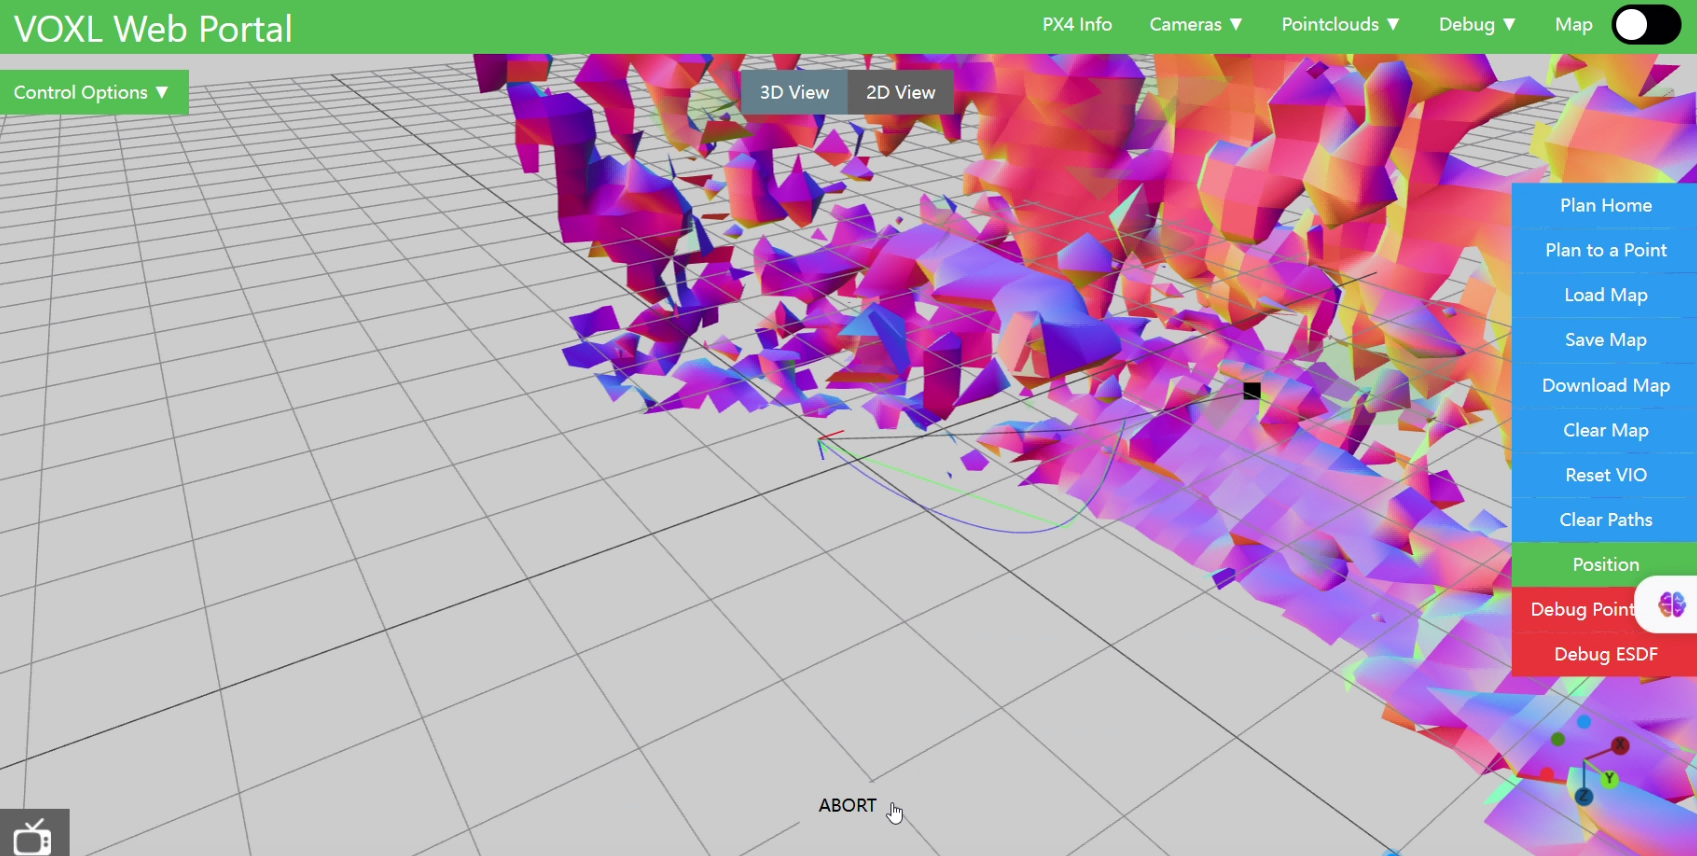
During that time, I accidentally turned over the TOF camera, resulting in a reversed image. I'm wondering if that could be the cause of the problem I'm currently facing?

Reading along? Create a free ModalAI Forum account to join in.
With an account you can reply, ask your own question, get an email when a ModalAI engineer answers, and mark the reply that solved it. Your place in each thread is saved between visits.
Questions about VOXL, Flight Core, ESCs and ModalAI drones are answered here by the engineers who build them.
Register Login